
 作者中心
 专家审稿
 责编办公
 编辑办公

-
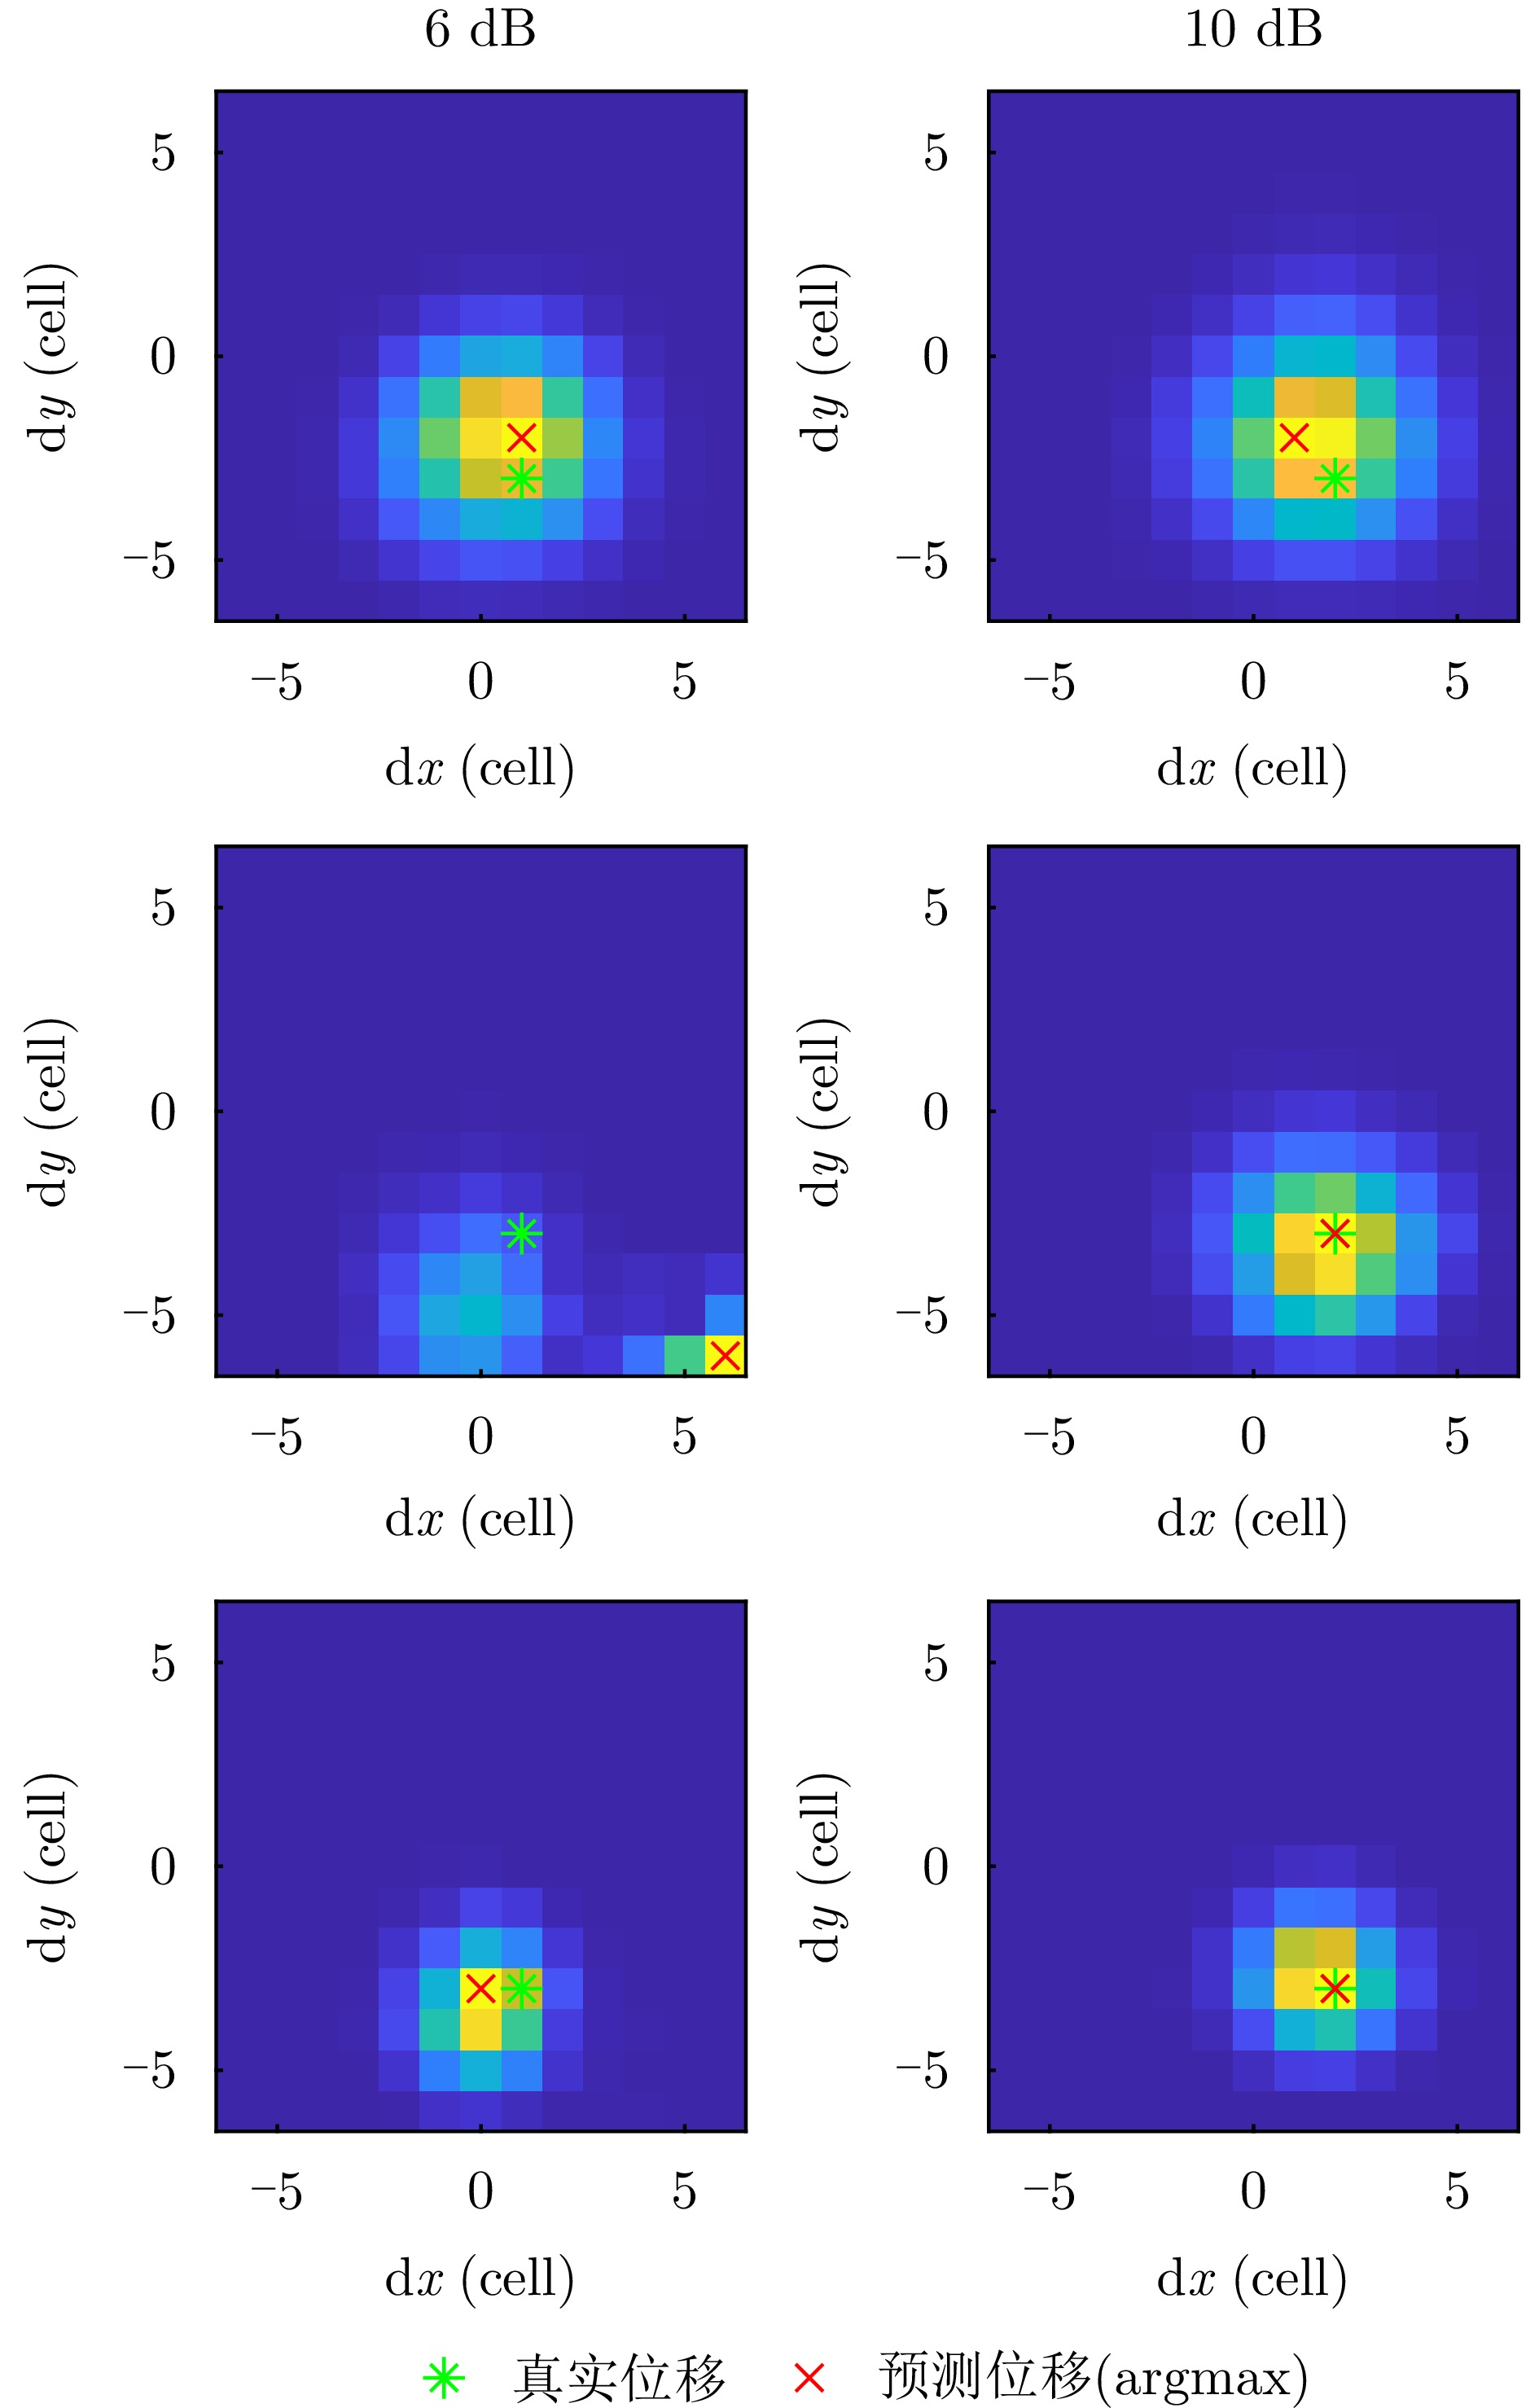
摘要: 现有基于深度学习的检测前跟踪(TBD)方法主要依赖历史状态序列进行运动建模与前向预测,对原始量测平面中目标能量分布及时空一致性信息的显式利用不足,在复杂机动场景下易产生累积误差和轨迹偏移。针对此问题,该文提出一种基于Transformer架构的量测引导转移门控网络(MG-TGN),以数据驱动方式生成自适应状态转移范围。MG-TGN从历史轨迹与量测序列中提取时空特征,预测先验位移概率矩阵,同时利用当前帧量测平面提取局部观测响应以估计观测似然概率,并通过可学习门控系数对二者进行动态融合,确定候选转移集合,从而约束动态规划递推的状态搜索空间。该方法将深度特征融合策略嵌入TBD框架,在保留全局路径搜索优势的同时,提升低信噪比下机动目标的能量累积一致性与轨迹稳定性。实验结果表明,相较于既有深度学习TBD方法,本文方法在信噪比为8 dB时,弱机动场景下目标检测概率提升约5%,强机动场景下提升约28%。
-
关键词:
- 检测前跟踪 /
- 机动目标 /
- 动态规划 /
- Transformer架构 /
- 转移范围优化
Abstract: Existing deep learning-–based track-before-detect (TBD) methods primarily rely on historical state sequences for motion modeling and forward prediction. They do not explicitly utilize target energy distribution and spatiotemporal consistency information in raw measurement planes, which causes cumulative errors and trajectory drift in complex maneuvering scenarios. To address this issue, this study proposes a Transformer--based measurement--guided transition gating network (MG-TGN), which adaptively generates state transition ranges in a data-driven manner. The MG-TGN extracts spatiotemporal features from historical trajectories and measurement sequences to predict a prior displacement probability matrix. Concurrently, it uses local observation responses from the current-frame measurement plane to estimate the observation likelihood probability. These two probabilistic quantities are dynamically fused using learnable gating coefficients to form a candidate transition set, thereby constraining the state search space for dynamic programming recursion. By embedding a deep feature fusion strategy into the TBD framework, the proposed method retains the advantages of global path search while enhancing both energy accumulation consistency and trajectory stability for maneuvering targets under low signal-to-noise ratio (SNR) conditions. Experimental results demonstrated that, compared with existing deep learning–based TBD methods, the proposed method achieves approximately 5% and 28% higher target detection probabilities in weak and strong maneuvering scenarios, respectively, at an SNR of 8 dB. -
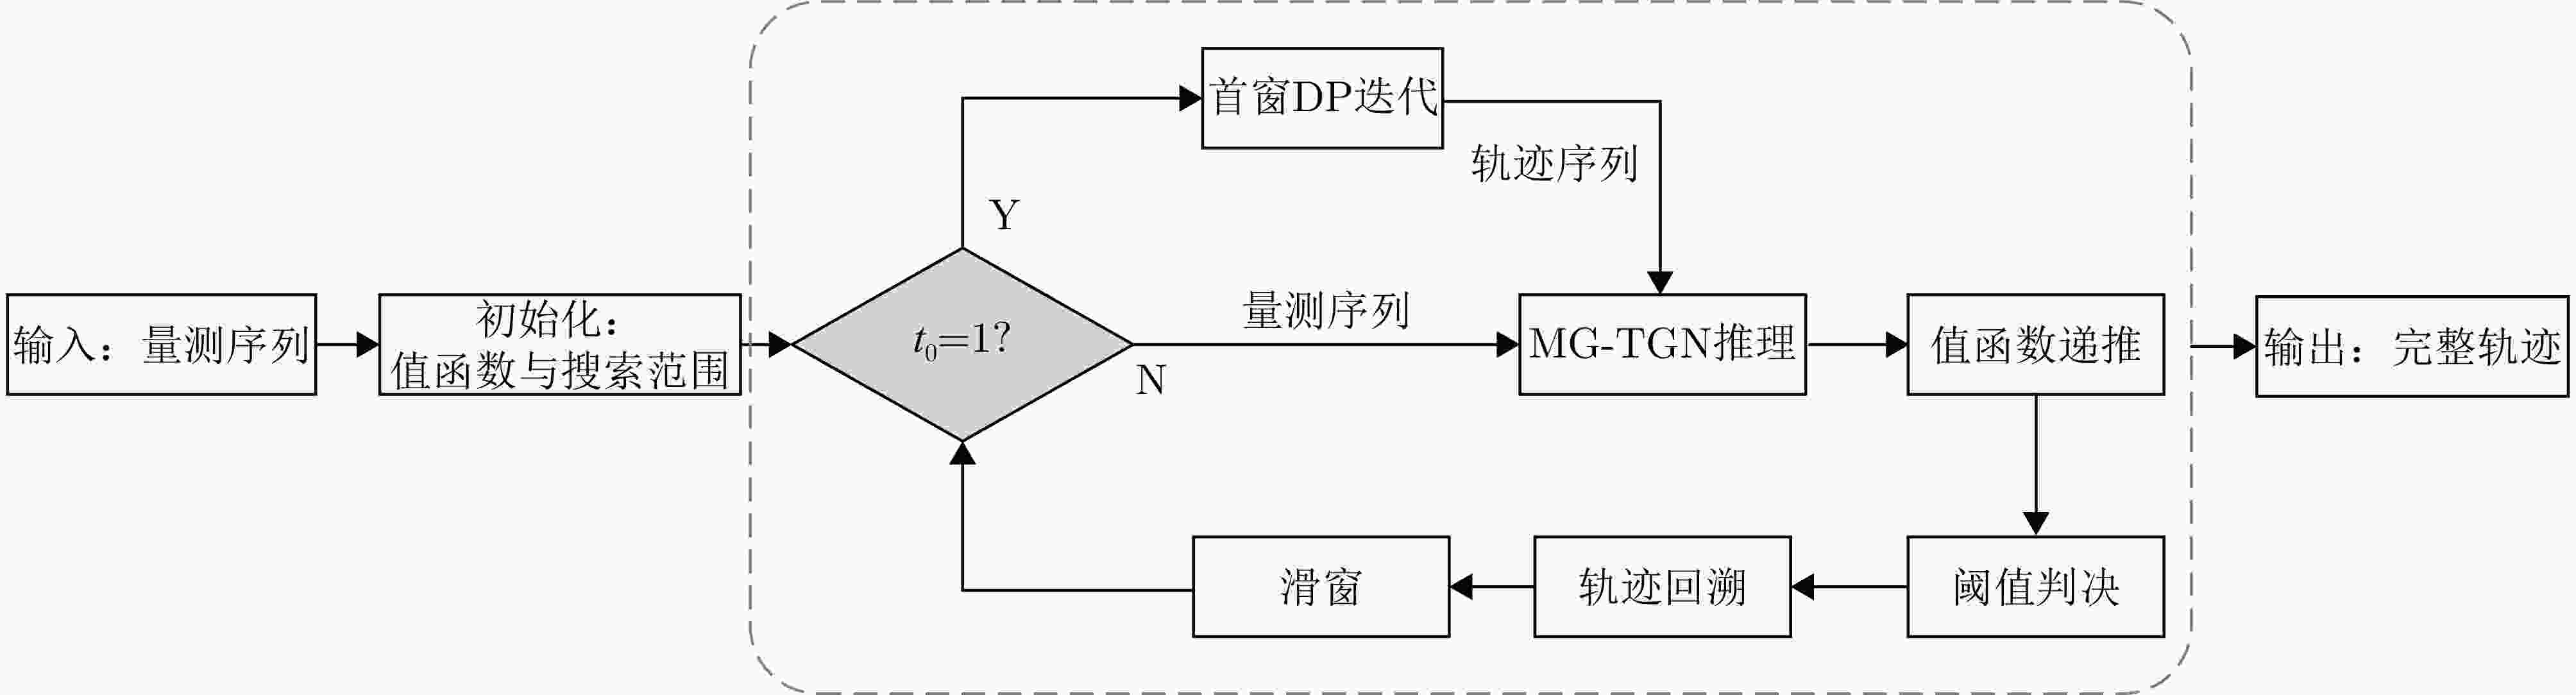
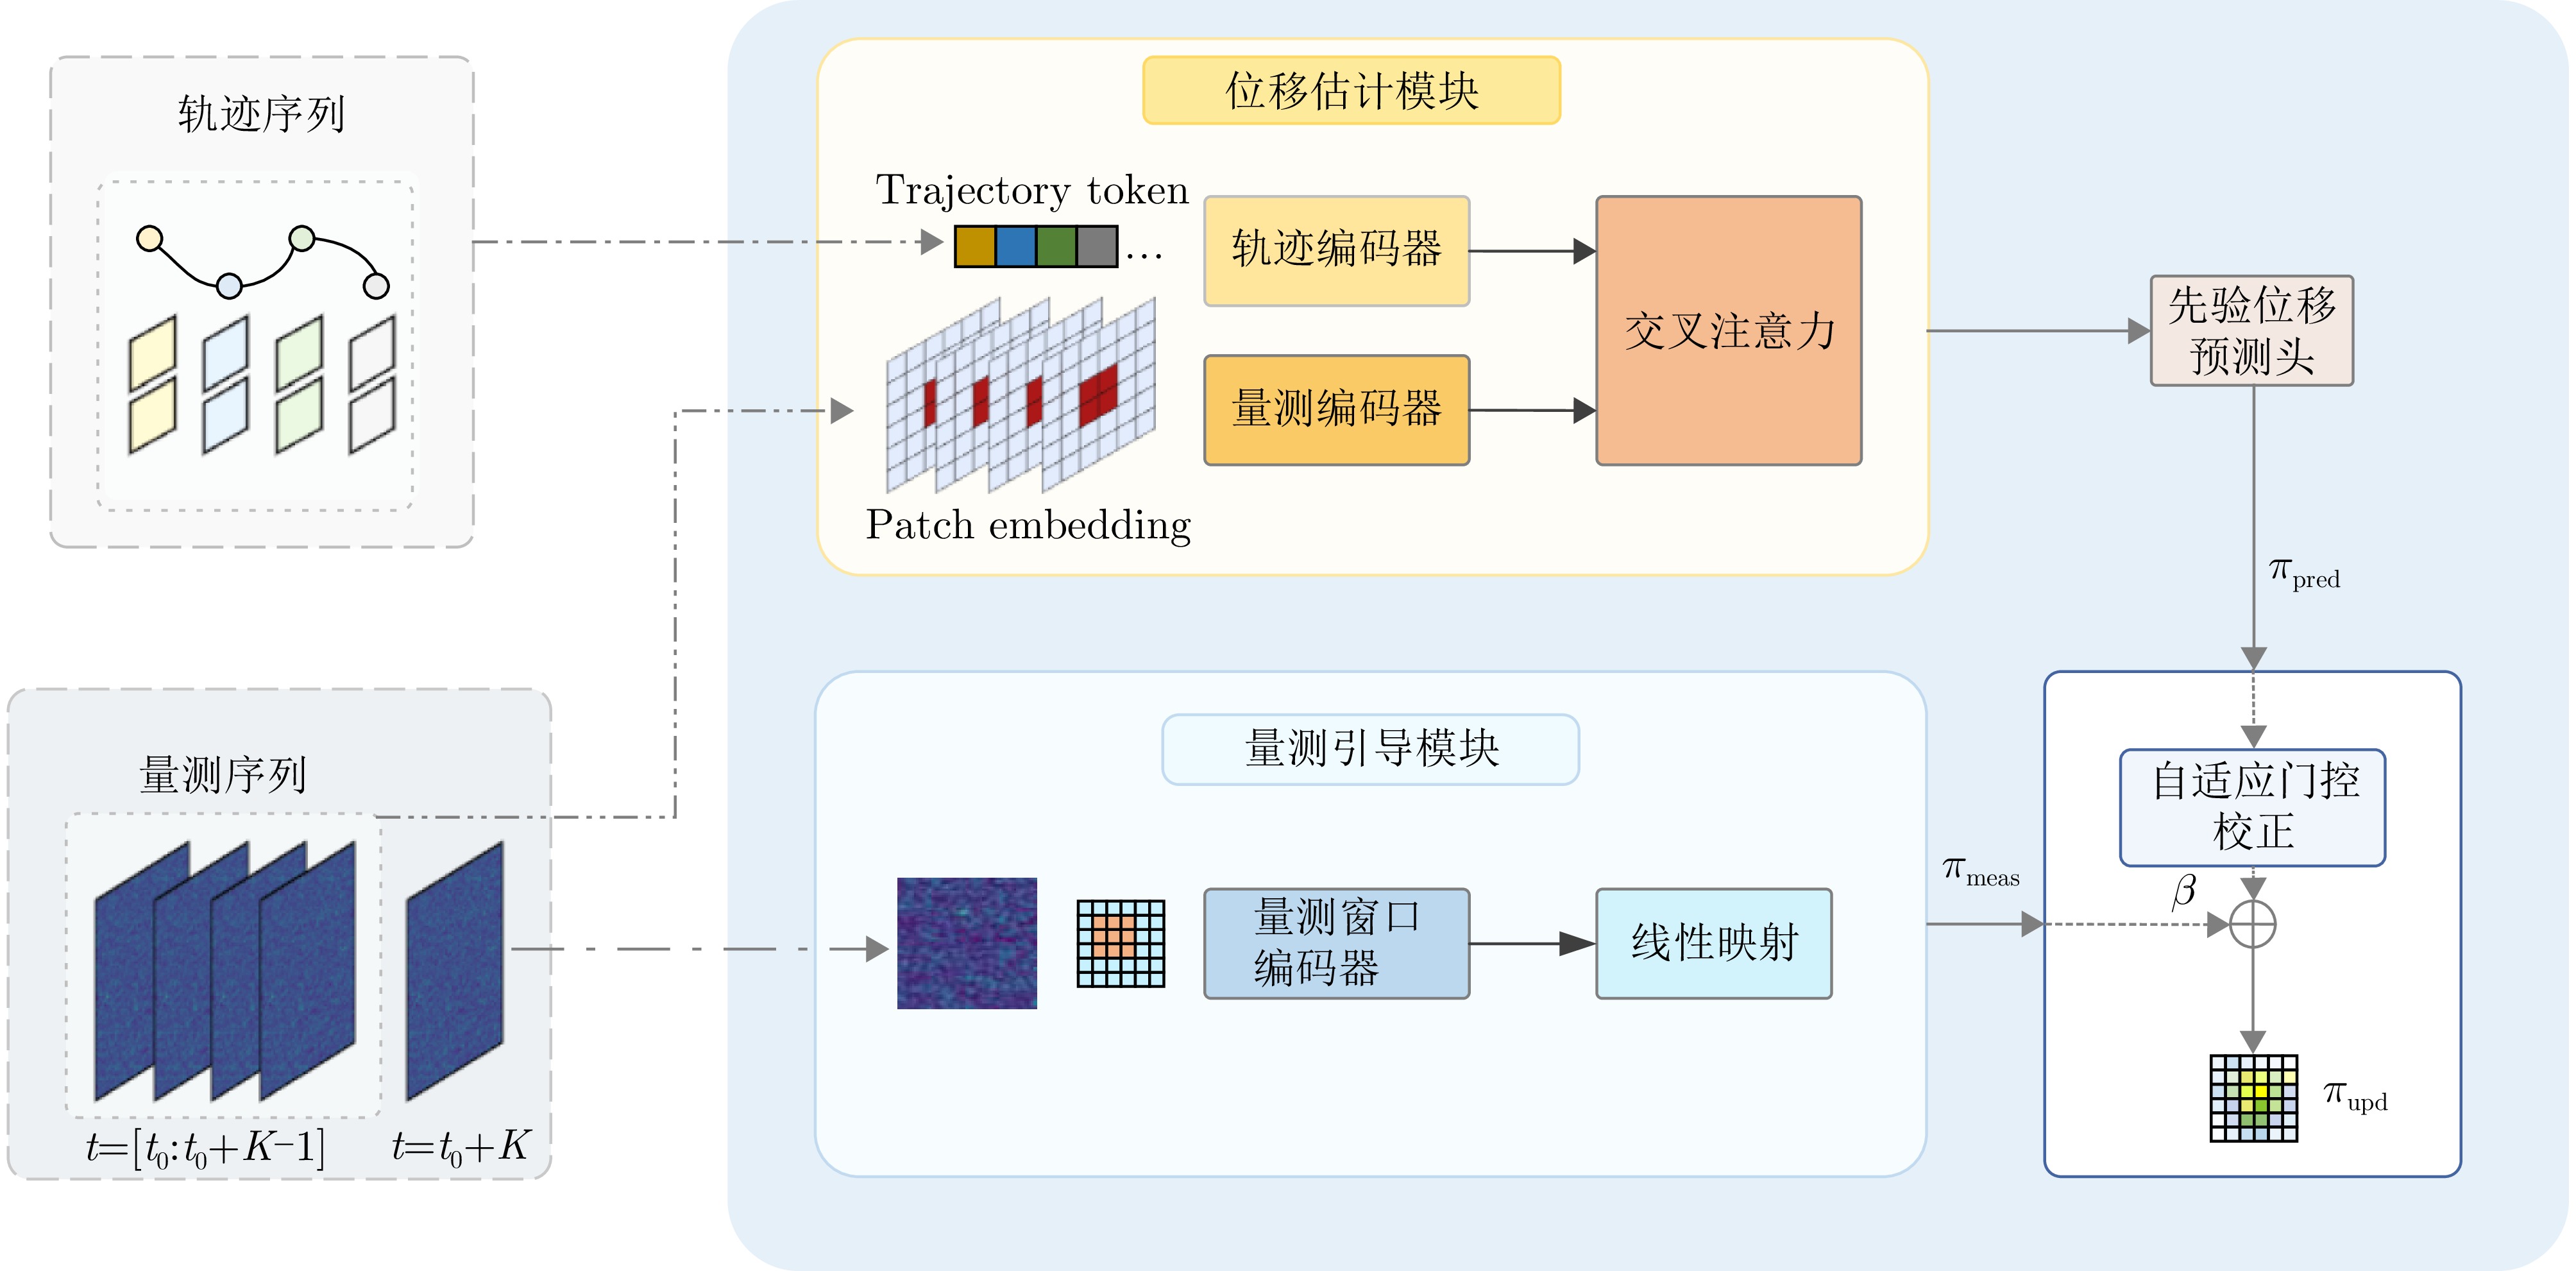
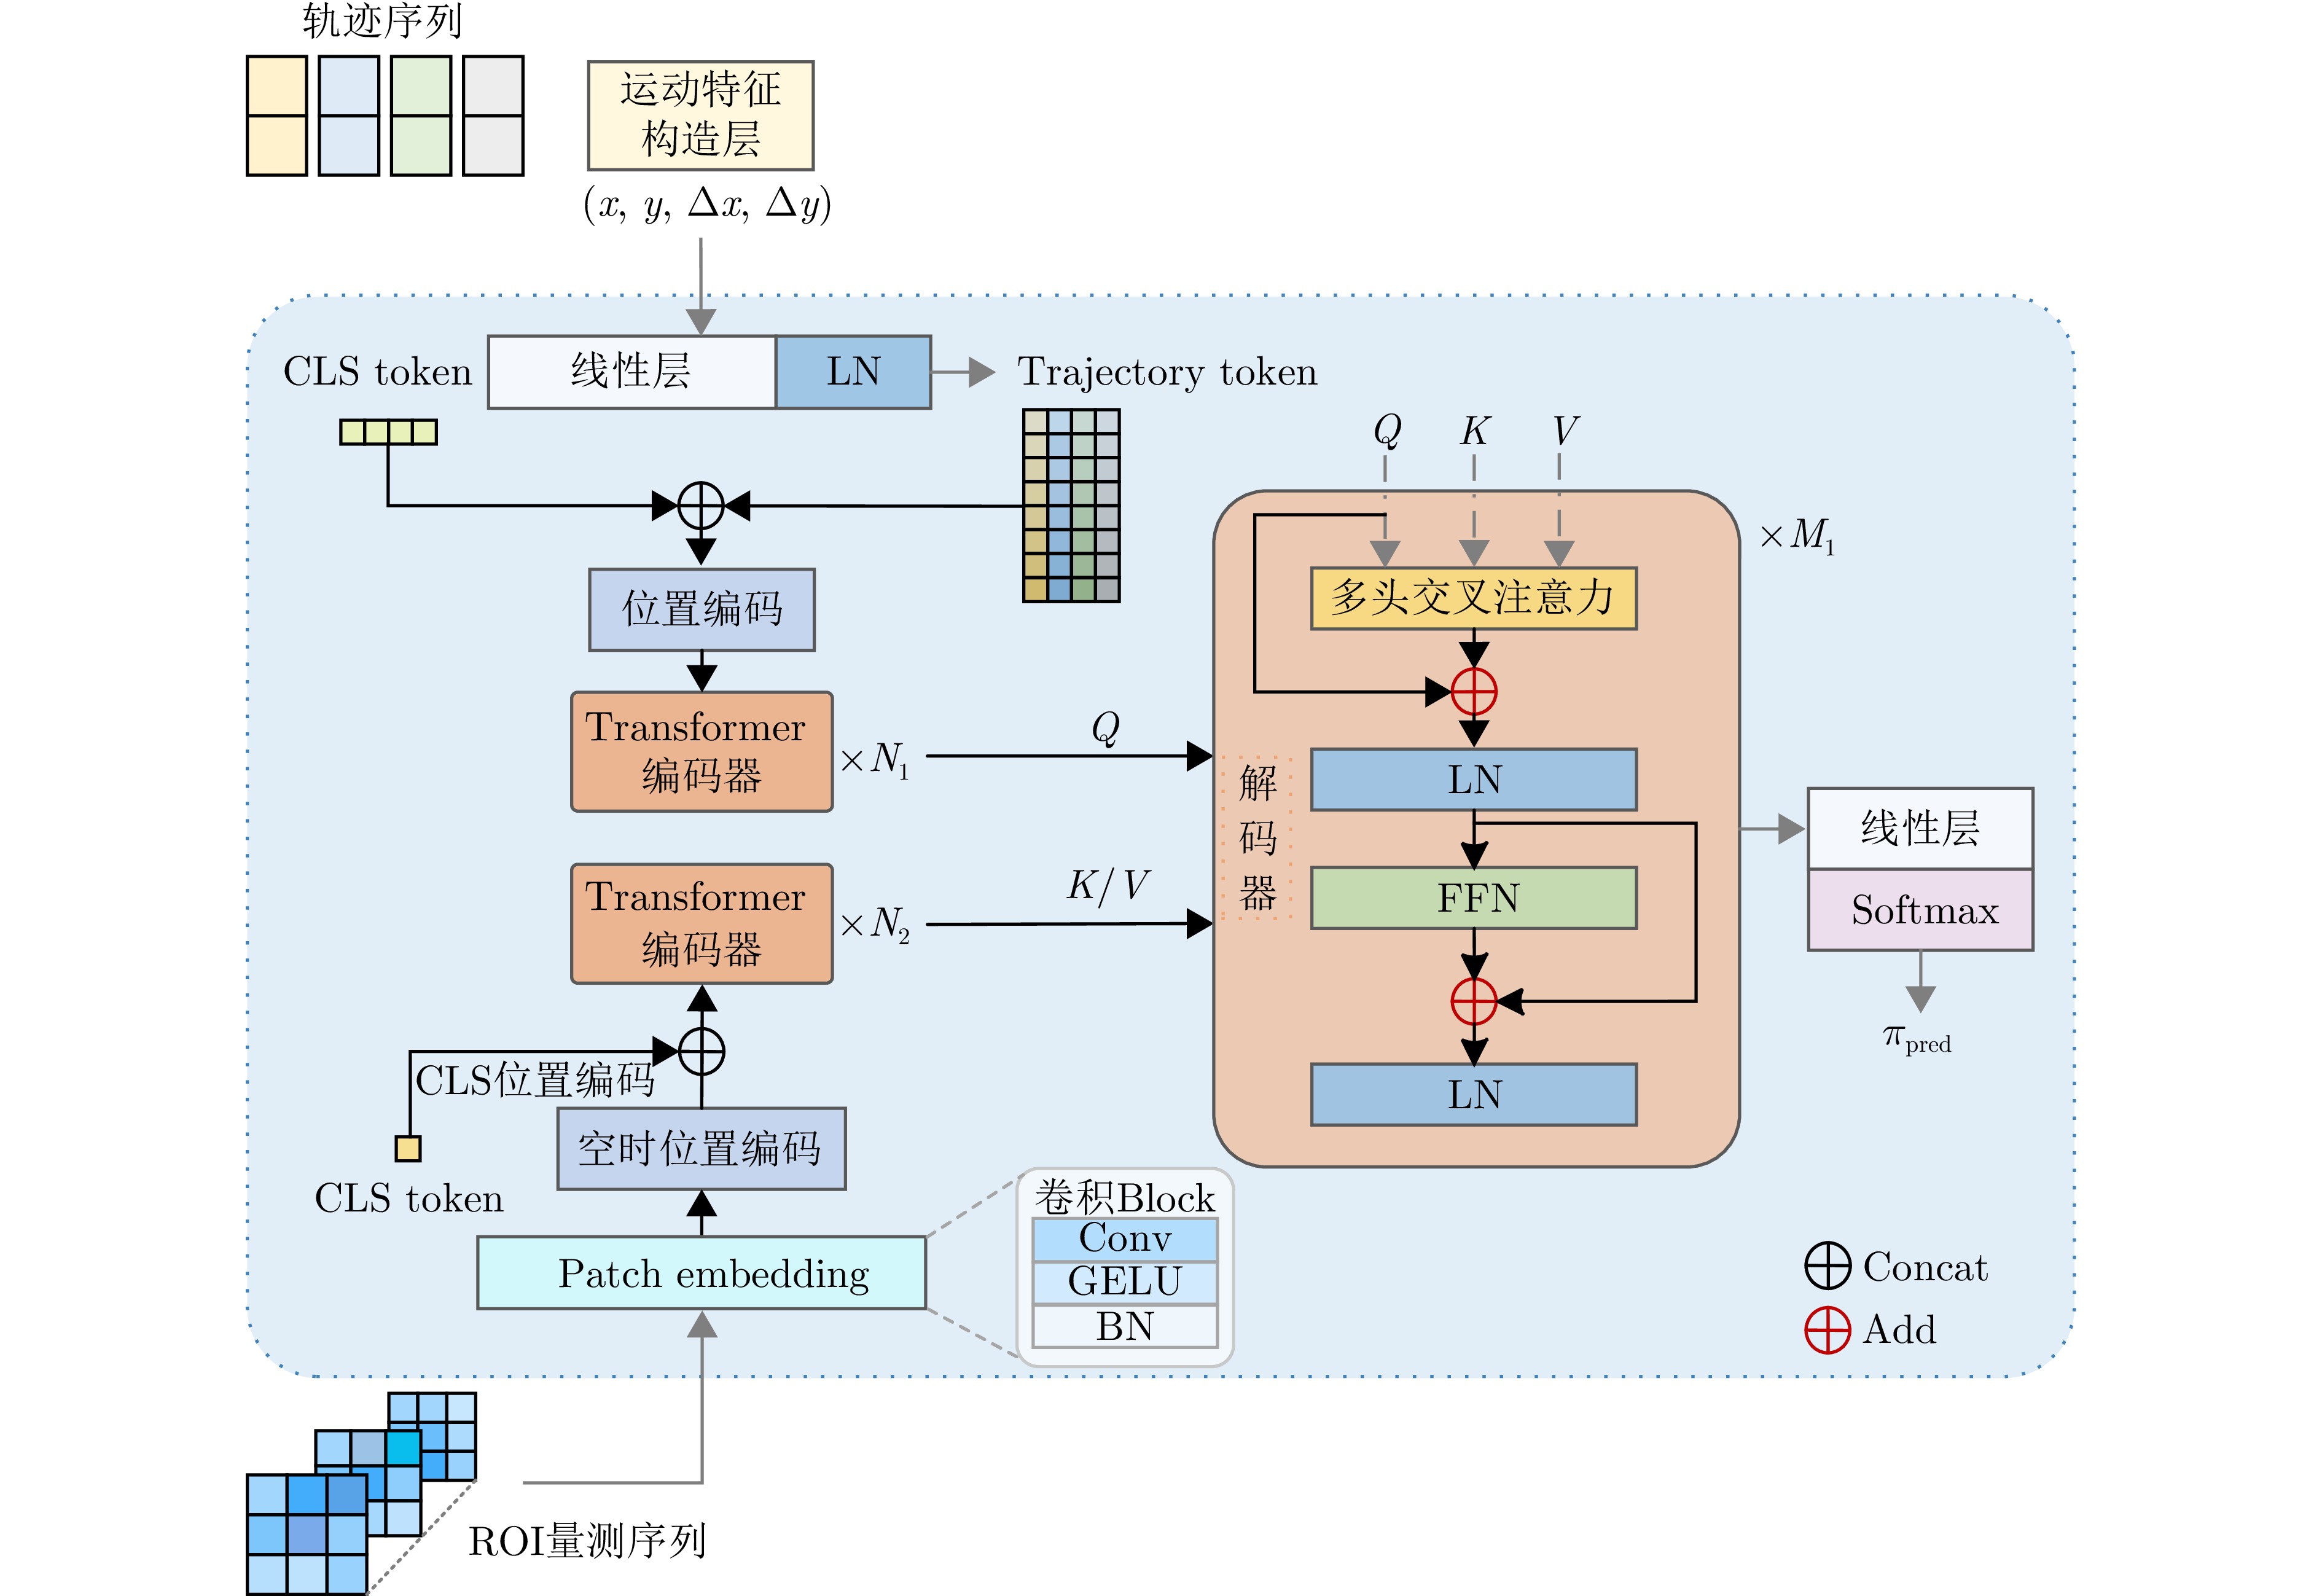
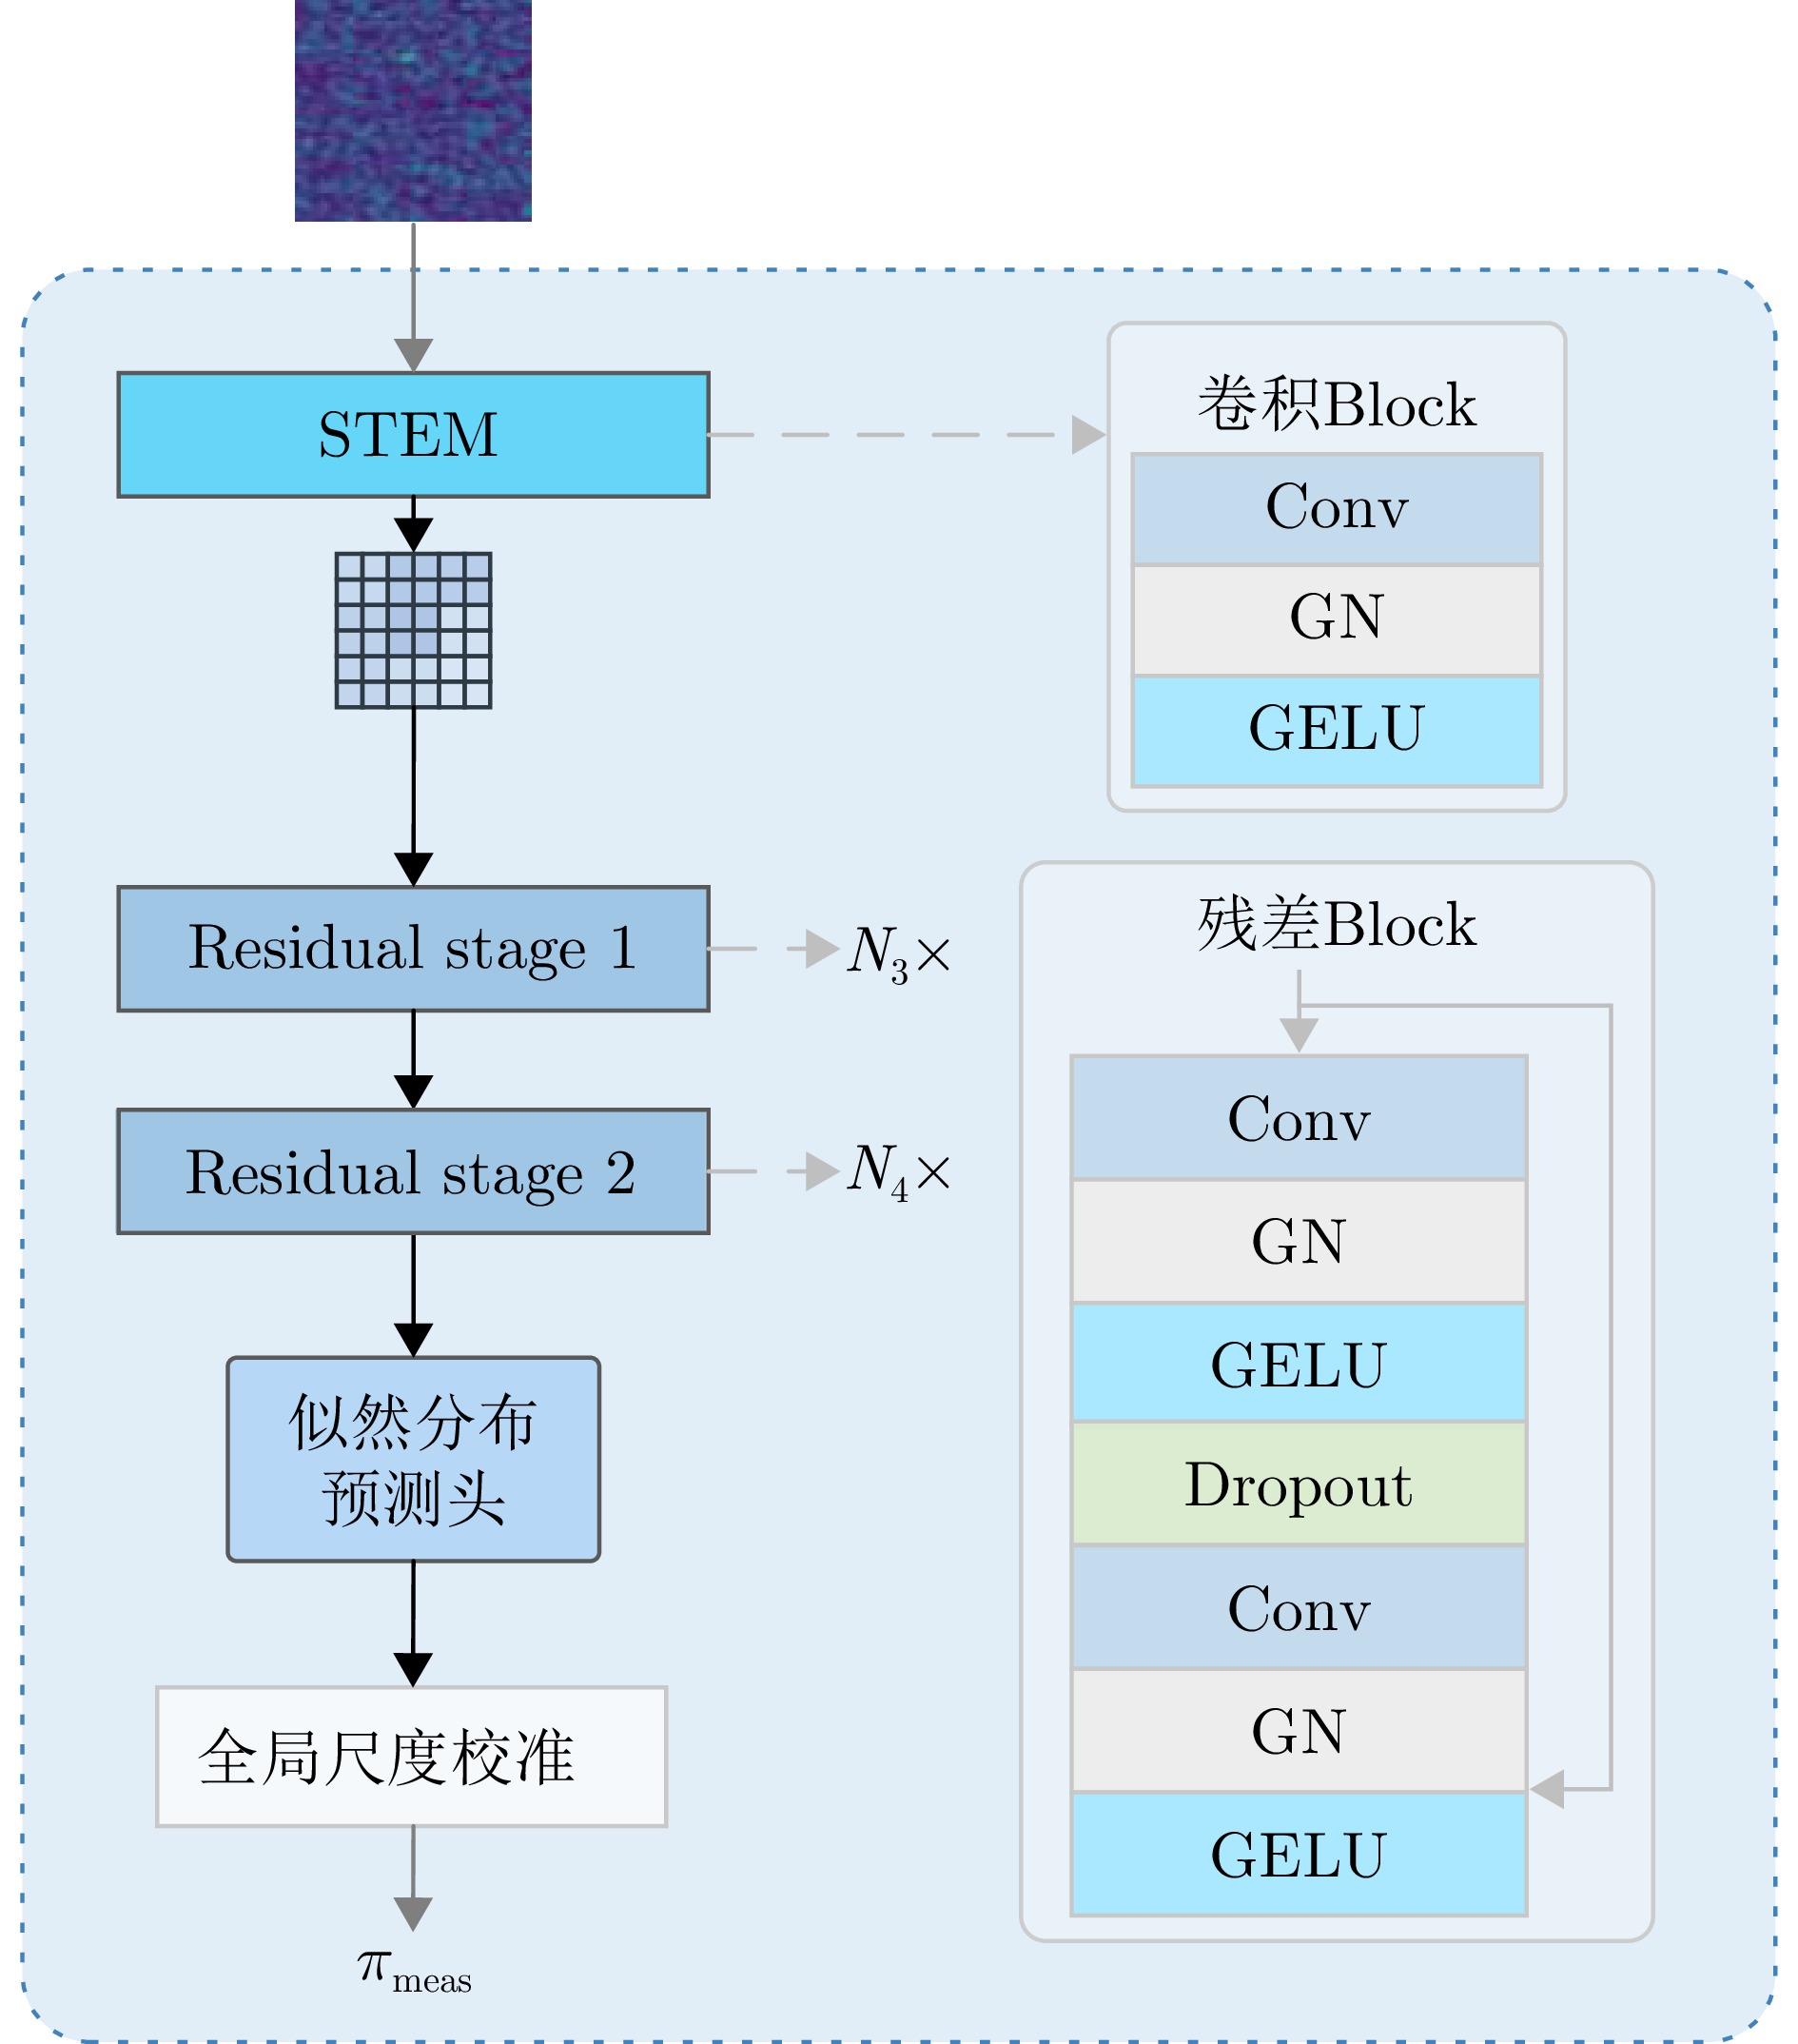
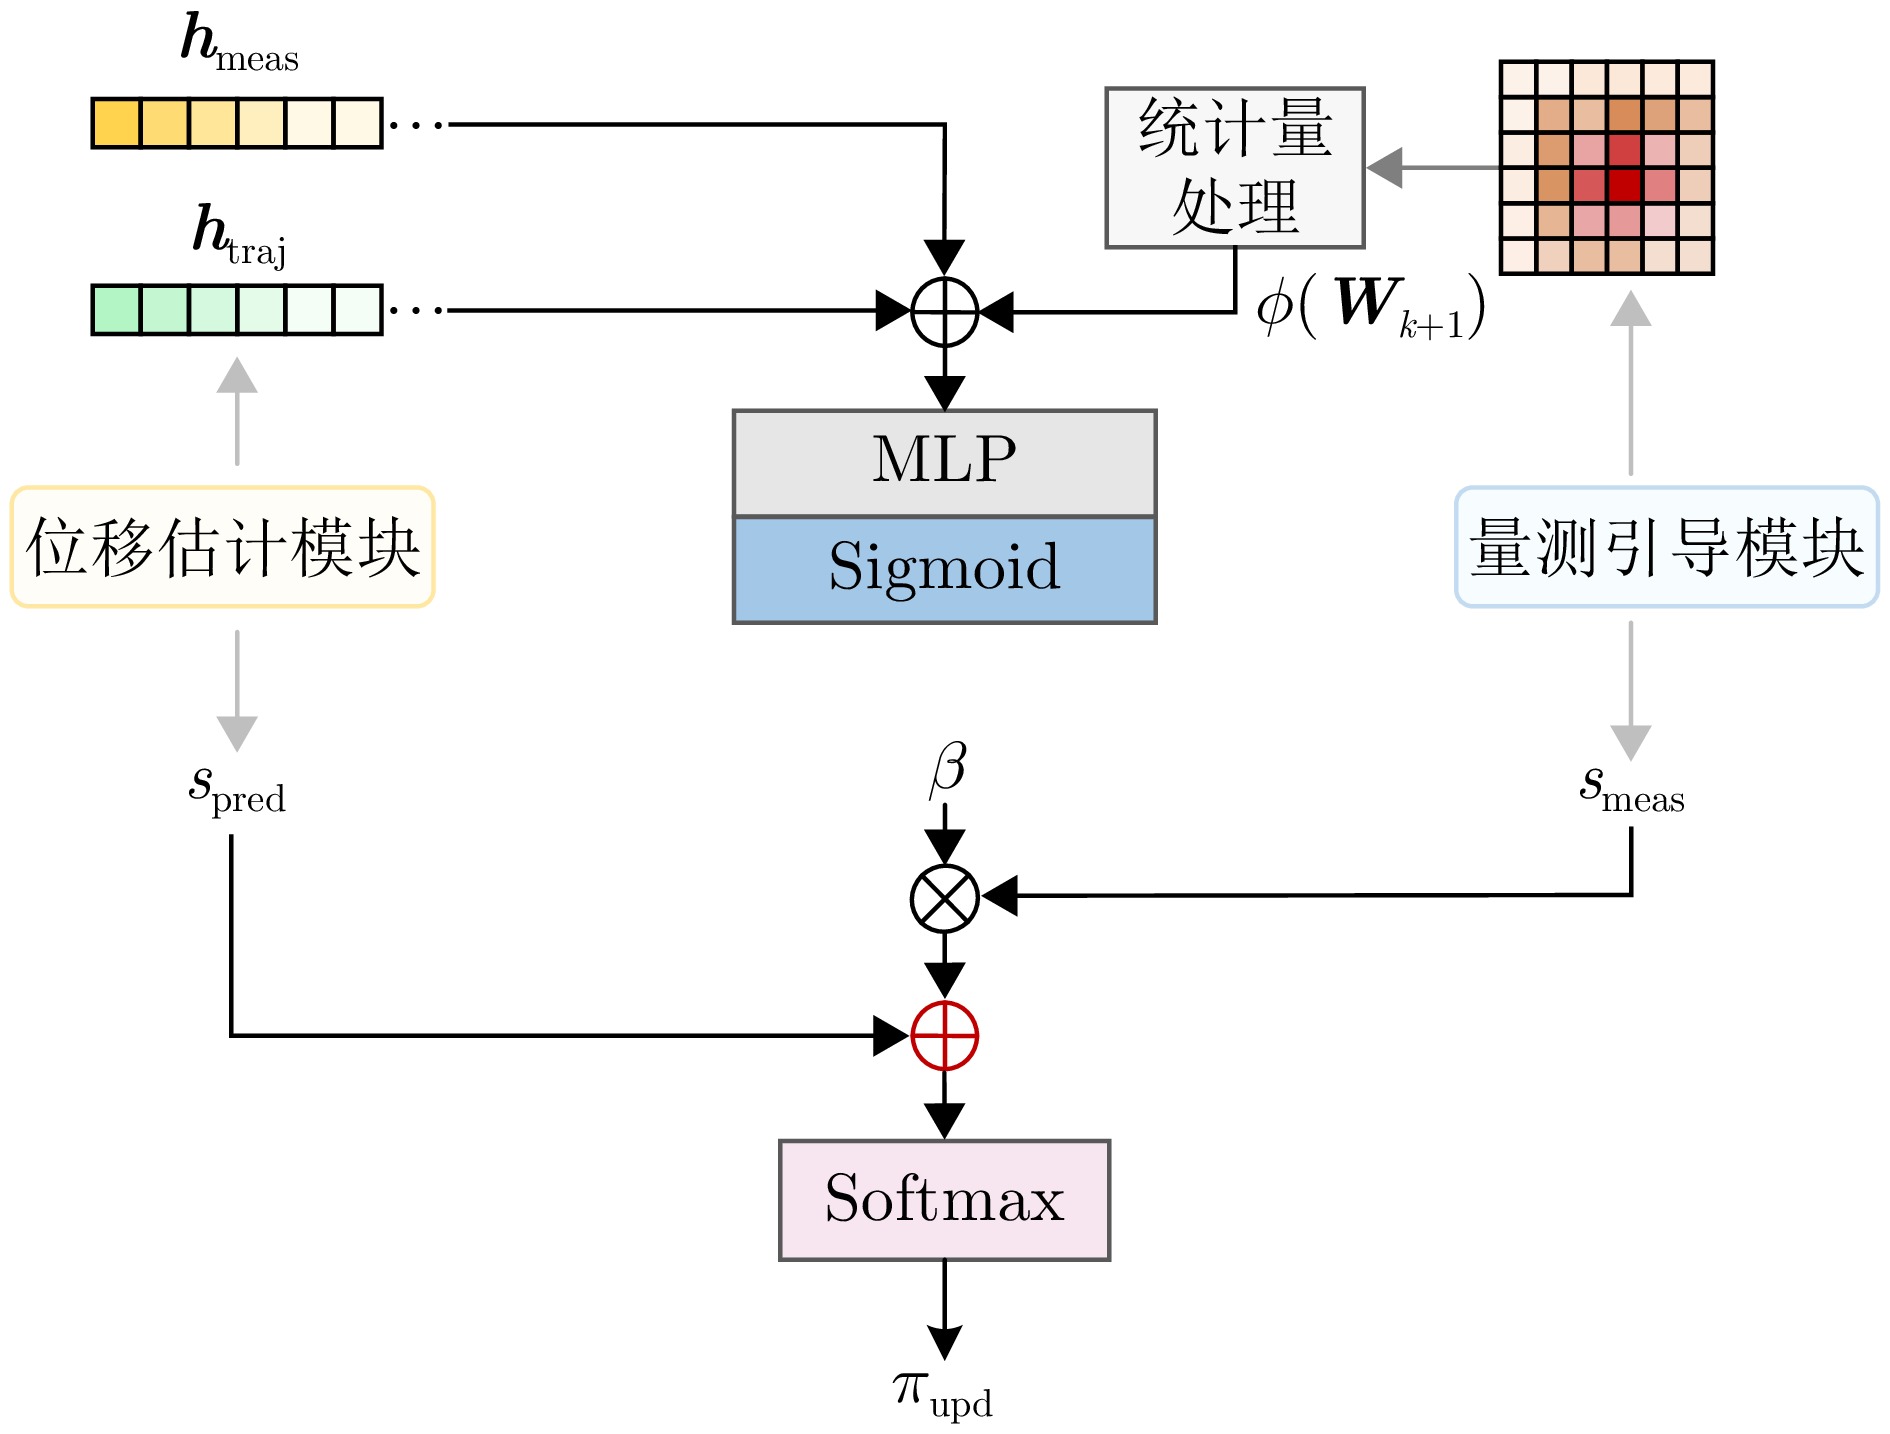
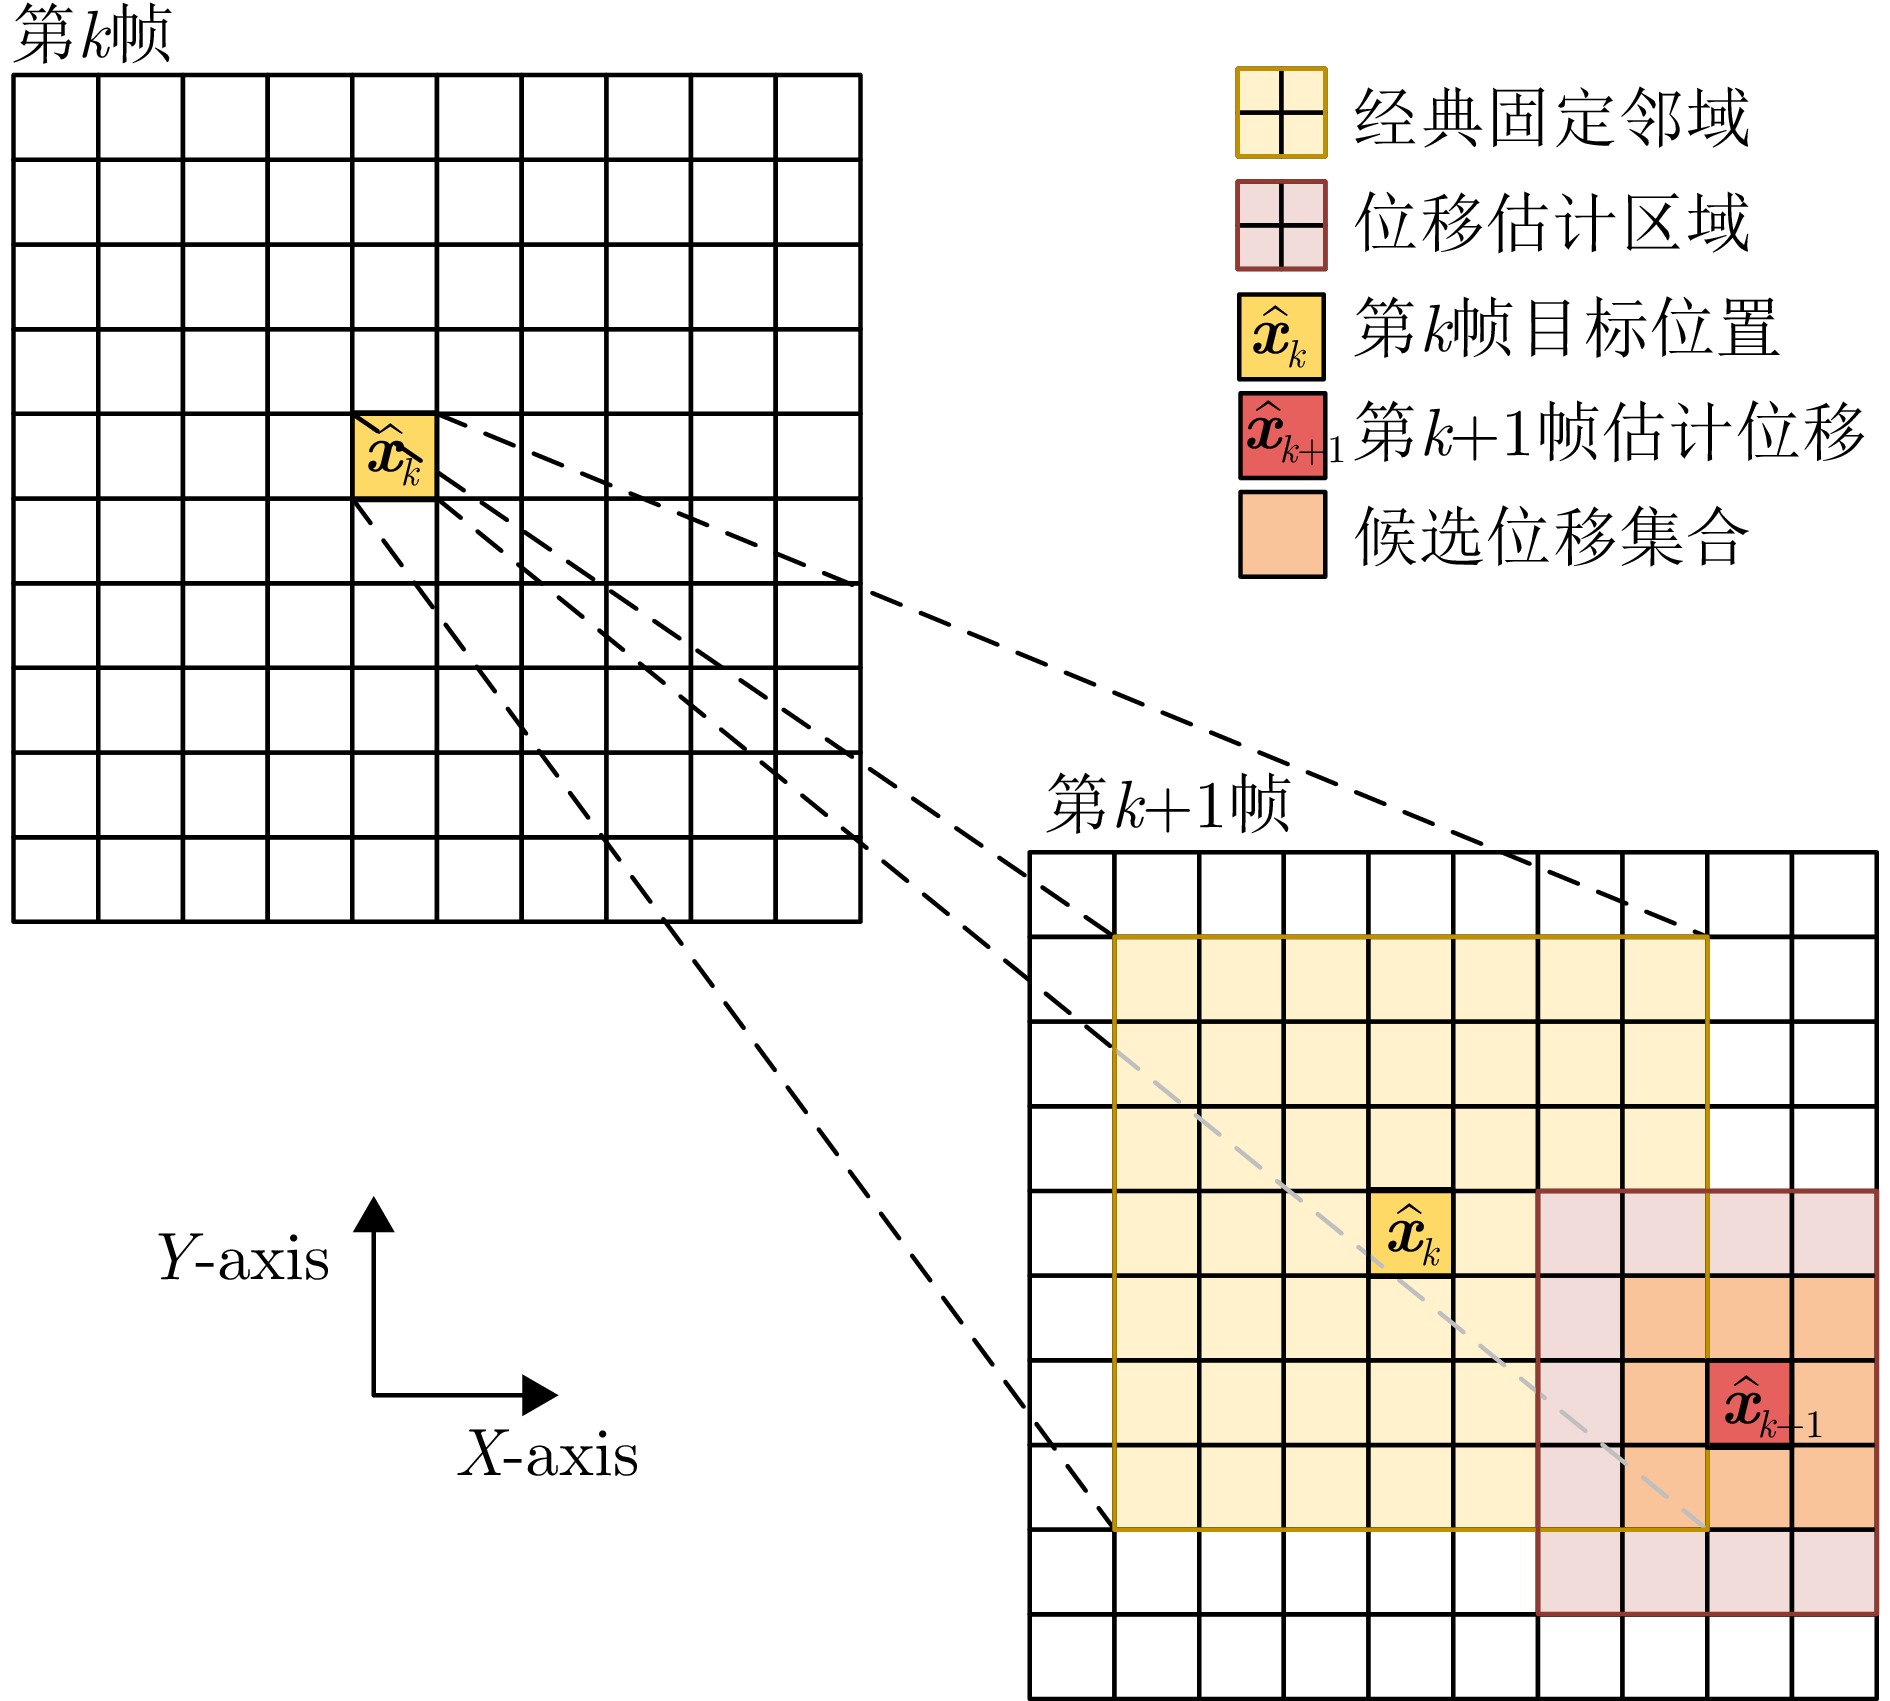
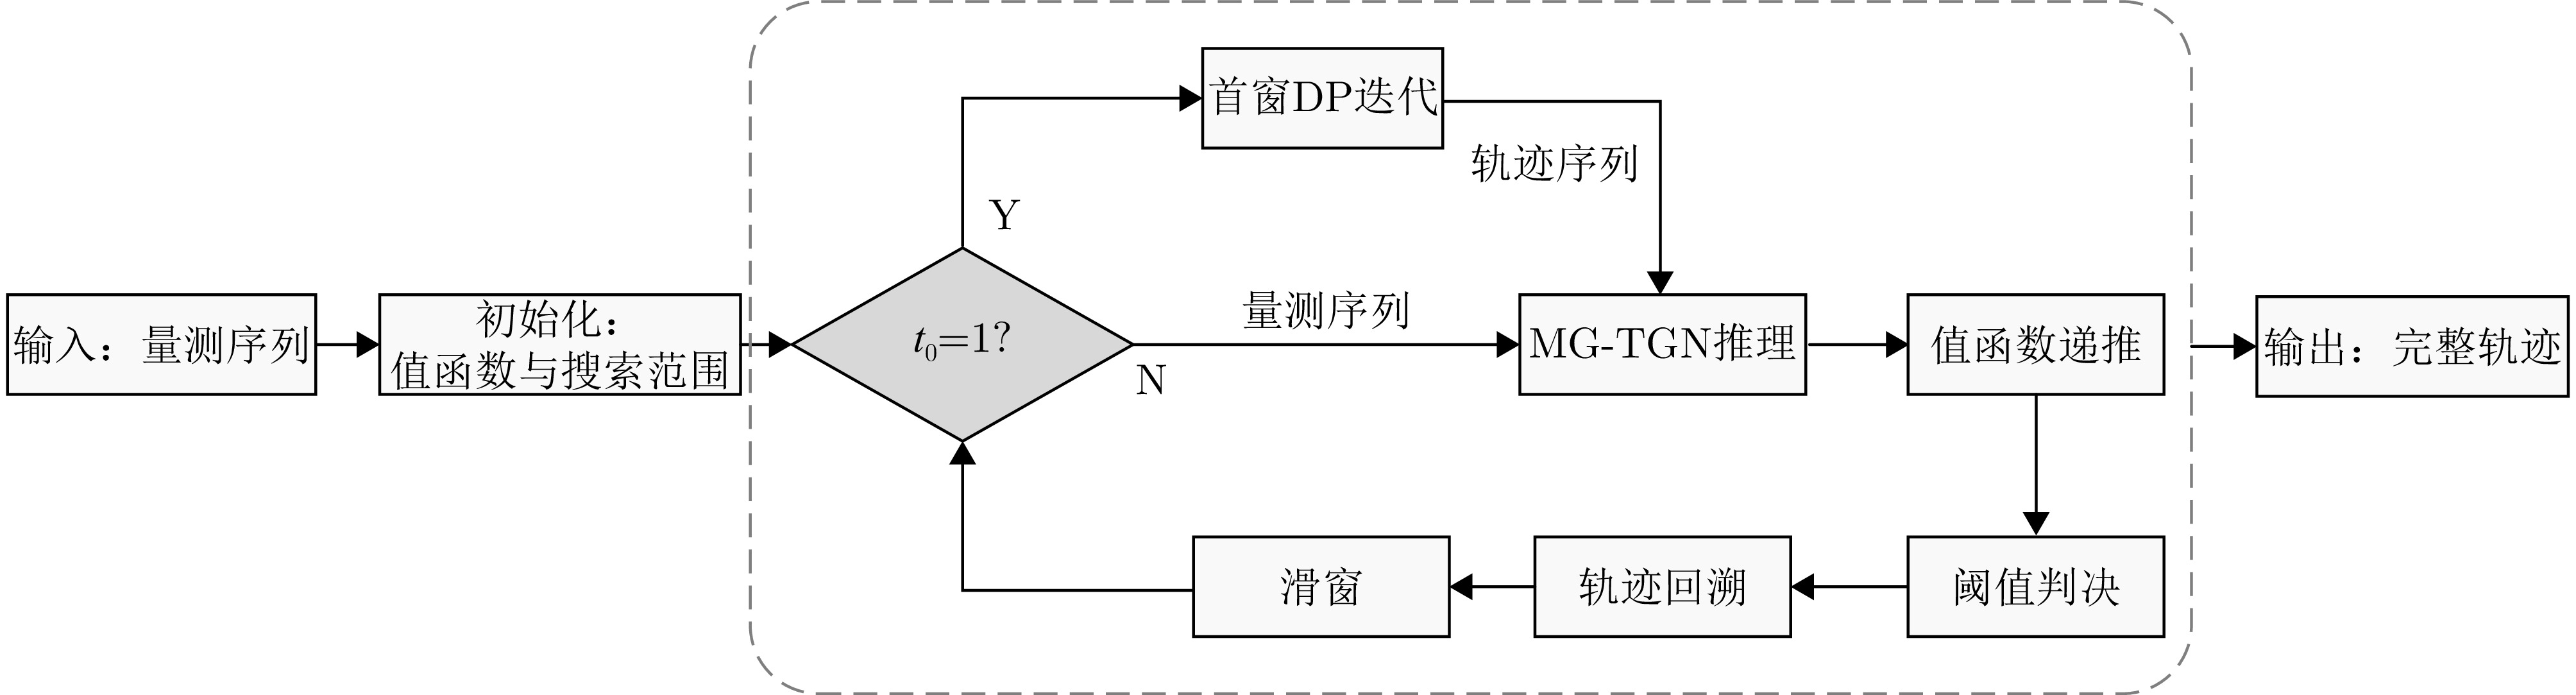
图 1 基于Transformer状态转移范围优化的检测前跟踪方法推理流程
Figure 1. Inference pipeline for Transformer-based TBD with optimized state transition range
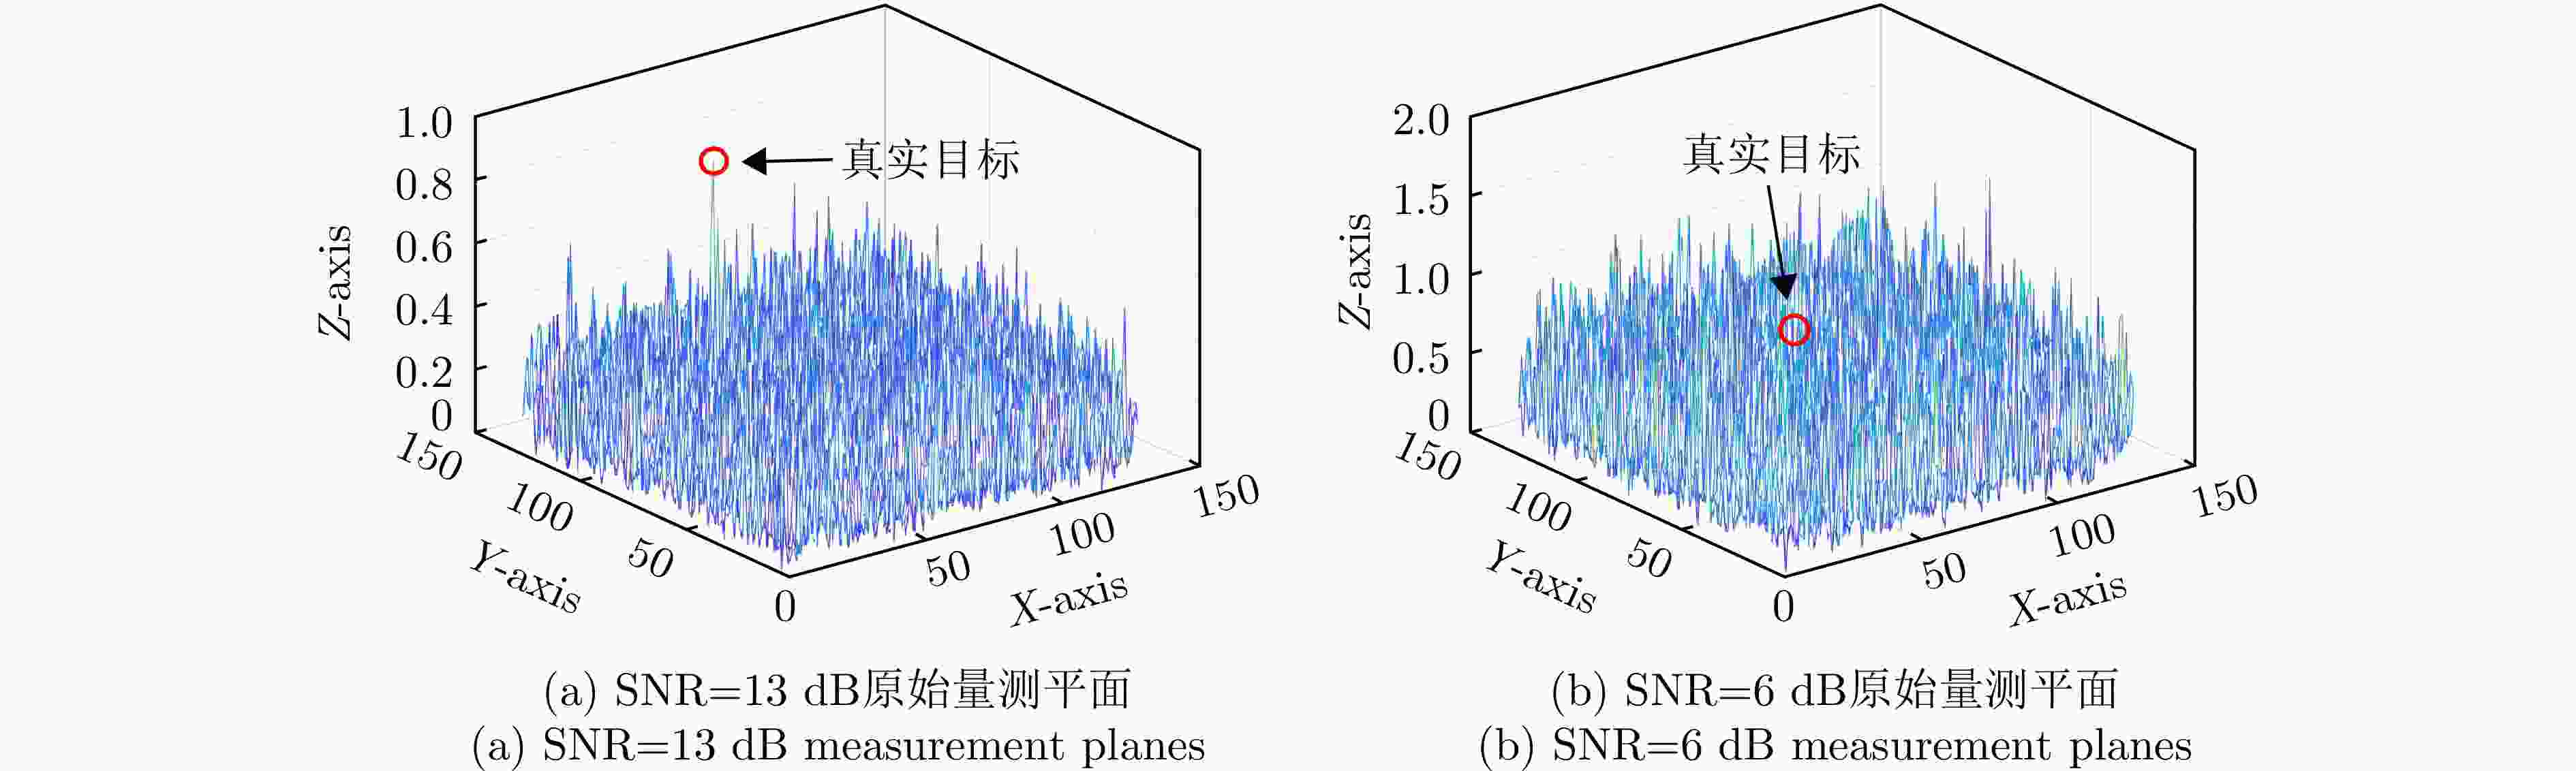
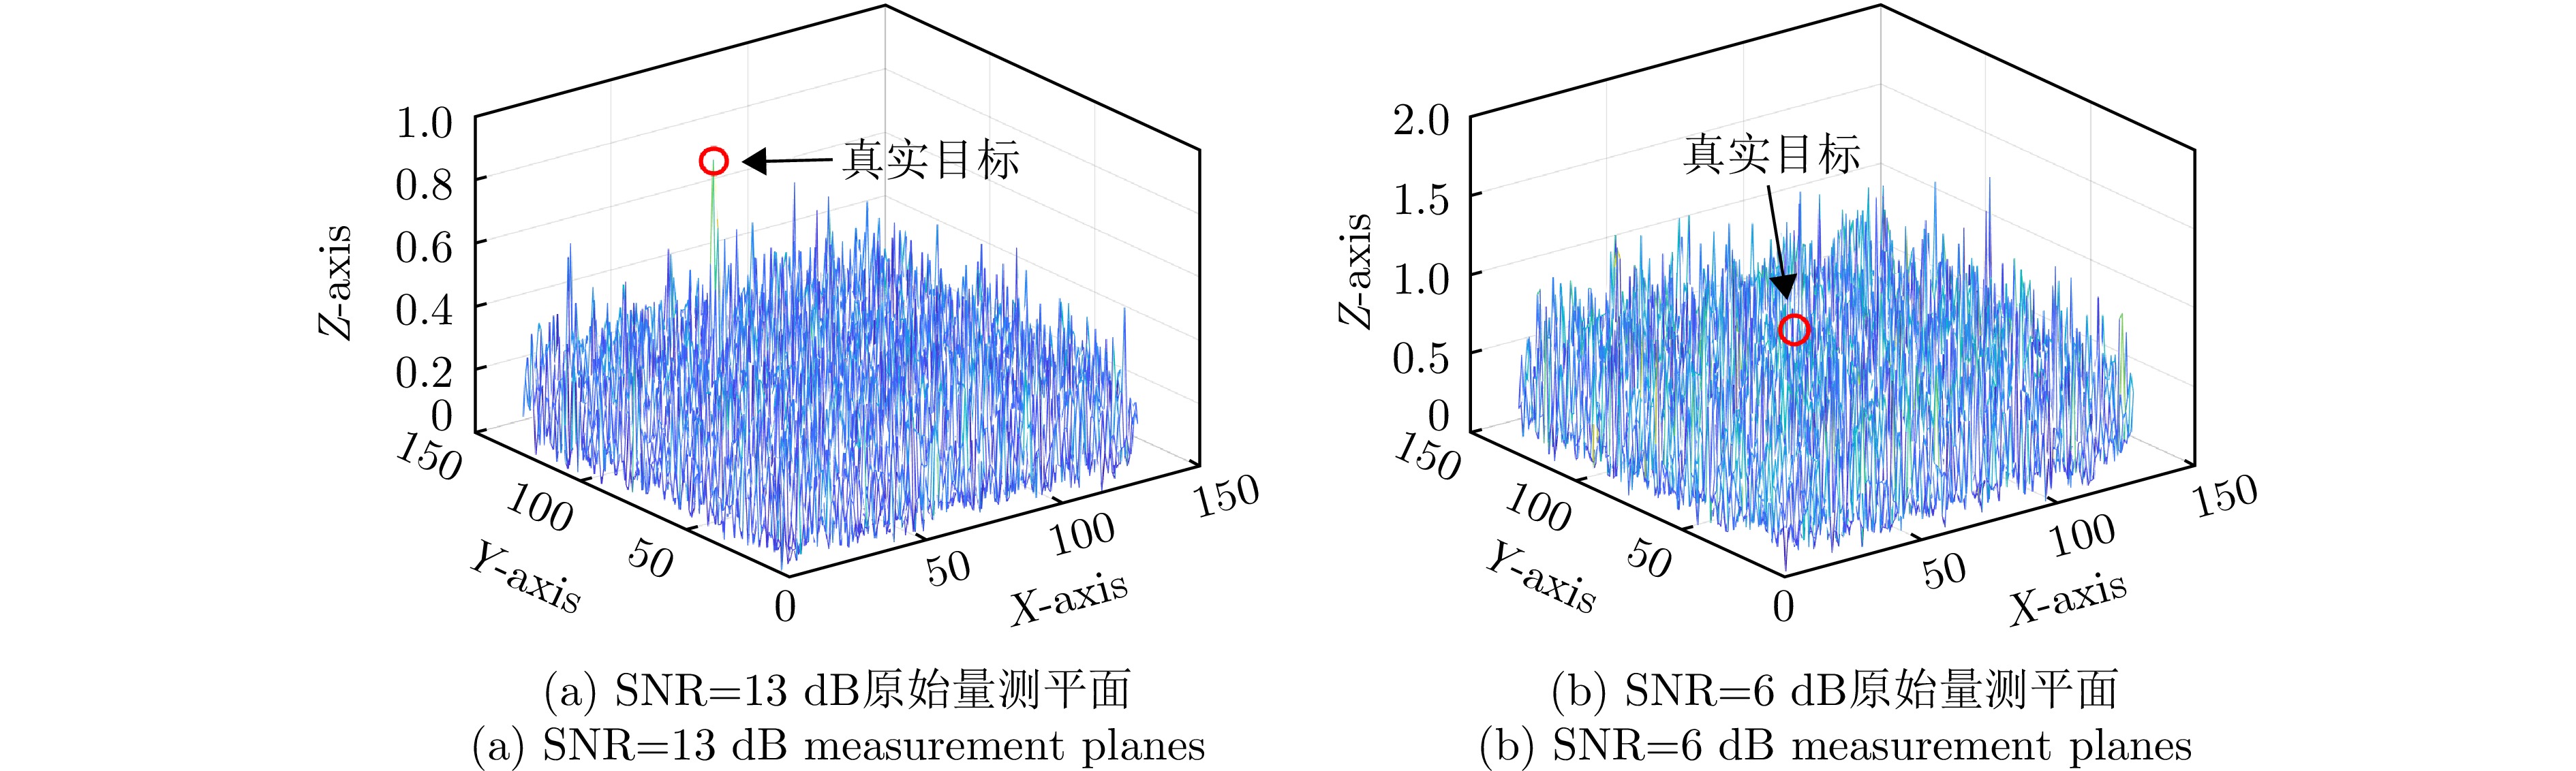
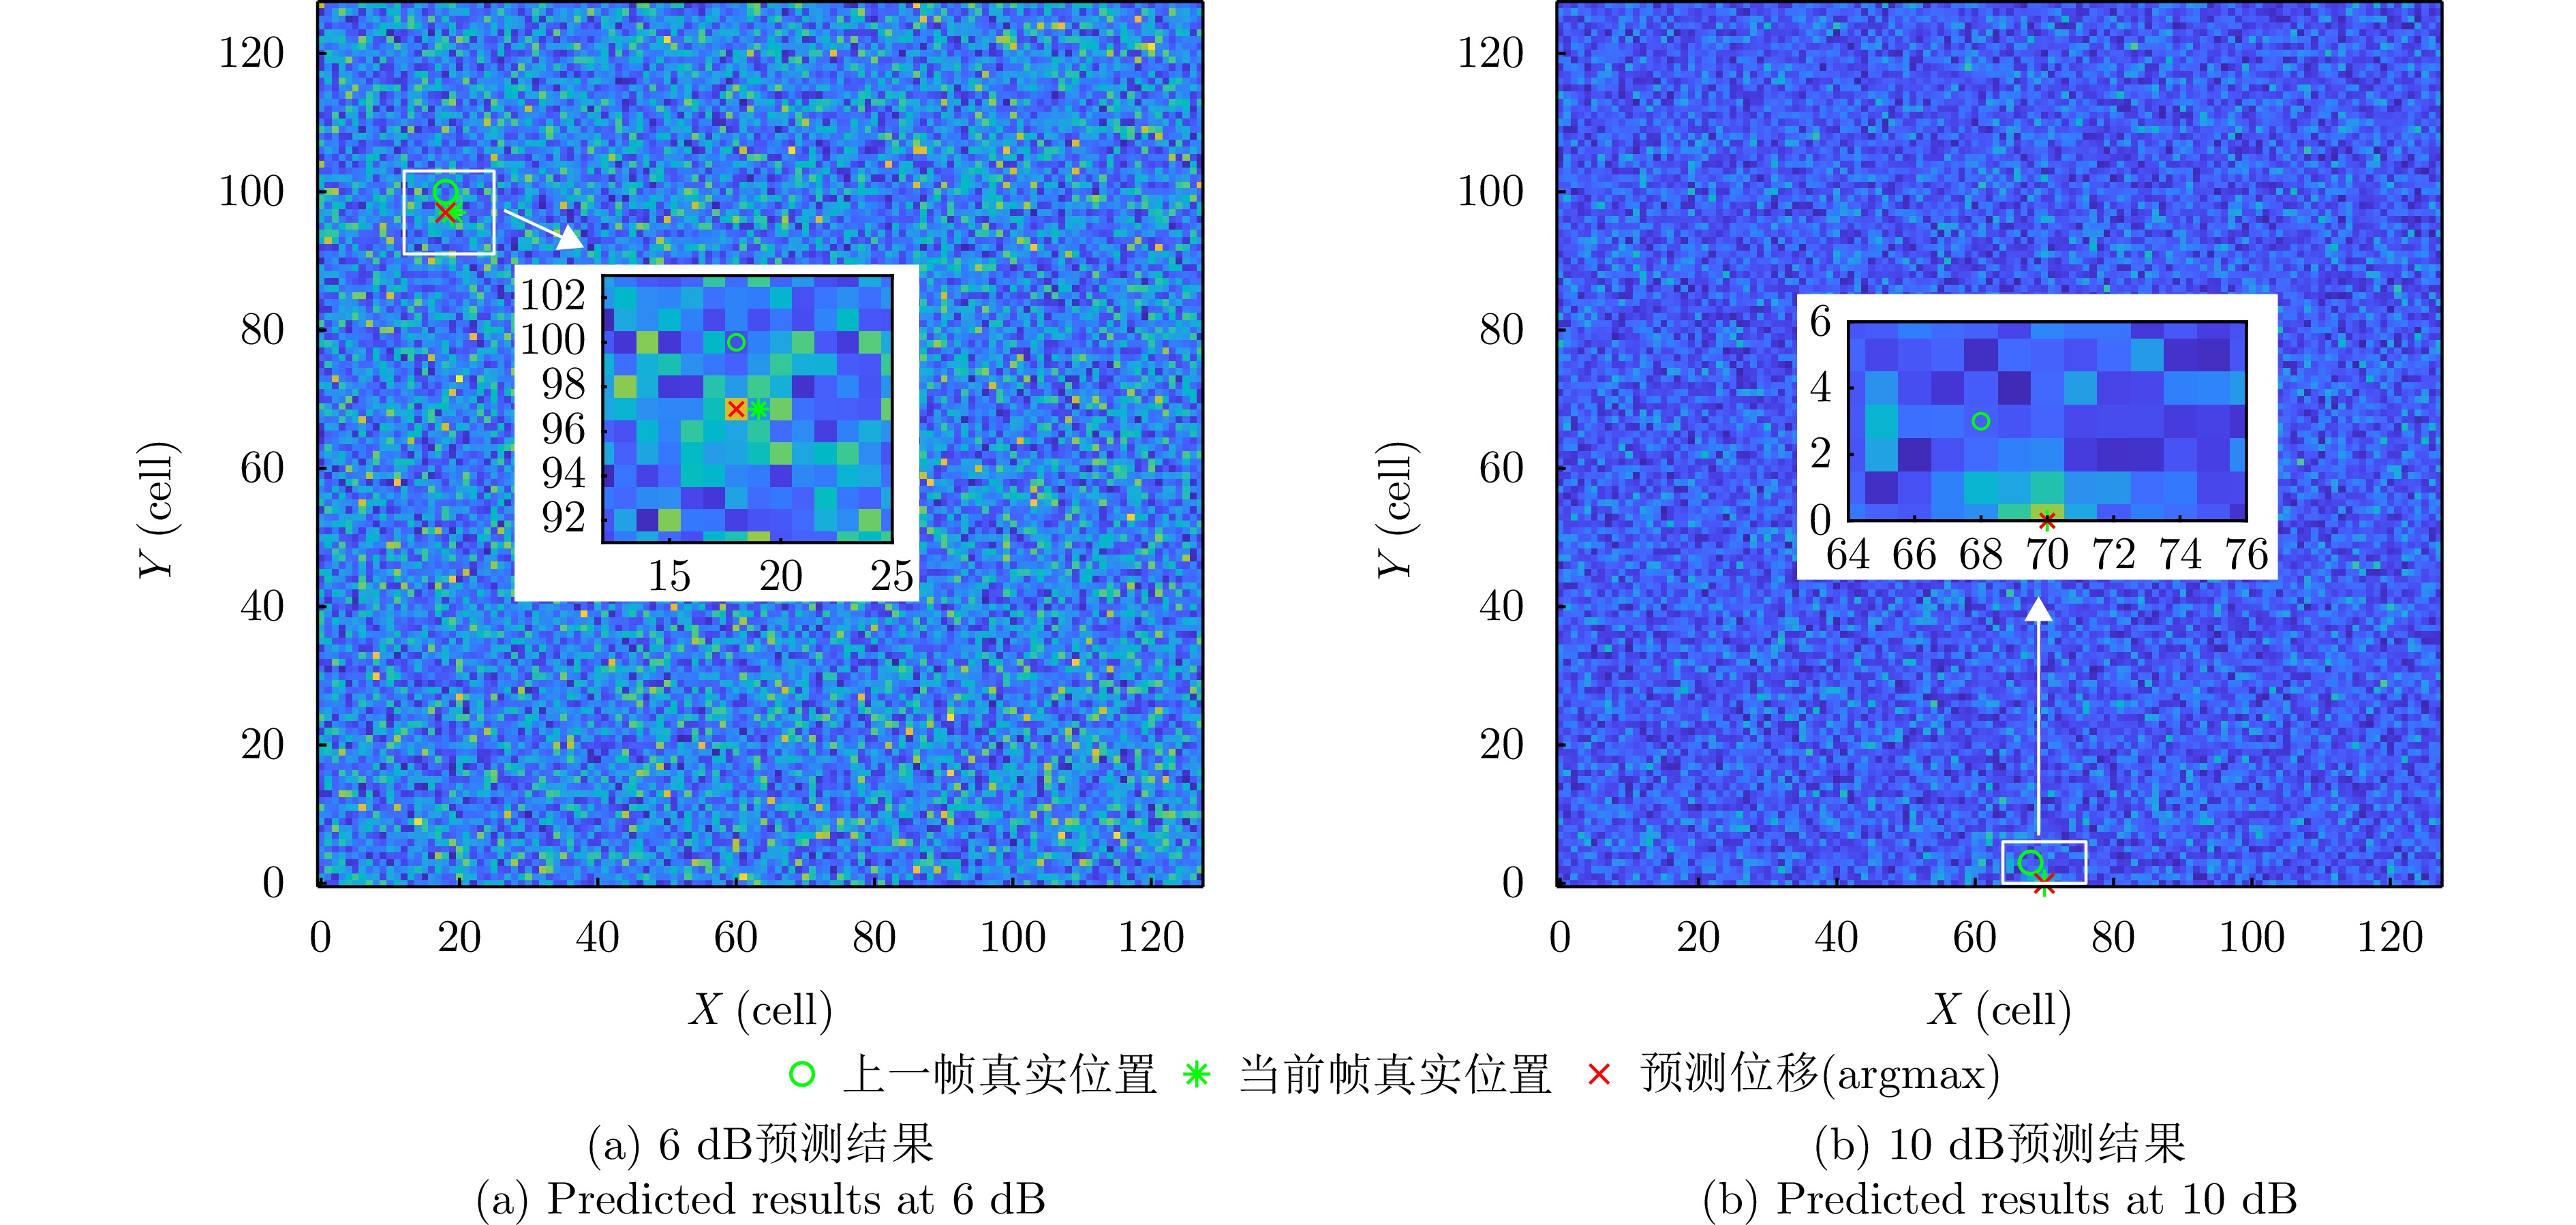
图 7 输入数据:不同信噪比下的原始量测平面
Figure 7. The raw measurement planes in different SNR conditions
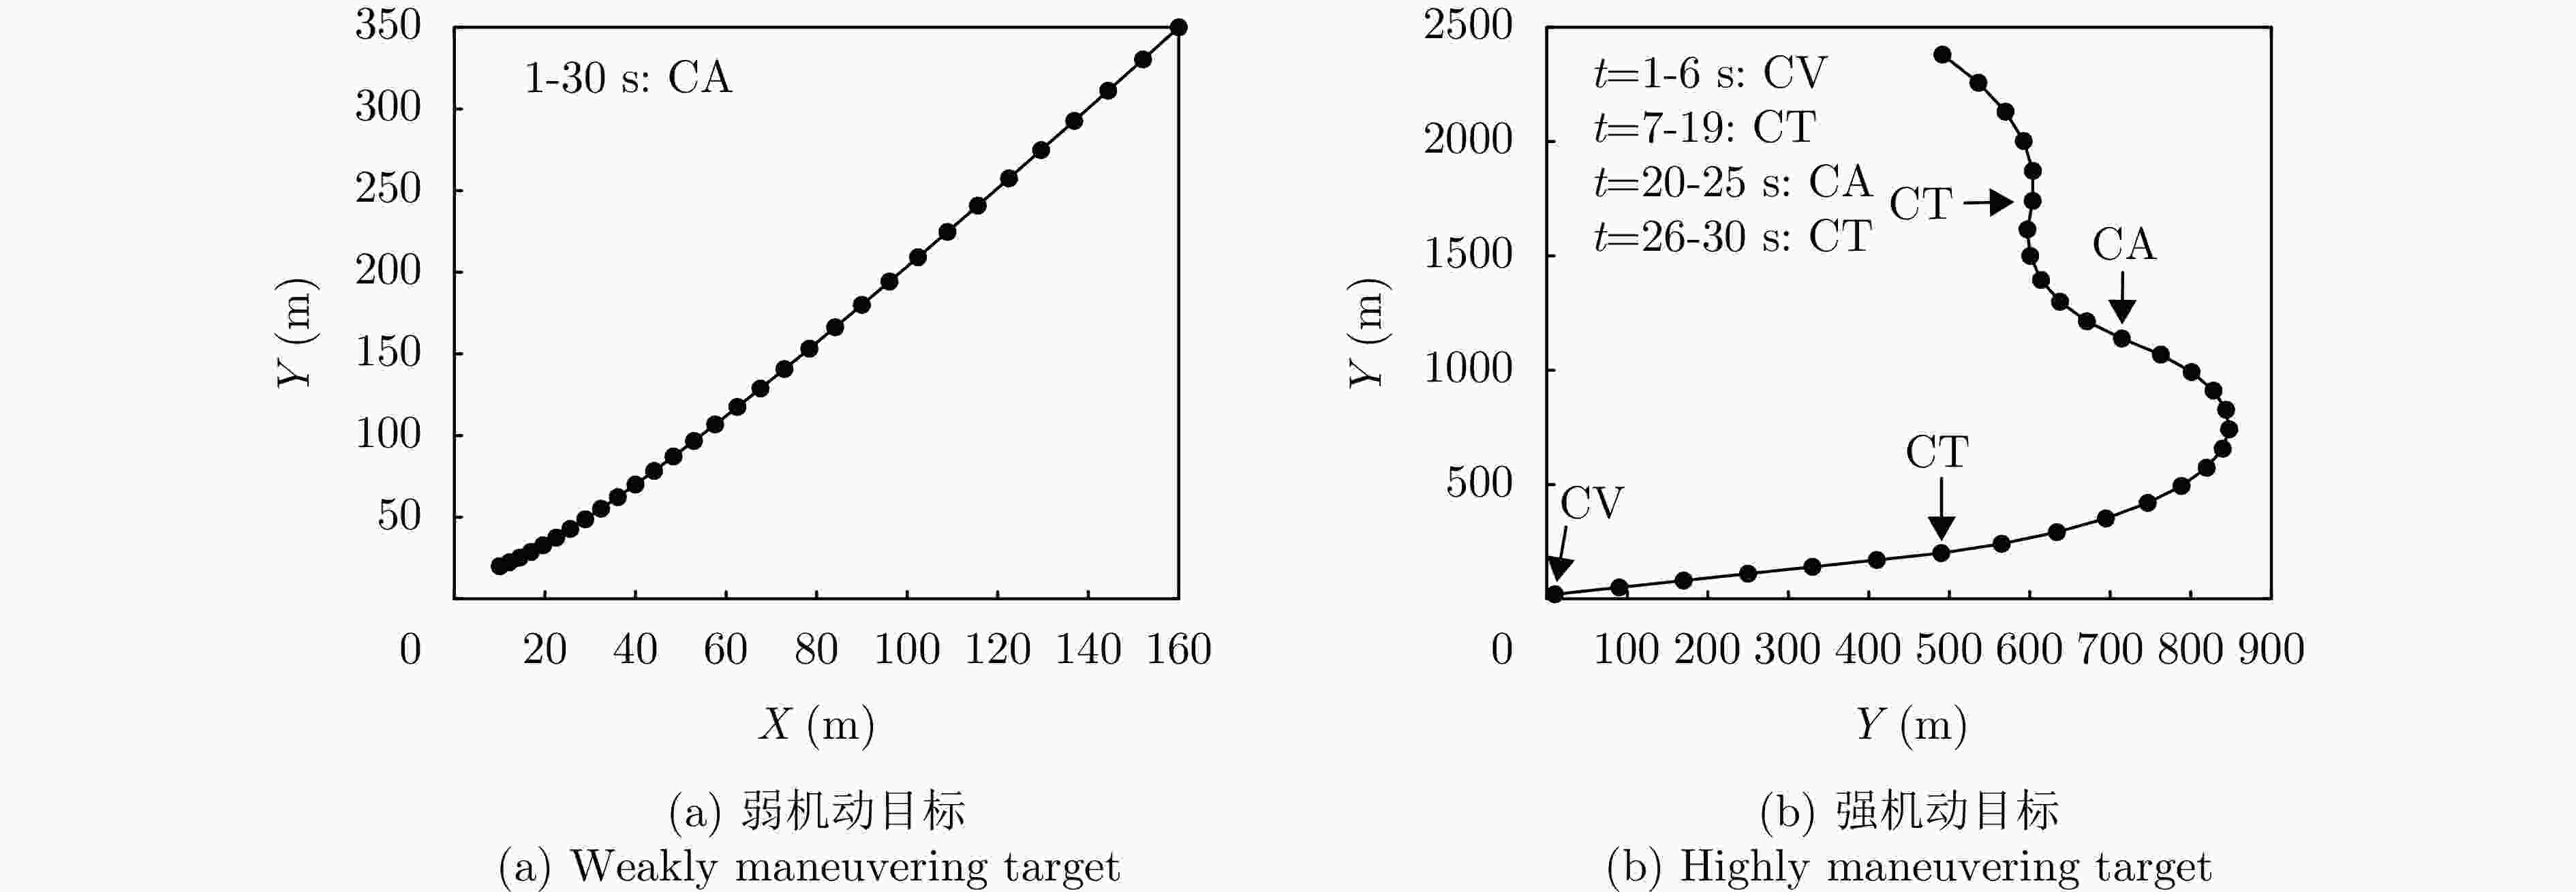
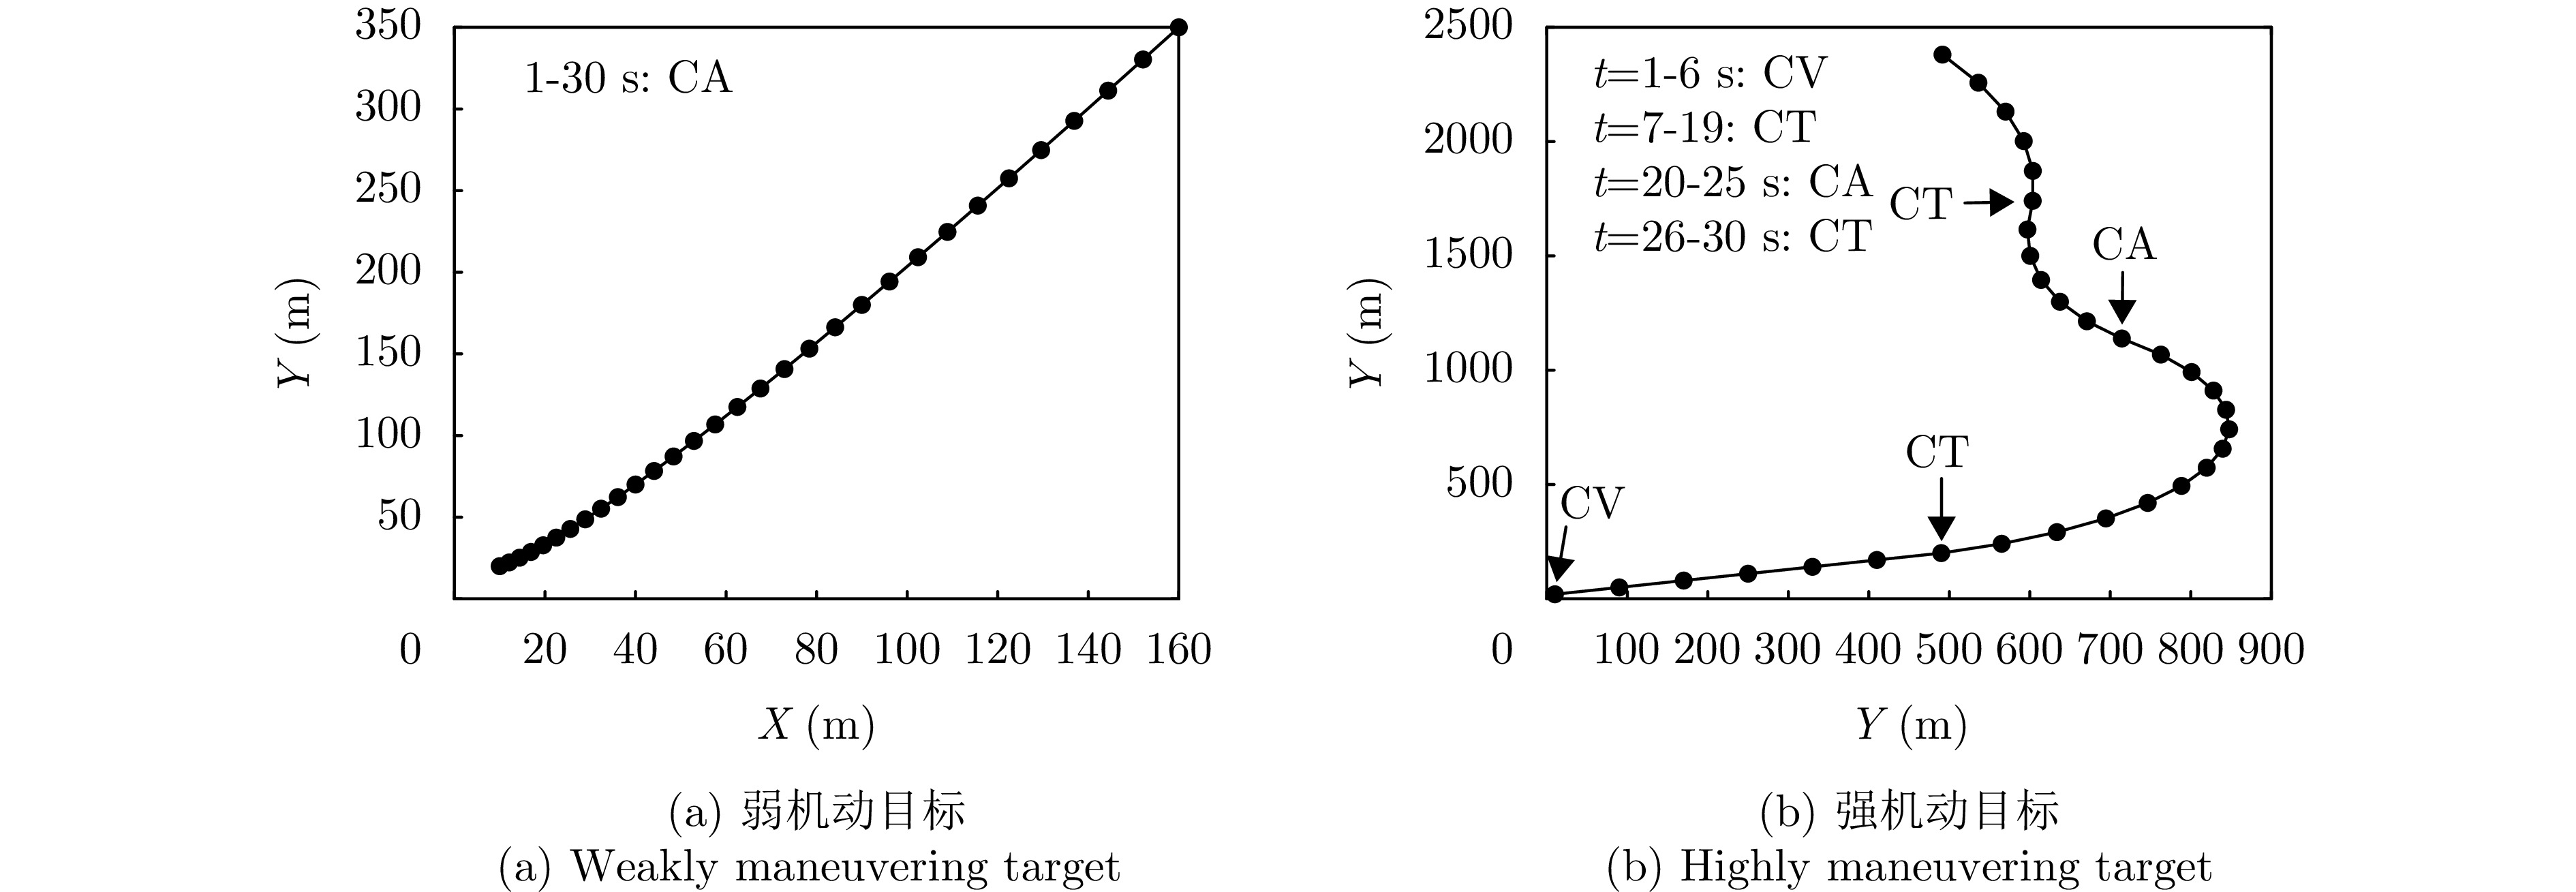
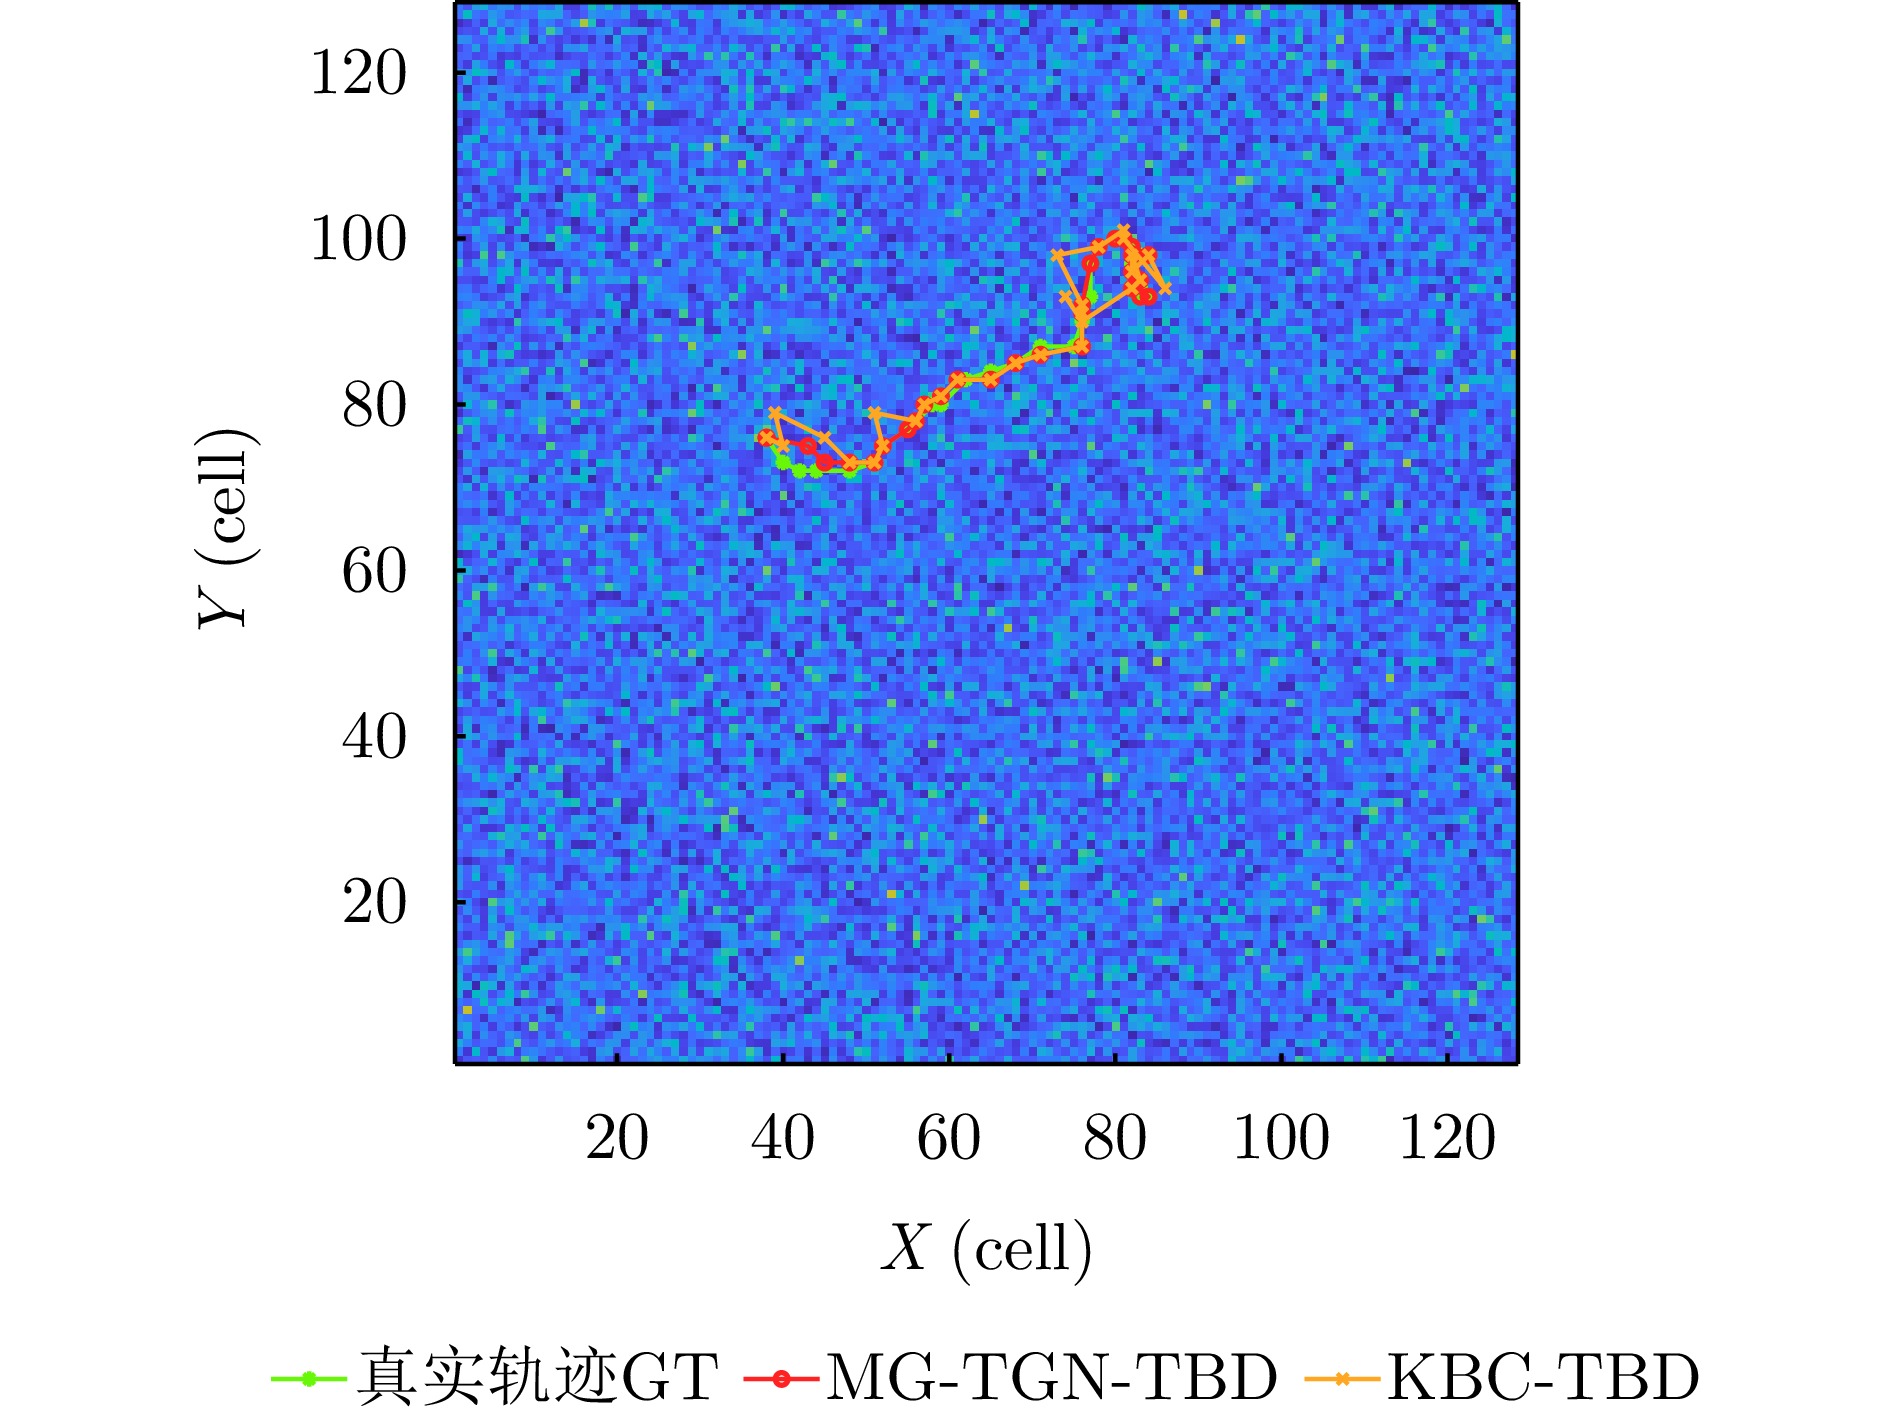
图 8 不同机动条件下的目标运动轨迹示意图
Figure 8. Target trajectories under different maneuvering conditions
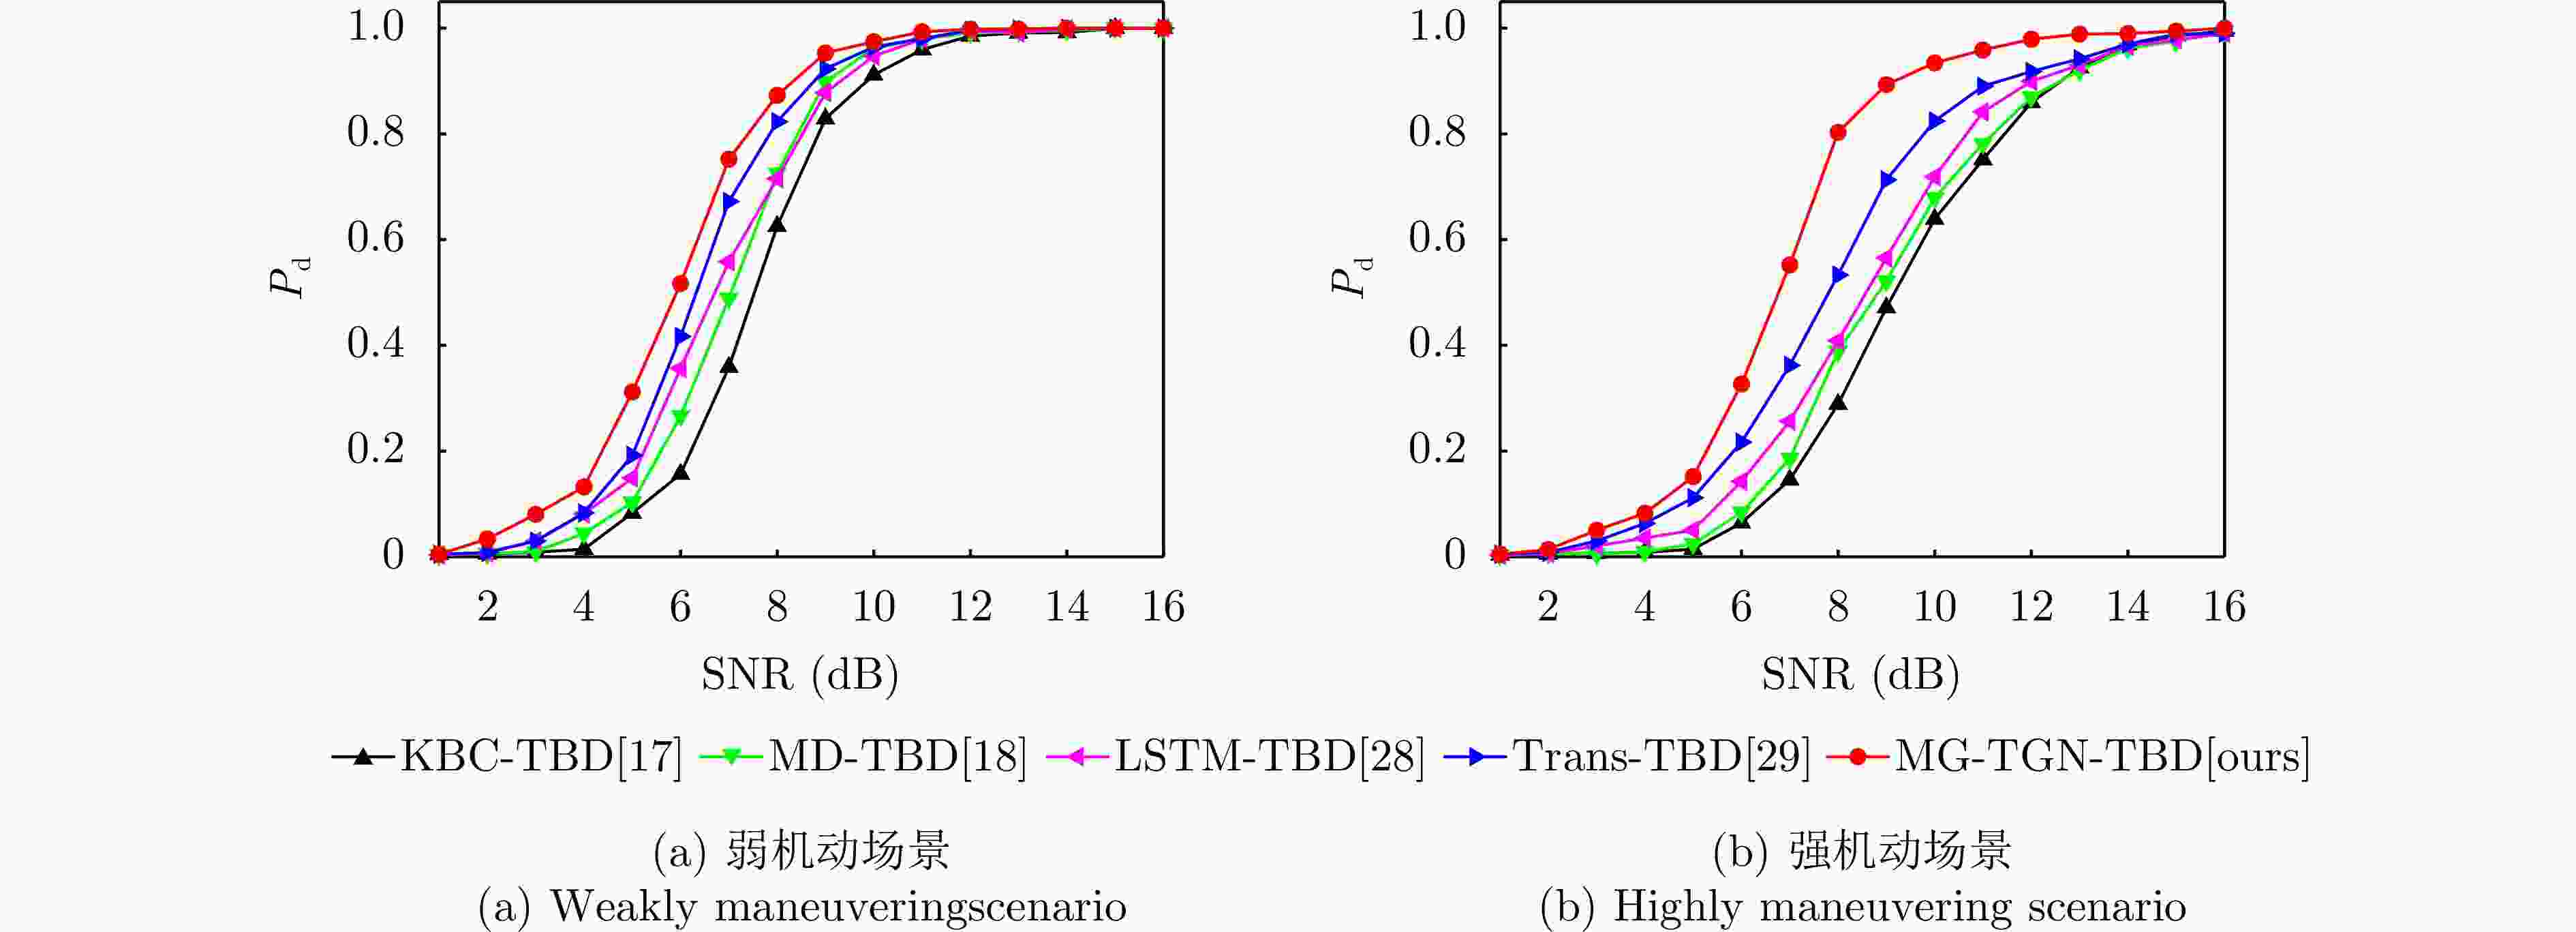
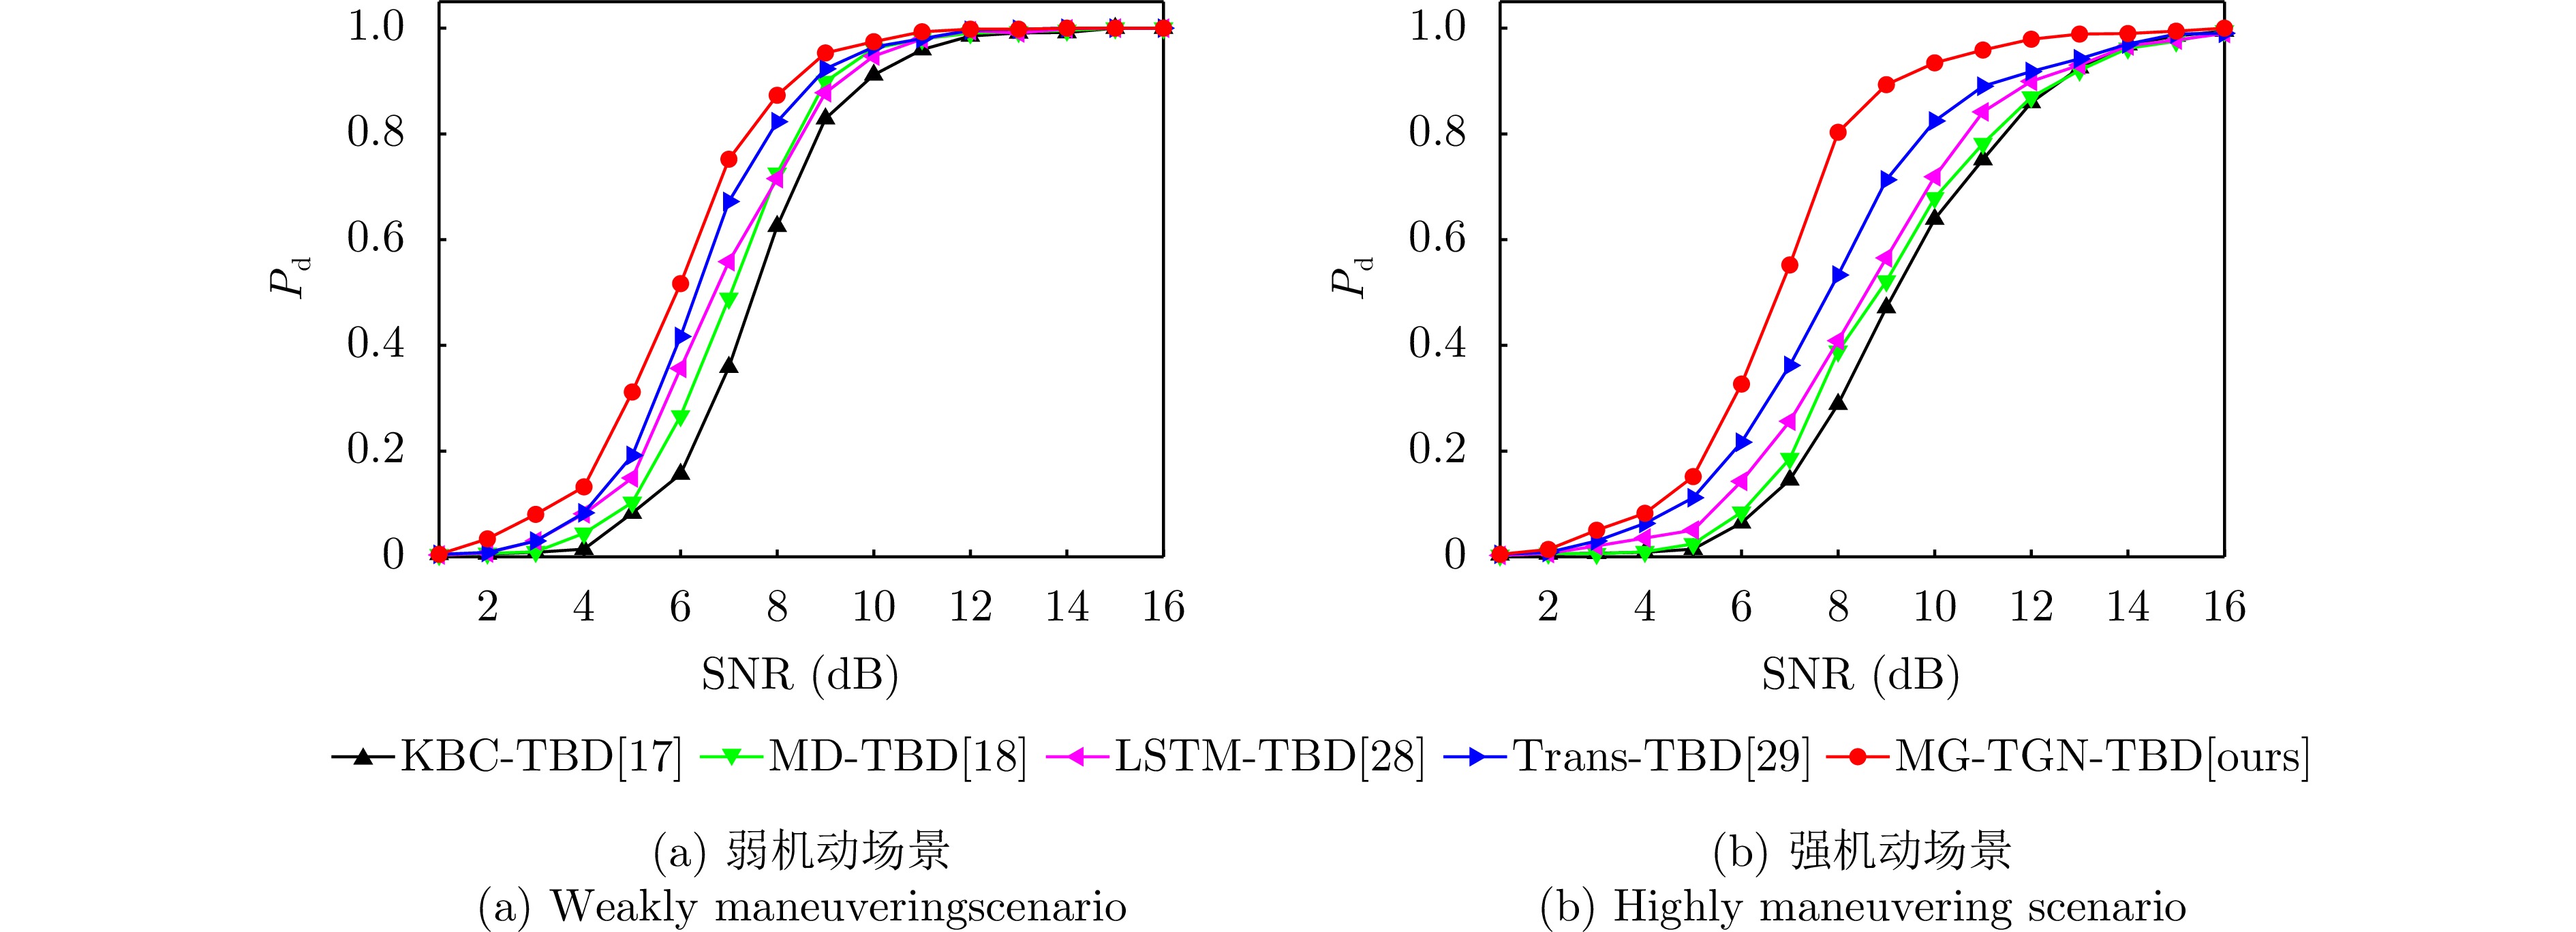
图 12 不同机动场景下的目标检测概率曲线
Figure 12. curves of $ {P}_{d} $ under different maneuvering scenarios
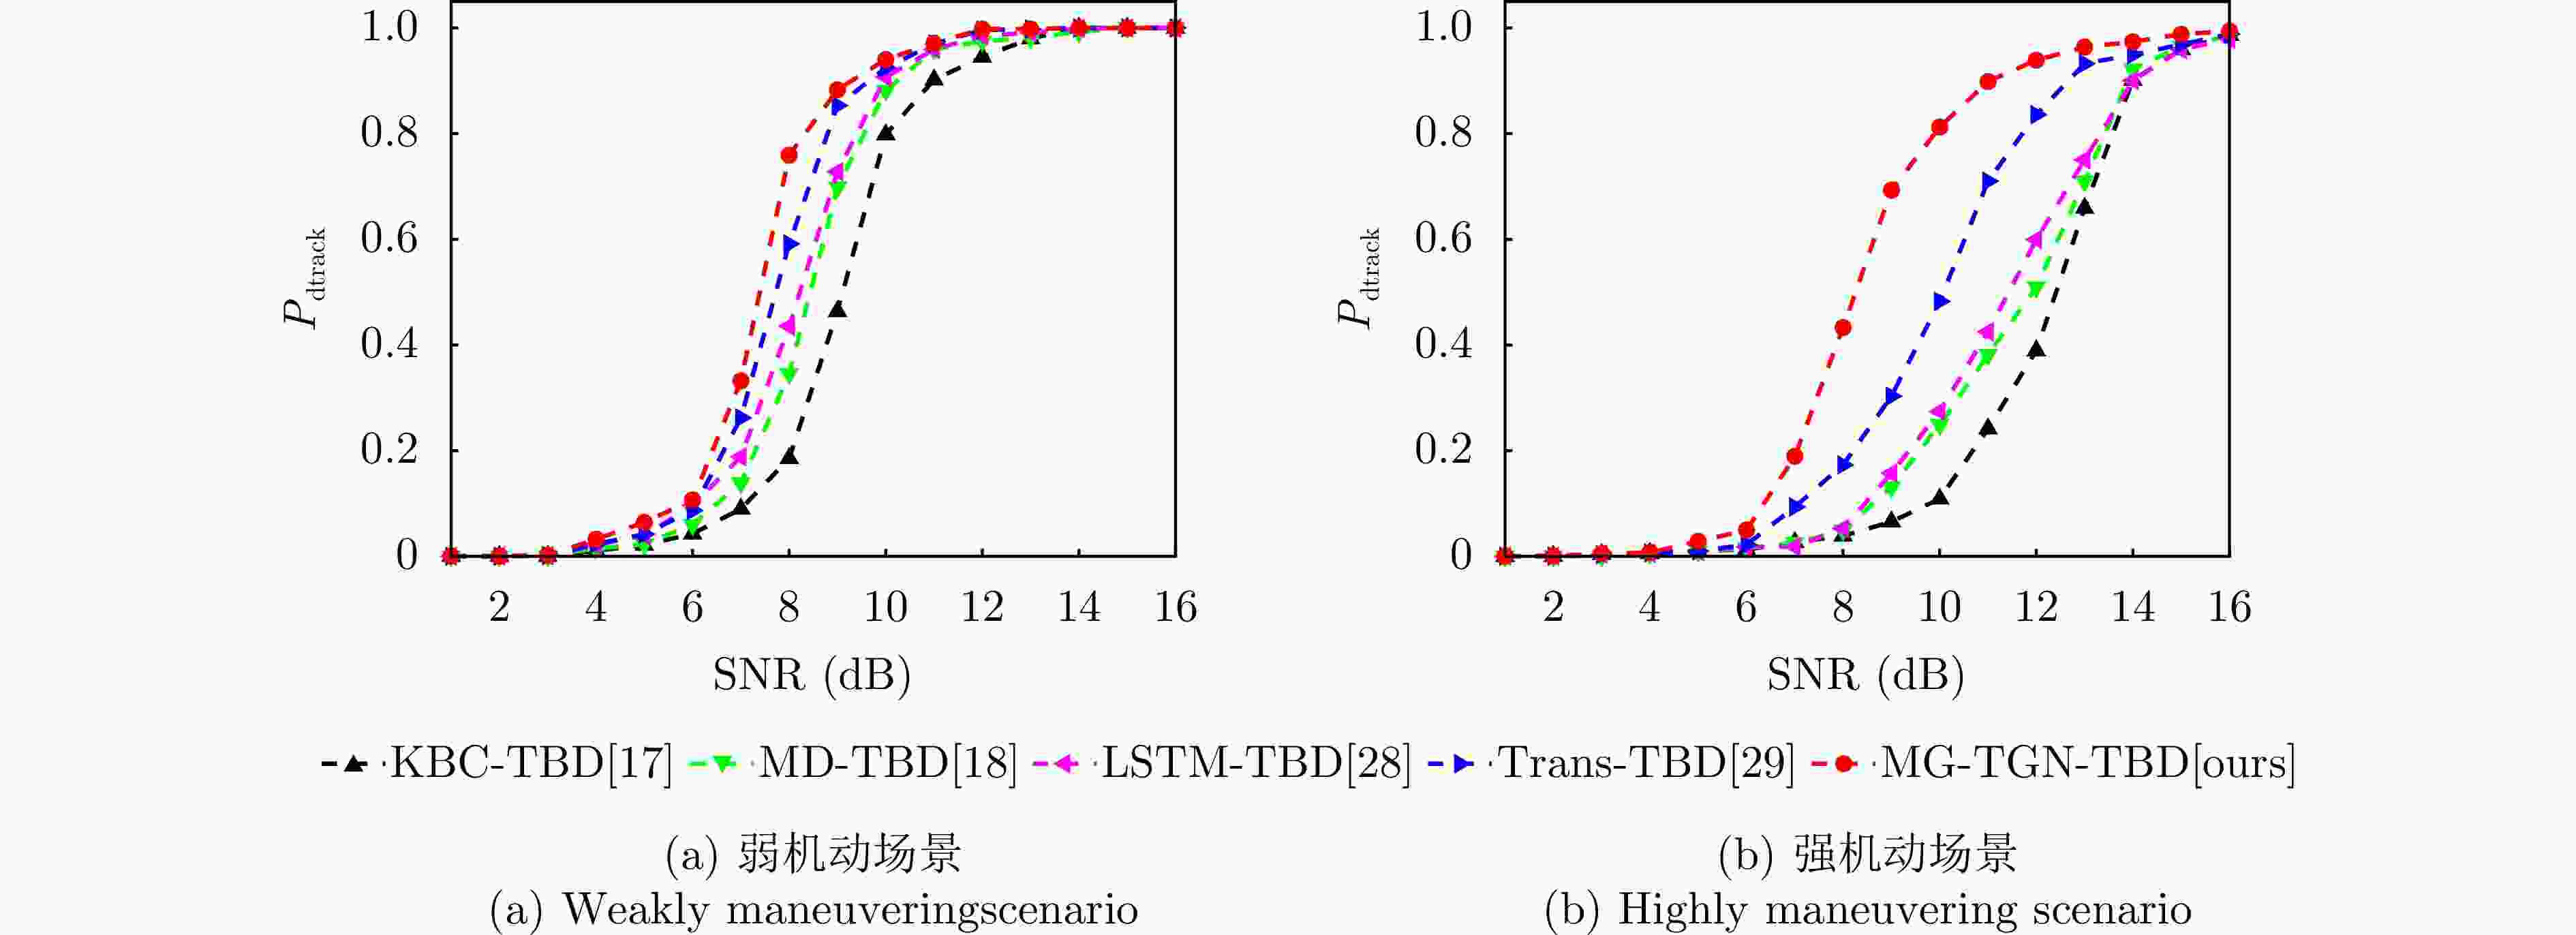
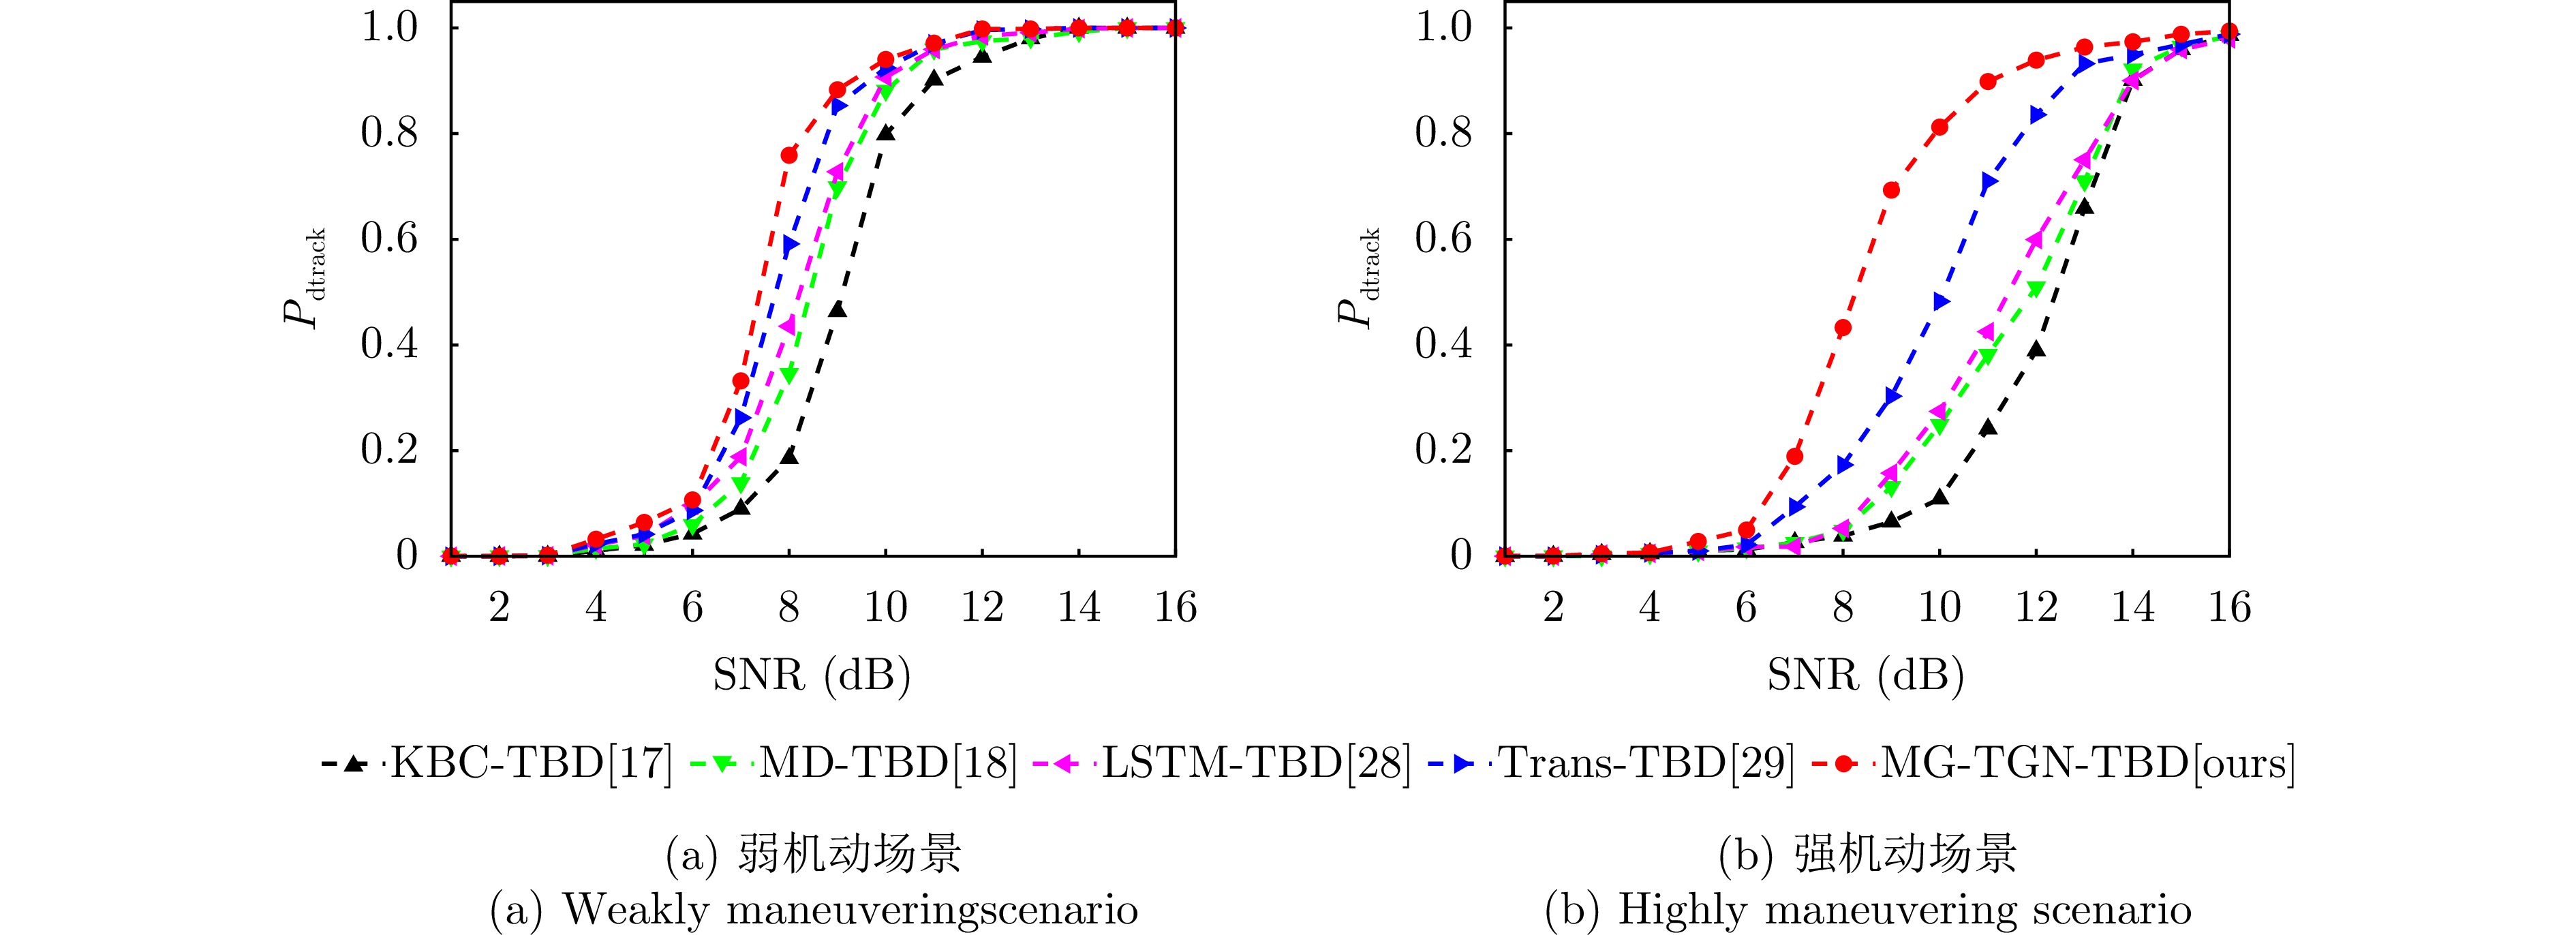
图 13 不同机动场景下的轨迹检测概率曲线
Figure 13. curves of $ {P}_{d-\text{track}} $ under different maneuvering scenarios
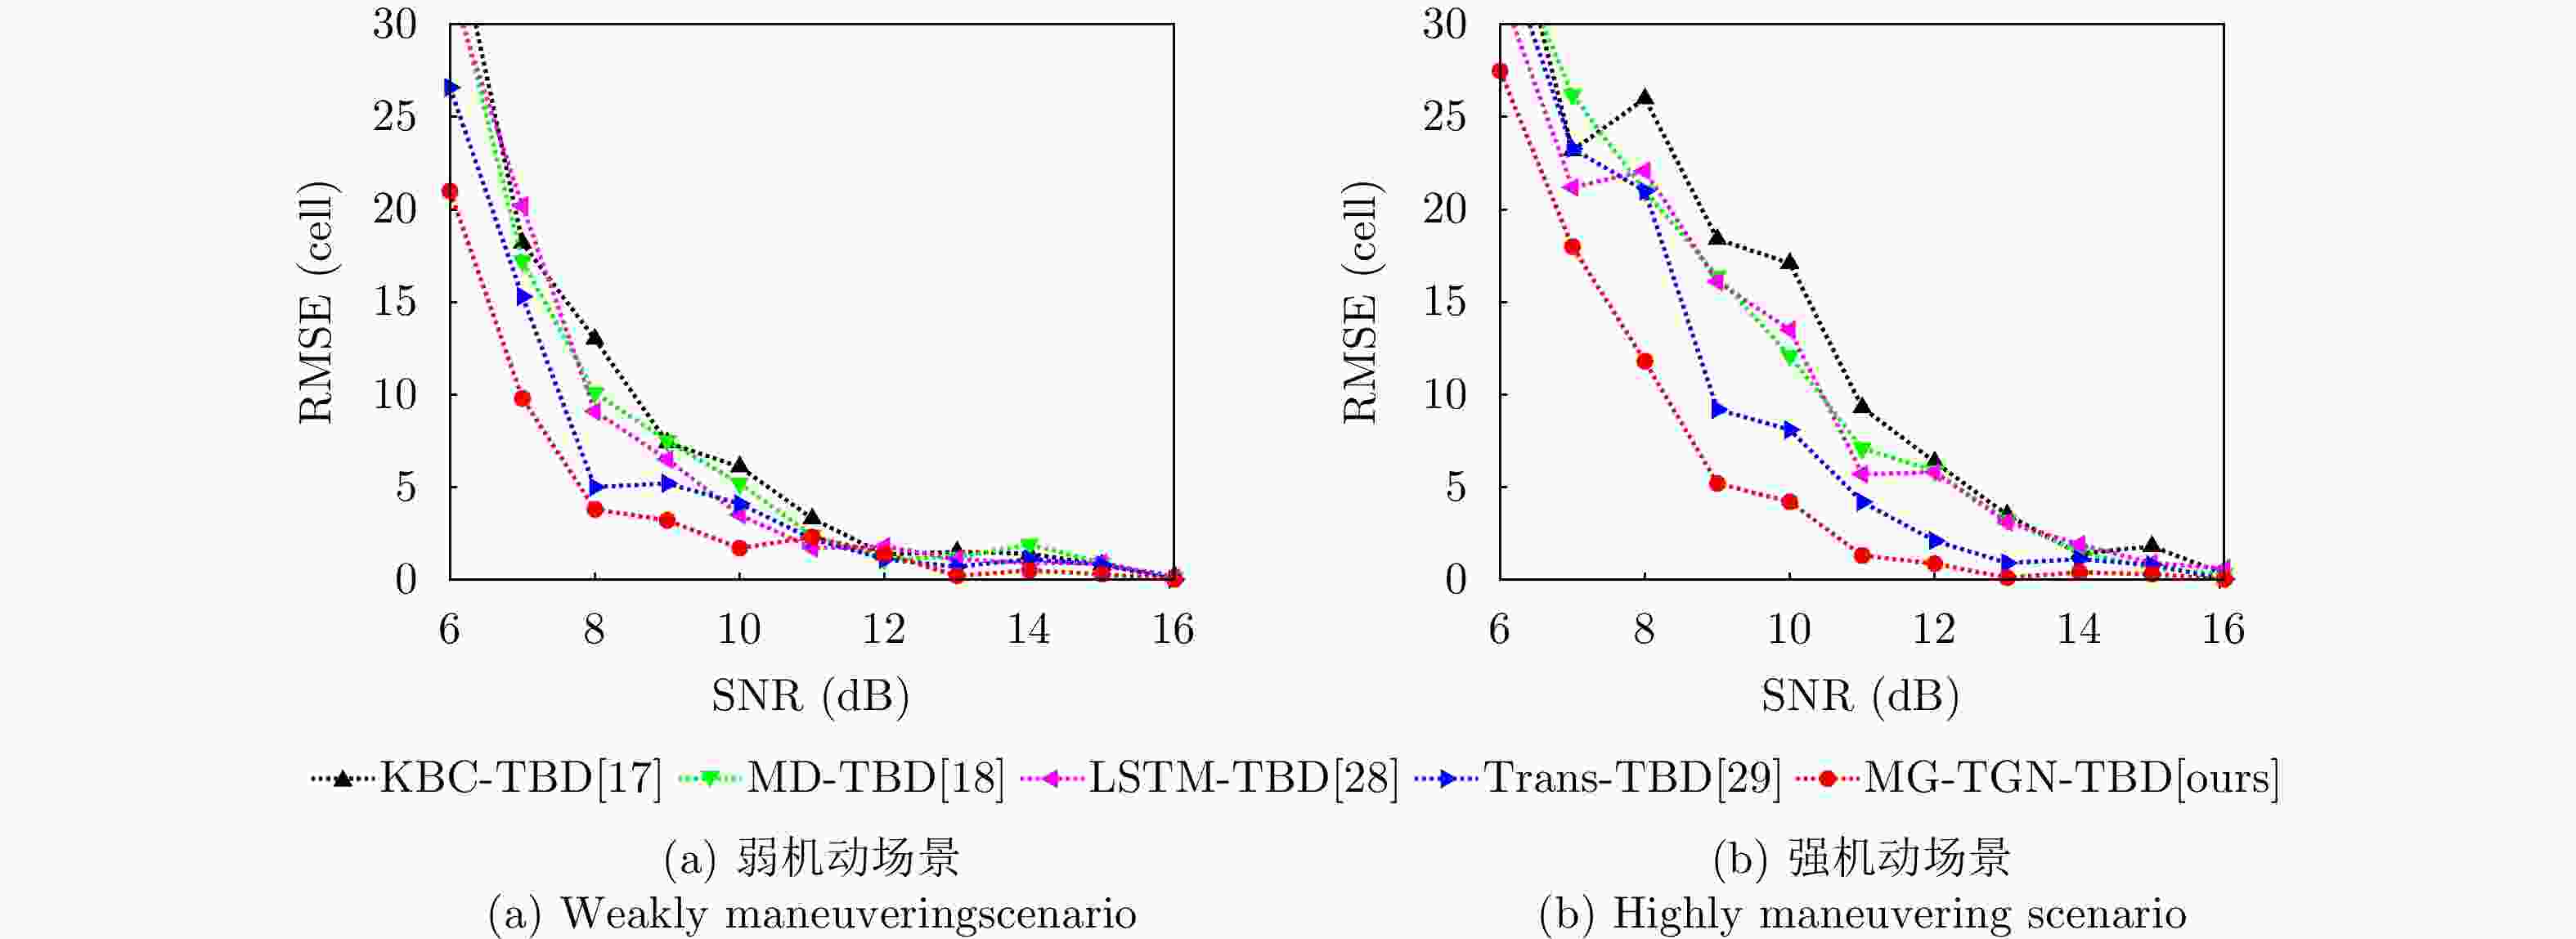
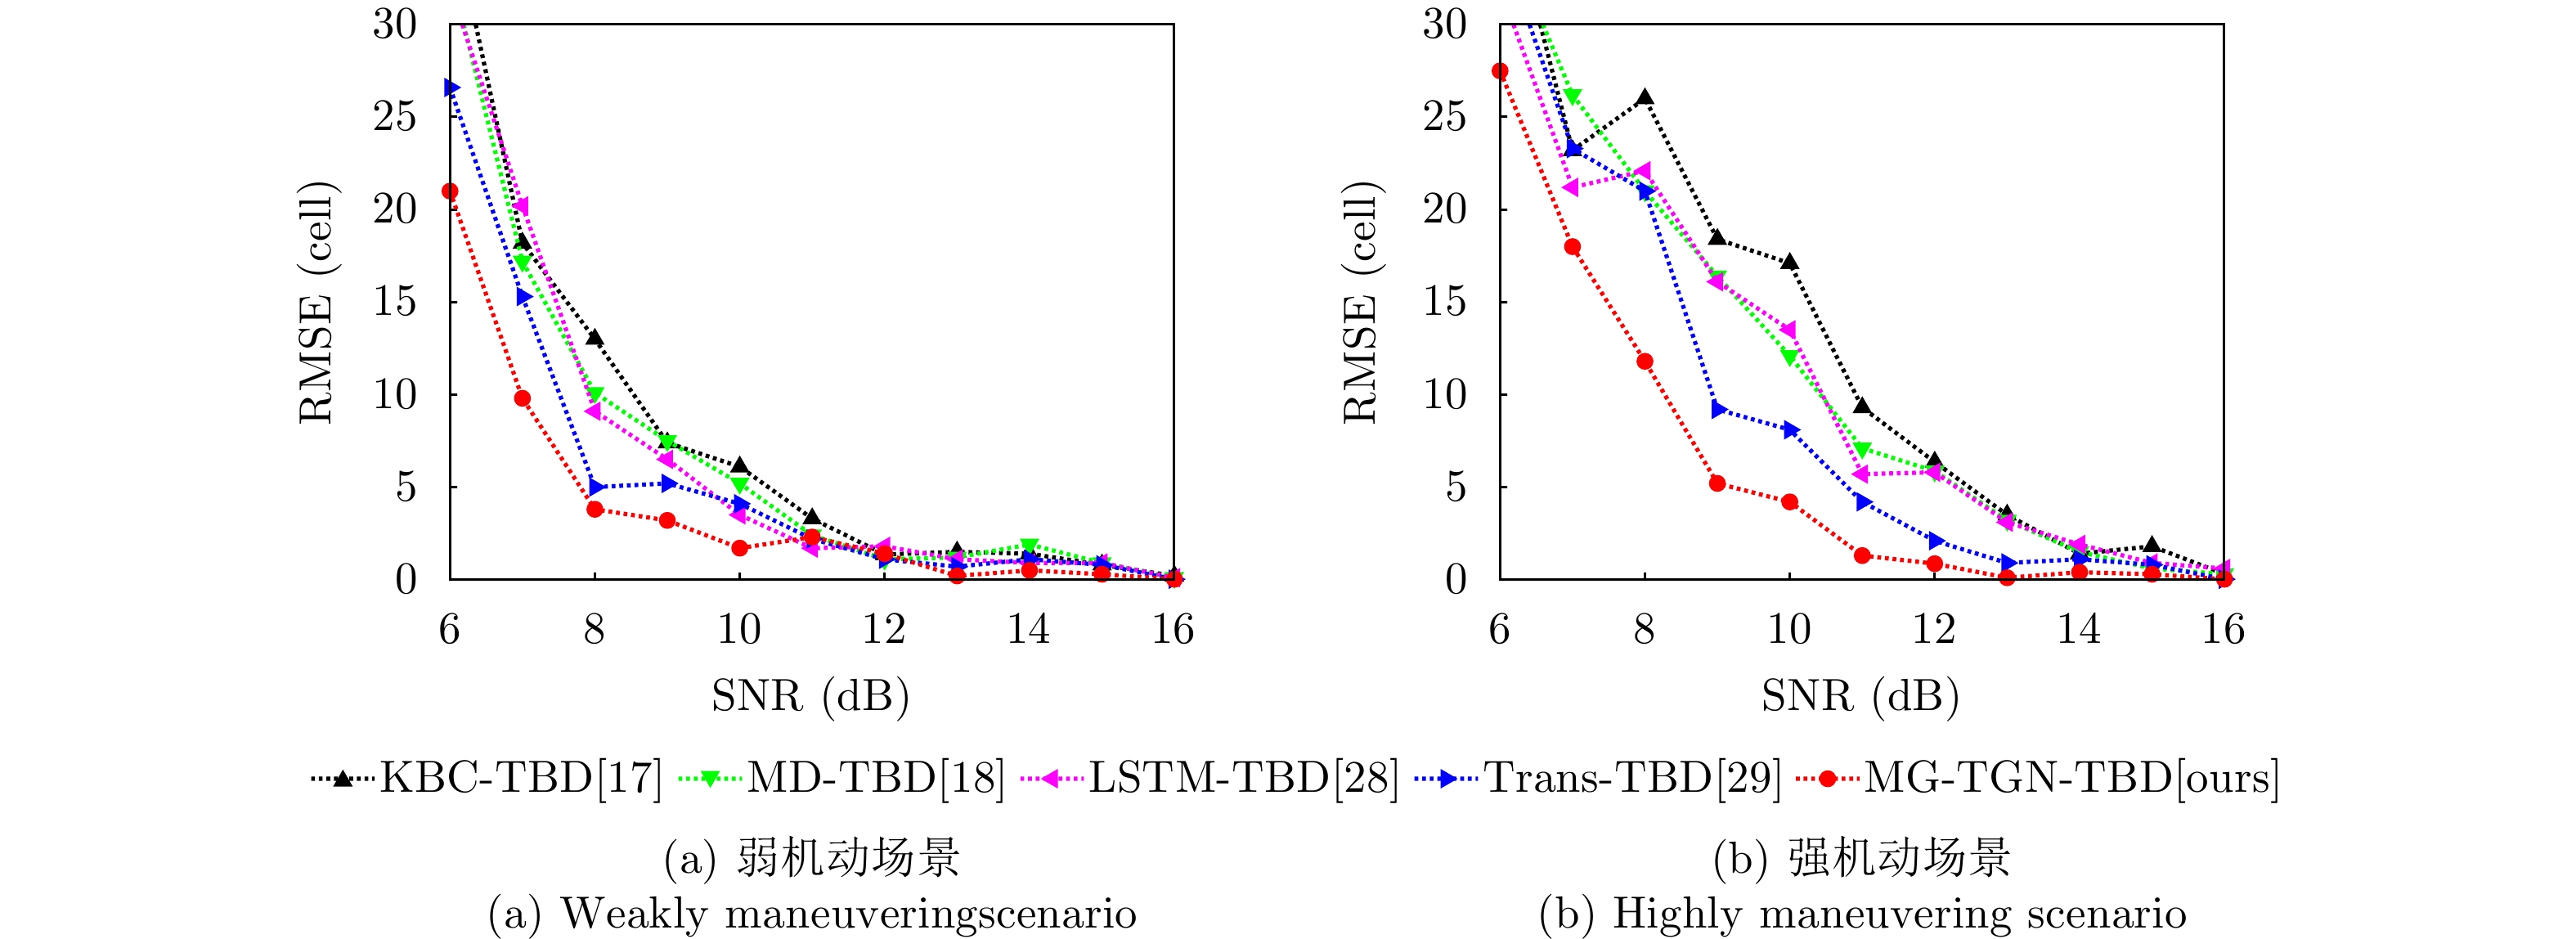
图 14 不同机动场景下的RMSE曲线
Figure 14. curves of $ \text{RMSE} $ under different maneuvering scenario
1 MG-TGN辅助的DP-TBD推理流程
1. Inference Pipeline of DP-TBD Using MG-TGN
1. 初始化值函数,利用宽门控DP递推和纯量测引导的MG-
TGN实现首个窗口初始化,得到轨迹序列$ {\hat{\bar{\mathbf{X}}}}_{1\colon K} $;2. while $ t+K-1\leq T $do 3. 窗口$ {W}_{t}\leftarrow [t,t+K-1] $ 4. 在窗口内执行DP递推: 5. 基于$ {W}_{t-1} $轨迹先验和量测信息及$ {\mathbf{z}}_{t} $ 6. MG-TGN输出$ {\pi }_{\text{upd}} $,构造候选转移集合$ {\mathcal{S}}_{k} $; 7. 根据公式(30),针对$ \Delta \in {\mathcal{S}}_{k} $更新值函数; 8. 记录轨迹回溯指针; 9. 阈值判决,轨迹回溯; 10. 下一滑窗迭代; 11. end while 12. 返回:整条轨迹序列$ {\hat{\bar{\mathbf{X}}}}_{1\colon N} $  下载: 导出CSV
表 1 不同机动条件下的目标运动参数
Table 1. Target motion parameters under different maneuvering conditions
参数 弱机动 强机动 速度约束$ ||{v}_{\max }|| $ $ 100\;\text{m/s} $ $ 400\;\text{m/s} $ 加速度$ ||{a}_{\max }|| $ $ 5\;{\text{m/s}}^{2} $ $ 40\;{\text{m/s}}^{2} $ 转弯率$ ||{\omega }_{\max }|| $ $ 0.05\pi $ $ 0.3\pi $ 切换概率$ {p}_{\text{turn}} $ 0.01 0.25
下载: 导出CSV
表 2 MG-TGN关键网络参数
Table 2. The key parameters of MG-TGN
参数 数值 序列长度 8 轨迹编码器层数 4 量测编码器层数 4 解码器层数 4 特征维度 192 多头注意力头数 8 前馈神经网络维度 512 Dropout 0.1 位移预测头MLP层数 3 位移预测头隐藏维度 256
下载: 导出CSV
表 3 模型训练参数
Table 3. Model training parameters
参数 数值 优化器 AdamW 初始学习率 $ 5\times {10}^{-4} $ 学习率策略 余弦退火 权重衰减 $ 1\times {10}^{-4} $ Batchsize 32 辅助损失权重 0.25
下载: 导出CSV
表 4 平均运行时间对比
Table 4. Comparison of average execution times
方法 平均运行时间(ms) KBC-TBD 759.1 MD-TBD 595.5 LSTM-TBD 383.4 Trans-TBD 407.5 MG-TGN-TBD 342.3
下载: 导出CSV
表 5 消融实验结果
Table 5. Results of ablation experiment
模型变体 位移估计 量测引导 $ {P}_{d} $ 完整MG-TGN √ √ 0.837 w/o 位移估计 √ × 0.743 w/o量测引导 × √ 0.512
下载: 导出CSV
-
[1] JALIL A, YOUSAF H, and BAIG M I. Analysis of CFAR techniques[C]. The 13th International Bhurban Conference on Applied Sciences and Technology (IBCAST), Islamabad, Pakistan, 2016: 654–659. doi: 10.1109/IBCAST.2016.7429949. [2] BARNIV Y. Dynamic programming solution for detecting dim moving targets[J]. IEEE Transactions on Aerospace and Electronic Systems, 1985, AES-21(1): 144–156. doi: 10.1109/TAES.1985.310548. [3] BOCQUEL M, DRIESSEN H, and BAGCHI A. Multitarget particle filter addressing ambiguous radar data in TBD[C]. 2012 IEEE Radar Conference, Atlanta, USA, 2012: 575–580. doi: 10.1109/RADAR.2012.6212206. [4] GARCIA F J I, MANDAL P K, BOCQUEL M, et al. Riemann–Langevin particle filtering in track-before-detect[J]. IEEE Signal Processing Letters, 2018, 25(7): 1039–1043. [5] LI Yuefeng, ZHANG Xiangyu, WANG Guohong, et al. A novel HT-TBD detection approach for near-space target[C]. The 3rd IEEE International Conference on Computer and Communications (ICCC), Chengdu, China, 2017: 1720–1724. doi: 10.1109/CompComm.2017.8322834. [6] YI Wei, KONG Lingjiang, YANG Jianyu, et al. A modified dynamic programming approach for dim target detection and tracking[C]. The 2nd International Congress on Image and Signal Processing, Tianjin, China, 2009: 1–5. doi: 10.1109/CISP.2009.5300953. [7] 易伟. 基于检测前跟踪技术的多目标跟踪算法研究[D]. [博士论文], 电子科技大学, 2012.YI Wei. Research on track-before-detect algorithms for multiple-target detection and tracking[D]. [Ph.D. dissertation], University of Electronic Science and Technology of China, 2012. [8] YI Wei, MORELANDE M R, KONG Lingjiang, et al. An efficient multi-frame track-before-detect algorithm for multi-target tracking[J]. IEEE Journal of Selected Topics in Signal Processing, 2013, 7(3): 421–434. doi: 10.1109/JSTSP.2013.2256415. [9] 方梓成. 多帧联合检测与跟踪技术研究[D]. [硕士论文], 电子科技大学, 2017.FANG Zicheng. Research on multi-frame detection and tracking technique[D]. [Master dissertation], University of Electronic Science and Technology of China, 2017. [10] 陆晓莹. 基于动态规划的雷达弱目标检测前跟踪算法研究[D]. [博士论文], 电子科技大学, 2023. doi: 10.27005/d.cnki.gdzku.2023.005491.LU Xiaoying. Research on track-before-detect algorithm based on dynamic programming for weak target with radar[D]. [Ph.D. dissertation], University of Electronic Science and Technology of China, 2023. doi: 10.27005/d.cnki.gdzku.2023.005491. [11] CAI Jiong, WANG Rui, LI Muyang, et al. An efficient threshold determination algorithm for DP-TBD based on structural analogy and saddle-point approximation[J]. IEEE Transactions on Aerospace and Electronic Systems, 2023, 59(6): 8263–8281. doi: 10.1109/TAES.2023.3301458. [12] LI Wujun, YI Wei, TEH K C, et al. Radar multiframe detection in a complicated multitarget environment[J]. IEEE Transactions on Geoscience and Remote Sensing, 2023, 61: 5107516. doi: 10.1109/TGRS.2023.3298040. [13] LI X R and JILKOV V P, Survey of maneuvering target tracking. Part I. Dynamic models[J]. IEEE Transactions on Aerospace and Electronic Systems, 2003, 39(4): 1333–1364. doi: 10.1109/TAES.2003.1261132. [14] LI Xinzhe, WANG Shouyong, and ZHENG Daikun. A DP-TBD algorithm with adaptive state transition set for maneuvering targets[C]. 2016 CIE International Conference on Radar (RADAR), Guangzhou, China, 2016: 1–4. doi: 10.1109/RADAR.2016.8059476. [15] FANG Zicheng, YI Wei, KONG Lingjiang, et al. A multi-frame track-before-detect algorithm for maneuvering targets in radar system[C]. 2016 IEEE Radar Conference (RadarConf), Philadelphia, USA, 2016: 1–6. [16] GROSSI E, LOPS M, and VENTURINO L. A novel dynamic programming algorithm for track-before-detect in radar systems[J]. IEEE Transactions on Signal Processing, 2013, 61(10): 2608–2619. doi: 10.1109/TSP.2013.2251338. [17] GROSSI E, LOPS M, and VENTURINO L. Track-before-detect for multiframe detection with censored observations[J]. IEEE Transactions on Aerospace and Electronic Systems, 2014, 50(3): 2032–2046. doi: 10.1109/TAES.2013.130148. [18] YI Wei, FANG Zicheng, LI Wujun, et al. Multi-frame track-before-detect algorithm for maneuvering target tracking[J]. IEEE Transactions on Vehicular Technology, 2020, 69(4): 4104–4118. doi: 10.1109/TVT.2020.2976095. [19] ZHENG Daikun, WANG Shouyong, and MENG Qingwen. Dynamic programming track-before-detect algorithm for radar target detection based on polynomial time series prediction[J]. IET Radar, Sonar & Navigation, 2016, 10(8): 1327–1336. [20] ZHENG Daikun, XU Hong, and ZHOU Chang. Maneuvering target joint detection and tracking using multi-frame integration[C]. 2019 International Conference on Control, Automation and Information Sciences, Chengdu, China, 2019: 1–6. doi: 10.1109/ICCAIS46528.2019.9074565. [21] XIONG Yan, PENG Jiaxiong, DING Mingyue, et al. An extended track-before-detect algorithm for infrared target detection[J]. IEEE Transactions on Aerospace and Electronic Systems, 1997, 33(3): 1087–1092. doi: 10.1109/7.599339. [22] WANG Yizhou, JIANG Zhongyu, LI Yudong, et al. RODNet: A real-time radar object detection network cross-supervised by camera-radar fused object 3D localization[J]. IEEE Journal of Selected Topics in Signal Processing, 2021, 15(4): 954–967. doi: 10.1109/JSTSP.2021.3058895. [23] DECOURT C, VANRULLEN R, SALLE D, et al. DAROD: A deep automotive radar object detector on range-Doppler maps[C]. 2022 IEEE Intelligent Vehicles Symposium (IV), Aachen, Germany, 2022: 112–118. doi: 10.1109/IV51971.2022.9827281. [24] WU Yuanhang, ZHANG Chenyu, LIN Yiru, et al. CV-SAGAN: Complex-valued self-attention GAN on radar clutter suppression and target detection[C]. 2023 IEEE Radar Conference (RadarConf23), San Antonio, USA, 2023: 1–6. doi: 10.1109/RadarConf2351548.2023.10149701. [25] YATAKA R, CARDACE A, WANG Pu, et al. RETR: Multi-view radar detection transformer for indoor perception[C]. The 38th International Conference on Neural Information Processing Systems, Vancouver, Canada, 2024: 625. [26] DECOURT C, VANRULLEN R, SALLE D, et al. A recurrent CNN for online object detection on raw radar frames[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(10): 13432–13441. doi: 10.1109/TITS.2024.3404076. [27] ZHU Chuan, DENG Jie, LONG Xingyue, et al. DBU-Net based robust target detection for multi-frame track-before-detect method[C]. The 11th International Conference on Control, Automation and Information Sciences (ICCAIS), Hanoi, Vietnam, 2022: 412–418. doi: 10.1109/ICCAIS56082.2022.9990429. [28] SONG Fei, LI Yong, CHENG Wei, et al. An improved dynamic programming tracking-before-detection algorithm based on LSTM network[J]. EURASIP Journal on Advances in Signal Processing, 2023, 2023(1): 57. doi: 10.1186/s13634-023-01020-3. [29] MOU Pan, MIAO Qing, ZHU Chuan, et al. Transformer architecture based multi-frame TBD algorithms for maneuvering targets[C]. The 12th International Conference on Control, Automation and Information Sciences (ICCAIS), Hanoi, Vietnam, 2023: 224–229. doi: 10.1109/ICCAIS59597.2023.10382246. [30] LEI Meng, WANG Yipeng, and ZHANG Ying. Highly maneuverable target recognition via contrastive-based time-frequency domain dynamic fusion[C]. IGARSS 2024 - 2024 IEEE International Geoscience and Remote Sensing Symposium, Athens, Greece, 2024: 9222–9226. doi: 10.1109/IGARSS53475.2024.10640849. -

计量
- 文章访问数:
- HTML全文浏览量:
- PDF下载量:
- 被引次数: 0