
 Submit Manuscript
 Peer Review
 Editor Work
- Home
- Articles & Issues
-
Data
- Dataset of Radar Detecting Sea
- SAR Dataset
- SARGroundObjectsTypes
- SARMV3D
- AIRSAT Constellation SAR Land Cover Classification Dataset
- 3DRIED
- UWB-HA4D
- LLS-LFMCWR
- FAIR-CSAR
- MSAR
- SDD-SAR
- FUSAR
- SpaceborneSAR3Dimaging
- Sea-land Segmentation
- SAR Multi-domain Ship Detection Dataset
- SAR-Airport
- Hilly and mountainous farmland time-series SAR and ground quadrat dataset
- SAR images for interference detection and suppression
- HP-SAR Evaluation & Analytical Dataset
- GDHuiYan-ATRNet
- Multi-System Maritime Low Observable Target Dataset
- DatasetinthePaper
- DatasetintheCompetition
- Report
- Course
- About
- Publish
- Editorial Board
- Chinese
Article Navigation >
Journal of Radars
>
2026
> Online First
| Citation: | SUN Jiamin, JIANG Meiqiu, HE Langchi, et al. Hierarchical association-based random matrix extended Kalman filter for vehicle tracking[J]. Journal of Radars, in press. doi: 10.12000/JR26104

|
Hierarchical Association-based Random Matrix Extended Kalman Filter for Vehicle Tracking
DOI: 10.12000/JR26104 CSTR: 32380.14.JR26104
More Information-
Abstract
With the rapid development of intelligent transportation and autonomous driving technologies, millimeter-wave radar has been widely used for road vehicle tracking due to its all-weather operational capability and high-precision sensing performance. Traditional tracking methods based on point targets or fixed parameters are unable to describe the extended characteristics and complex interaction behaviors of vehicles, which may lead to target splitting, missed detection, and track interruption. To deal with these problems, this paper proposes a Hierarchical Association-based Random Matrix Extended Kalman Filter (HARM-EKF) for vehicle tracking. First, the spatial extent of vehicle targets is modeled using a random matrix model, where the target shape is represented by an inverse Wishart distribution and jointly estimated with the kinematic state. Second, a hierarchical association mechanism is designed for tracks of different states and vehicles of different sizes. Third, Gaussian mixture model-based association and cluster-level association are introduced, and a sliding-window measurement accumulation strategy for small vehicles is employed to suppress the splitting of large vehicles and improve tracking continuity of small vehicles under sparse measurements. Fourth, a track re-association method combining motion consistency, directional constraints, and shape similarity is developed to recover the tracks and maintain the target identities under occlusion. Finally, a shape screening method based on size priors is proposed at the new-target initialization stage to improve initialization stability. Simulation results show that in dense traffic scenarios with multiple occlusions and clutter interference, the proposed method greatly improves multi-target tracking continuity and stability, effectively reduces target splitting and incorrect associations, and outperforms traditional methods in tracking accuracy and robustness. -

-
References
[1] HASCH J, TOPAK E, SCHNABEL R, et al. Millimeter-wave technology for automotive radar sensors in the 77 GHz frequency band[J]. IEEE Transactions on Microwave Theory and Techniques, 2012, 60(3): 845–860. doi: 10.1109/TMTT.2011.2178427.[2] WANG Yifei, CHENG Yayun, TANG Peiwen, et al. Pathway detection using fusion polarization features in passive millimeter-wave imaging[J]. IEEE Transactions on Circuits and Systems for Video Technology, 2026, 36(3): 2685–2696. doi: 10.1109/TCSVT.2025.3613515.[3] FENG Di, HAASE-SCHÜTZ C, ROSENBAUM L, et al. Deep multi-modal object detection and semantic segmentation for autonomous driving: Datasets, methods, and challenges[J]. IEEE Transactions on Intelligent Transportation Systems, 2021, 22(3): 1341–1360. doi: 10.1109/TITS.2020.2972974.[4] GRANSTRÖM K, BAUM M, and REUTER S. Extended object tracking: Introduction, overview, and applications[J]. Journal of Advances in Information Fusion, 2017, 12(2): 139–174.[5] SHAMSFAKHR F, MACII D, PALOPOLI L, et al. A multi-target detection and position tracking algorithm based on mmWave-FMCW radar data[J]. Measurement, 2024, 234: 114797. doi: 10.1016/j.measurement.2024.114797.[6] YURTSEVER E, LAMBERT J, CARBALLO A, et al. A survey of autonomous driving: Common practices and emerging technologies[J]. IEEE Access, 2020, 8: 58443–58469. doi: 10.1109/ACCESS.2020.2983149.[7] KALMAN R E. A new approach to linear filtering and prediction problems[J]. Journal of Basic Engineering, 1960, 82(1): 35–45. doi: 10.1115/1.3662552.[8] JULIER S J and UHLMANN J K. New extension of the Kalman filter to nonlinear systems[C]. SPIE 3068, Signal Processing, Sensor Fusion, and Target Recognition VI, Orlando, USA, 1997: 182–193. doi: 10.1117/12.280797.[9] JULIER S J and UHLMANN J K. Unscented filtering and nonlinear estimation[J]. Proceedings of the IEEE, 2004, 92(3): 401–422. doi: 10.1109/JPROC.2003.823141.[10] MAHLER R P S. Statistical Multisource-Multitarget Information Fusion[M]. Boston: Artech House, 2007.[11] BLACKMAN S and POPOLI R. Design and Analysis of Modern Tracking Systems[M]. Boston: Artech House, 1999.[12] PATOLE S M, TORLAK M, WANG Dan, et al. Automotive radars: A review of signal processing techniques[J]. IEEE Signal Processing Magazine, 2017, 34(2): 22–35. doi: 10.1109/MSP.2016.2628914.[13] BAR-SHALOM Y and FORTMANN T E. Tracking and Data Association[M]. Boston: Academic Press, 1988.[14] BLACKMAN S S. Multiple hypothesis tracking for multiple target tracking[J]. IEEE Aerospace and Electronic Systems Magazine, 2004, 19(1): 5–18. doi: 10.1109/MAES.2004.1263228.[15] BAR-SHALOM Y, LI X R, and KIRUBARAJAN T. Estimation with Applications to Tracking and Navigation: Theory Algorithms and Software[M]. New York: John Wiley & Sons, 2001.[16] BLOM H A P and BAR-SHALOM Y. The interacting multiple model algorithm for systems with Markovian switching coefficients[J]. IEEE Transactions on Automatic Control, 1988, 33(8): 780–783. doi: 10.1109/9.1299.[17] 周浩文, 王奇. 基于变分边缘化粒子滤波的车载雷达扩展目标跟踪[J]. 雷达学报(中英文), 2025, 14(5): 1306–1322. doi: 10.12000/JR25005.ZHOU Haowen and WANG Qi. Extended object tracking based on variational marginalized particle filter for automotive radar[J]. Journal of Radars, 2025, 14(5): 1306–1322. doi: 10.12000/JR25005.[18] 陈辉, 边斌超, 连峰, 等. 基于Transformer复杂运动辨识的机动星凸形扩展目标跟踪方法[J]. 雷达学报(中英文), 2024, 13(3): 629–645. doi: 10.12000/JR24031.CHEN Hui, BIAN Binchao, LIAN Feng, et al. A novel method for tracking complex maneuvering star convex extended targets using Transformer network[J]. Journal of Radars, 2024, 13(3): 629–645. doi: 10.12000/JR24031.[19] 蒋美秋, 罗皓蓝, 郭世盛, 等. 基于多径扩展投影的毫米波雷达室内目标跟踪方法[J]. 雷达学报(中英文), 待出版. doi: 10.12000/JR25245.JIANG Meiqiu, LUO Haolan, GUO Shisheng, et al. Indoor target tracking method for millimeter-wave radar based on multipath extension mapping[J]. Journal of Radars, in press. doi: 10.12000/JR25245.[20] LAN Jian. Extended object tracking using random matrix with extension-dependent measurement numbers[J]. IEEE Transactions on Aerospace and Electronic Systems, 2023, 59(4): 4464–4477. doi: 10.1109/TAES.2023.3241888.[21] HAAG S, DURAISAMY B, GOVAERS F, et al. Extended object tracking assisted adaptive clustering for radar in autonomous driving applications[C]. 2019 Sensor Data Fusion: Trends, Solutions, Applications, Bonn, Germany, 2019: 1–7. doi: 10.1109/SDF.2019.8916658.[22] LAN Jian and LI X R. Tracking of extended object or target group using random matrix—Part I: New model and approach[C]. 2012 15th International Conference on Information Fusion, Singapore, Singapore, 2012: 2177–2184.[23] KOCH J W. Bayesian approach to extended object and cluster tracking using random matrices[J]. IEEE Transactions on Aerospace and Electronic Systems, 2008, 44(3): 1042–1059. doi: 10.1109/TAES.2008.4655362.[24] FELDMANN M, FRÄNKEN D, and KOCH W. Tracking of extended objects and group targets using random matrices[J]. IEEE Transactions on Signal Processing, 2011, 59(4): 1409–1420. doi: 10.1109/TSP.2010.2101064.[25] GRANSTRÖM K and ORGUNER U. A PHD filter for tracking multiple extended targets using random matrices[J]. IEEE Transactions on Signal Processing, 2012, 60(11): 5657–5671. doi: 10.1109/TSP.2012.2212888.[26] YANG Shishan and BAUM M. Tracking the orientation and axes lengths of an elliptical extended object[J]. IEEE Transactions on Signal Processing, 2019, 67(18): 4720–4729. doi: 10.1109/TSP.2019.2929462.[27] FOWDUR J S, BAUM M, and HEYMANN F. Tracking targets with known spatial extent using experimental marine radar data[C]. 2019 22nd International Conference on Information Fusion, Ottawa, Canada, 2019: 1–8. doi: 10.23919/FUSION43075.2019.9011244.[28] CAO Xiaomeng, LAN Jian, LI X R, et al. Automotive radar-based vehicle tracking using data-region association[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(7): 8997–9010. doi: 10.1109/TITS.2021.3089676.[29] BAUM M and HANEBECK U D. Shape tracking of extended objects and group targets with star-convex RHMs[C]. The 14th International Conference on Information Fusion, Chicago, USA, 2011: 1–8.[30] STEINBRING J, BAUM M, ZEA A, et al. A closed-form likelihood for Particle Filters to track extended objects with star-convex RHMs[C]. 2015 IEEE International Conference on Multisensor Fusion and Integration for Intelligent Systems, San Diego, USA, 2015: 25–30. doi: 10.1109/MFI.2015.7295740.[31] GUPTA A K and NAGAR D K. Matrix Variate Distributions[M]. New York: Chapman and Hall/CRC, 2018: 384. doi: 10.1201/9780203749289.[32] ESTER M, KRIEGEL H P, SANDER J, et al. A density-based algorithm for discovering clusters in large spatial databases with noise[C]. The 2nd International Conference on Knowledge Discovery and Data Mining, Portland, Oregon, 1996: 226–231.[33] JIANG Meiqiu, LUO Haolan, GUO Shisheng, et al. Indoor human tracking with 3-D expansion estimation based on mmWave radar[J]. IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(6): 16647–16665. doi: 10.1109/taes.2025.3595827.[34] ŞAHIN K K, BALCI A E and ÖZKAN E. Random matrix extended target tracking for trajectory‐aligned and drifting targets[J]. IET Radar, Sonar & Navigation, 2024, 18(11): 2247–2263. doi: 10.1049/rsn2.12628. -
Proportional views
- Publishing Ethics
- Journal Insights
- Abstracting & Indexing
- Peer Review Policies
- Guide for Authors
- Conference
- ISSN 2095-283X (Print)ISSN 2097-339X (Online)
- CN 10-1030/TN
- CODEN LXEUAO
About Journal
- Sponsor: China Radio Detection and Ranging Industry Association (CRIA)
- Phone: 010-58887062
- Email:radars@aircas.ac.cn
- Publisher: Leida Xuebao Bianjibu (Editorial office of the Journal of Radars)
Contacts Us
京ICP备20021838号-14
Supported by: Beijing Renhe Information Technology Co. Ltd

Export File
Citation
Format
Content
 DownLoad:

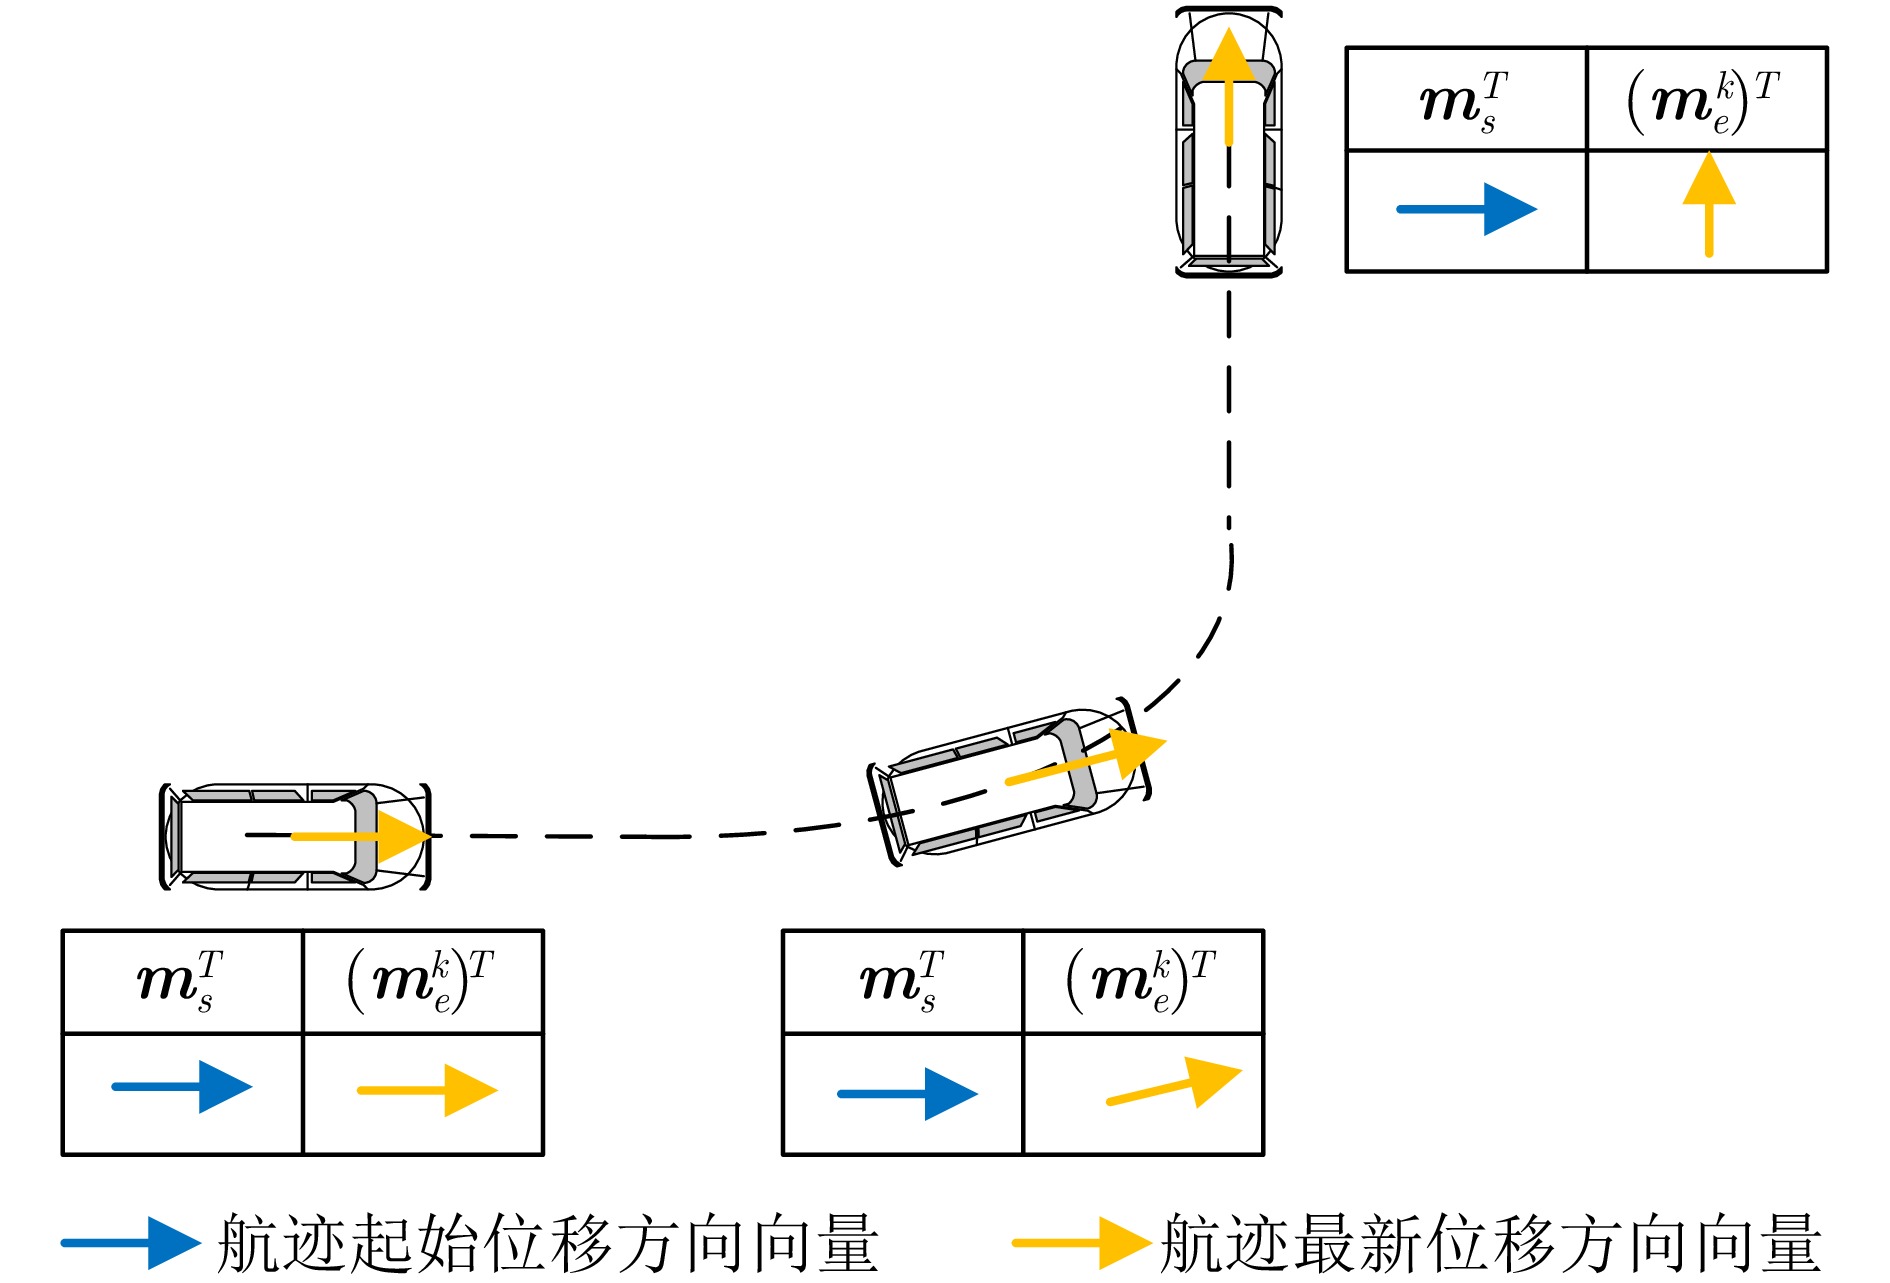
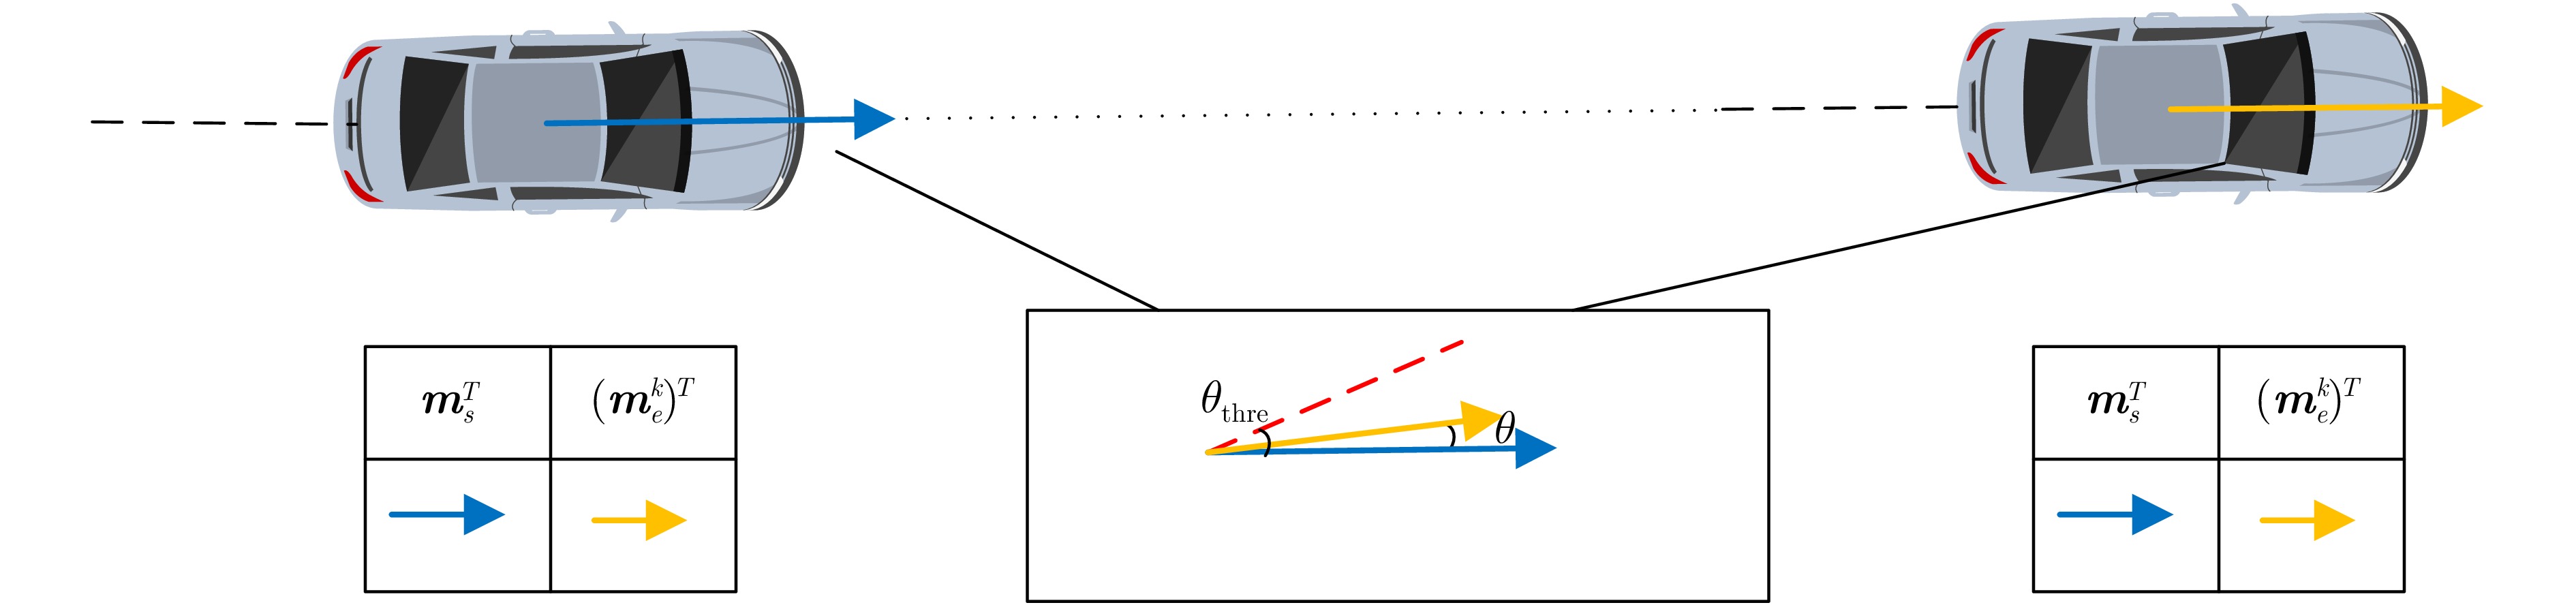
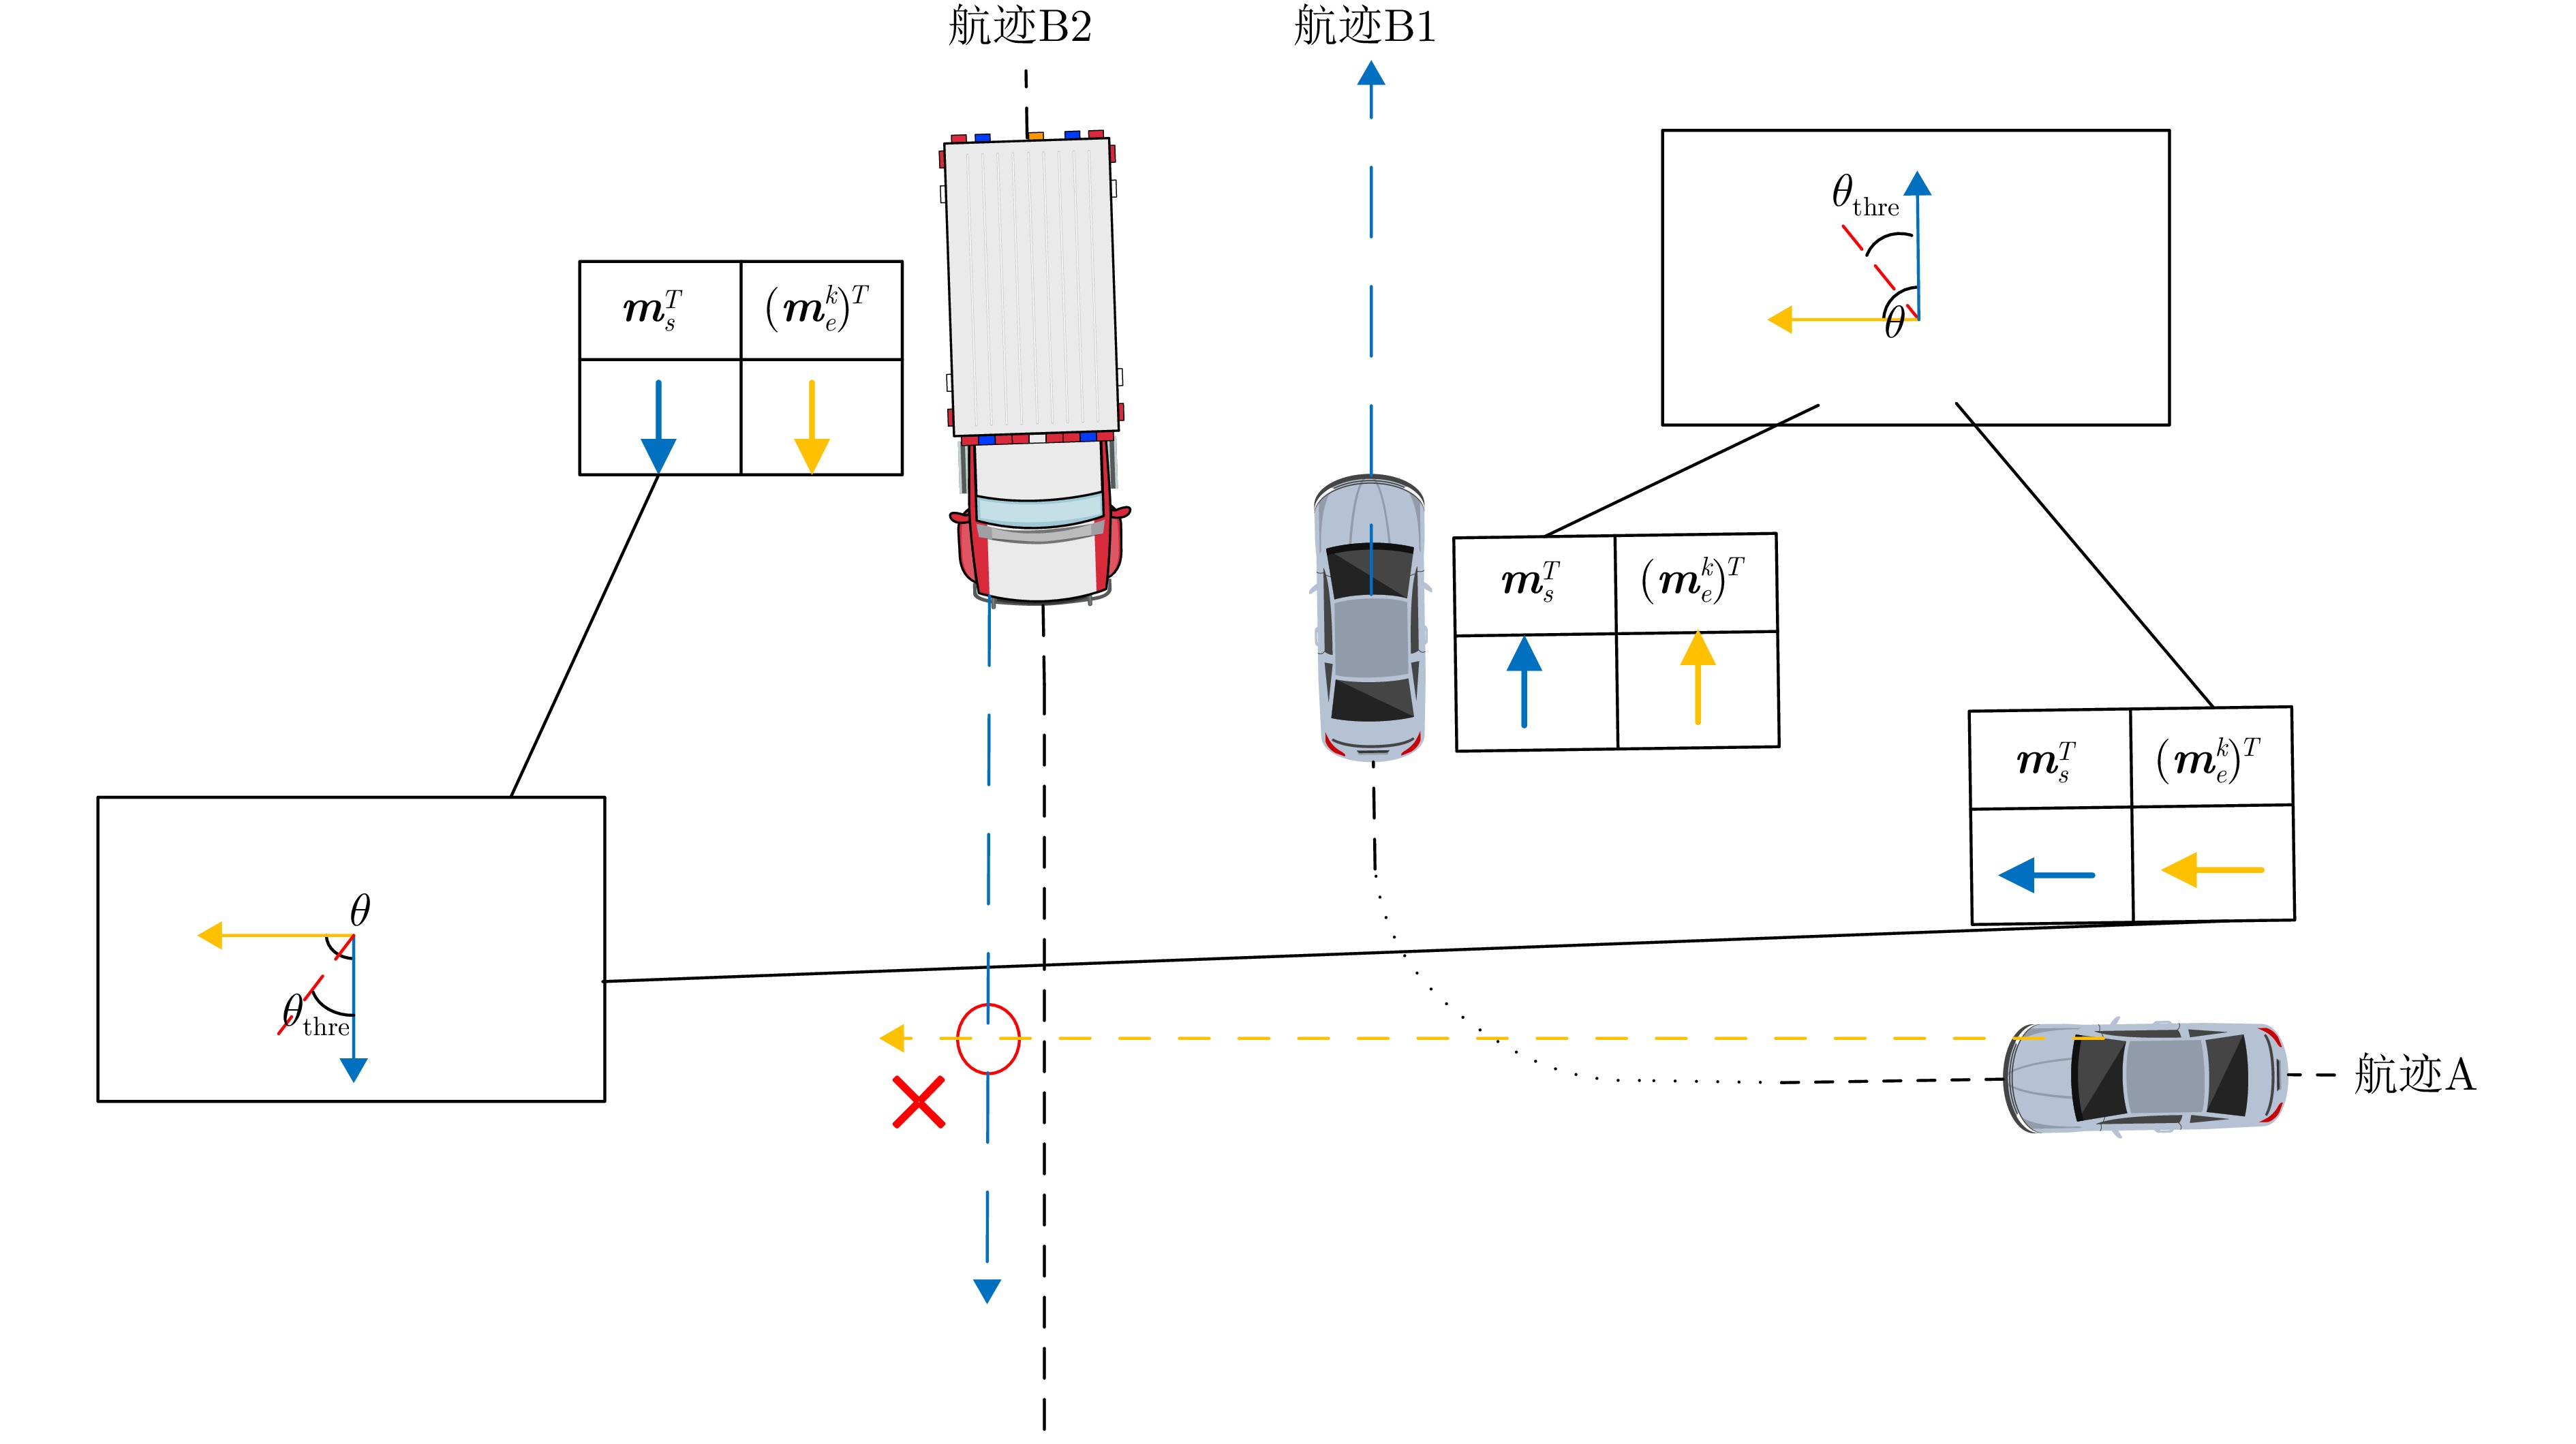

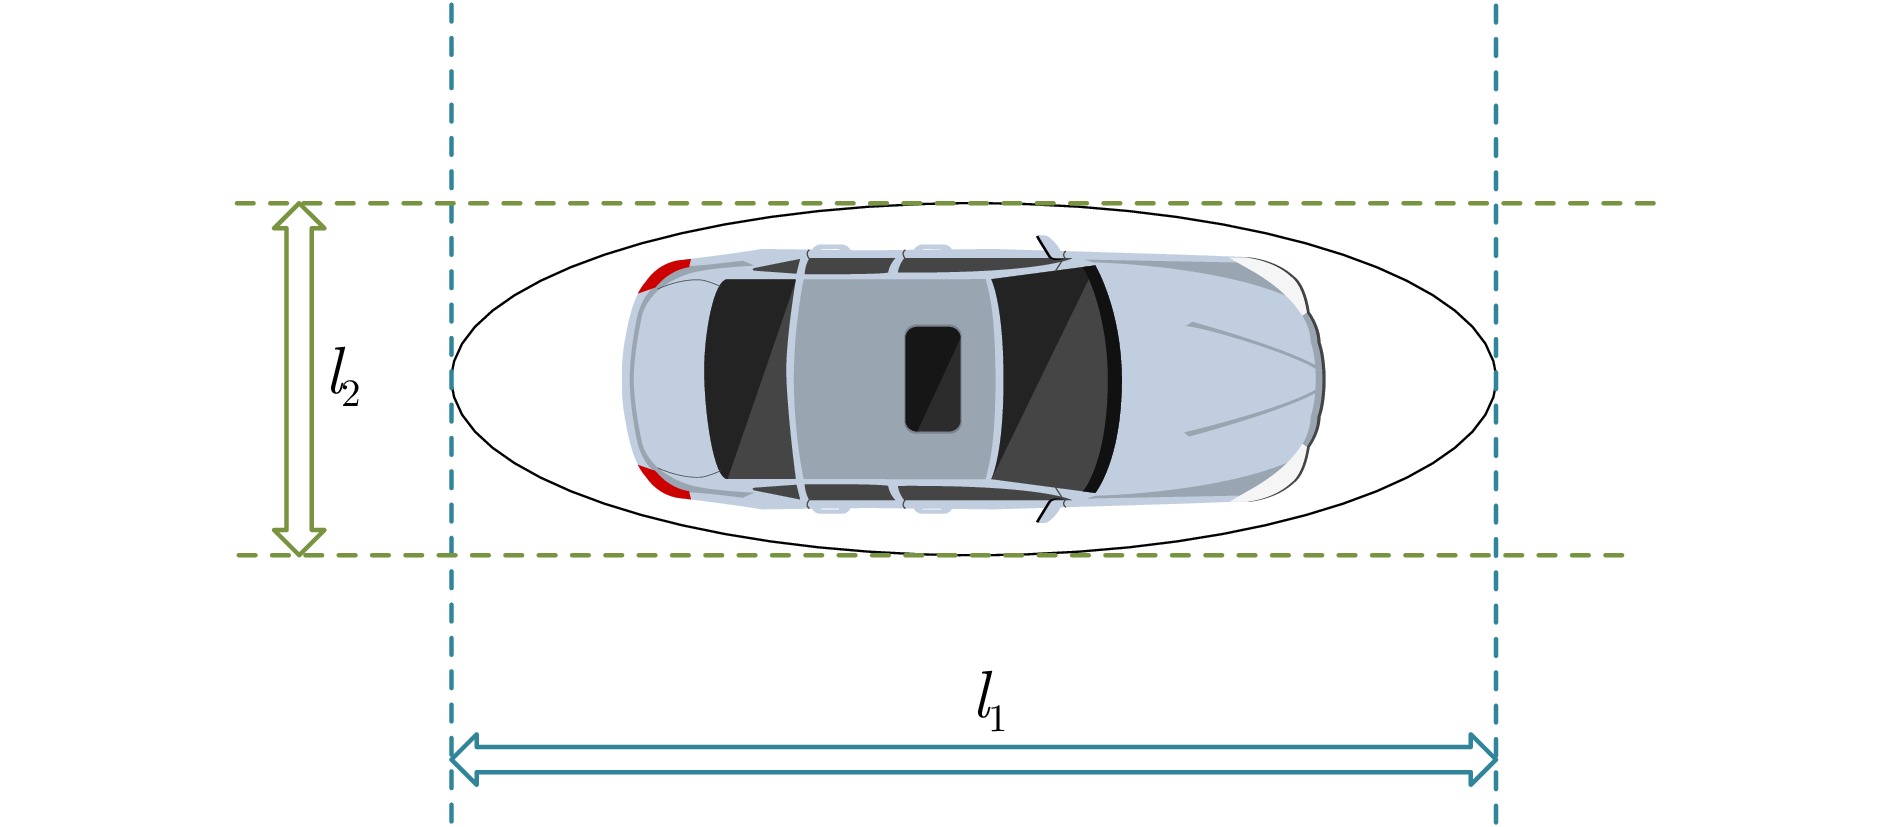
- Figure 1. Schematic diagram of vehicle shape modeling
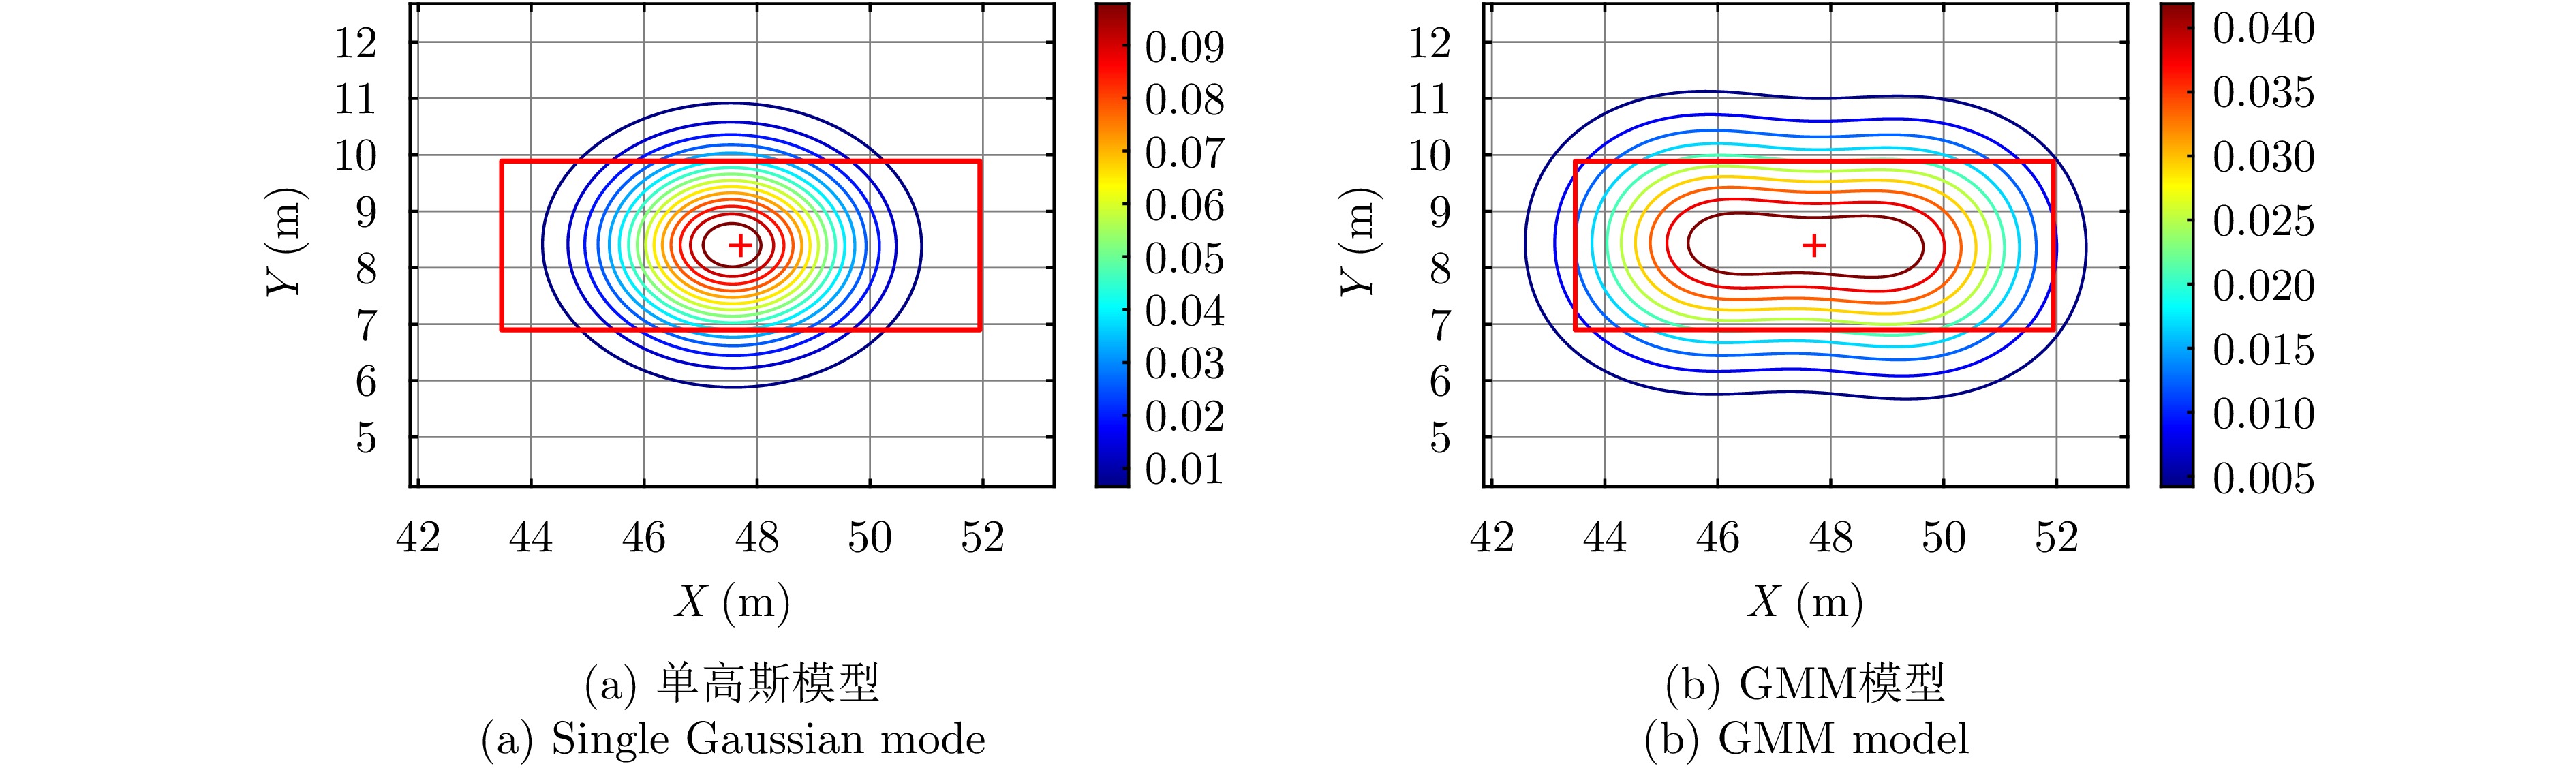
- Figure 2. Schematic diagram of vehicle measurement probability distributions under different association models
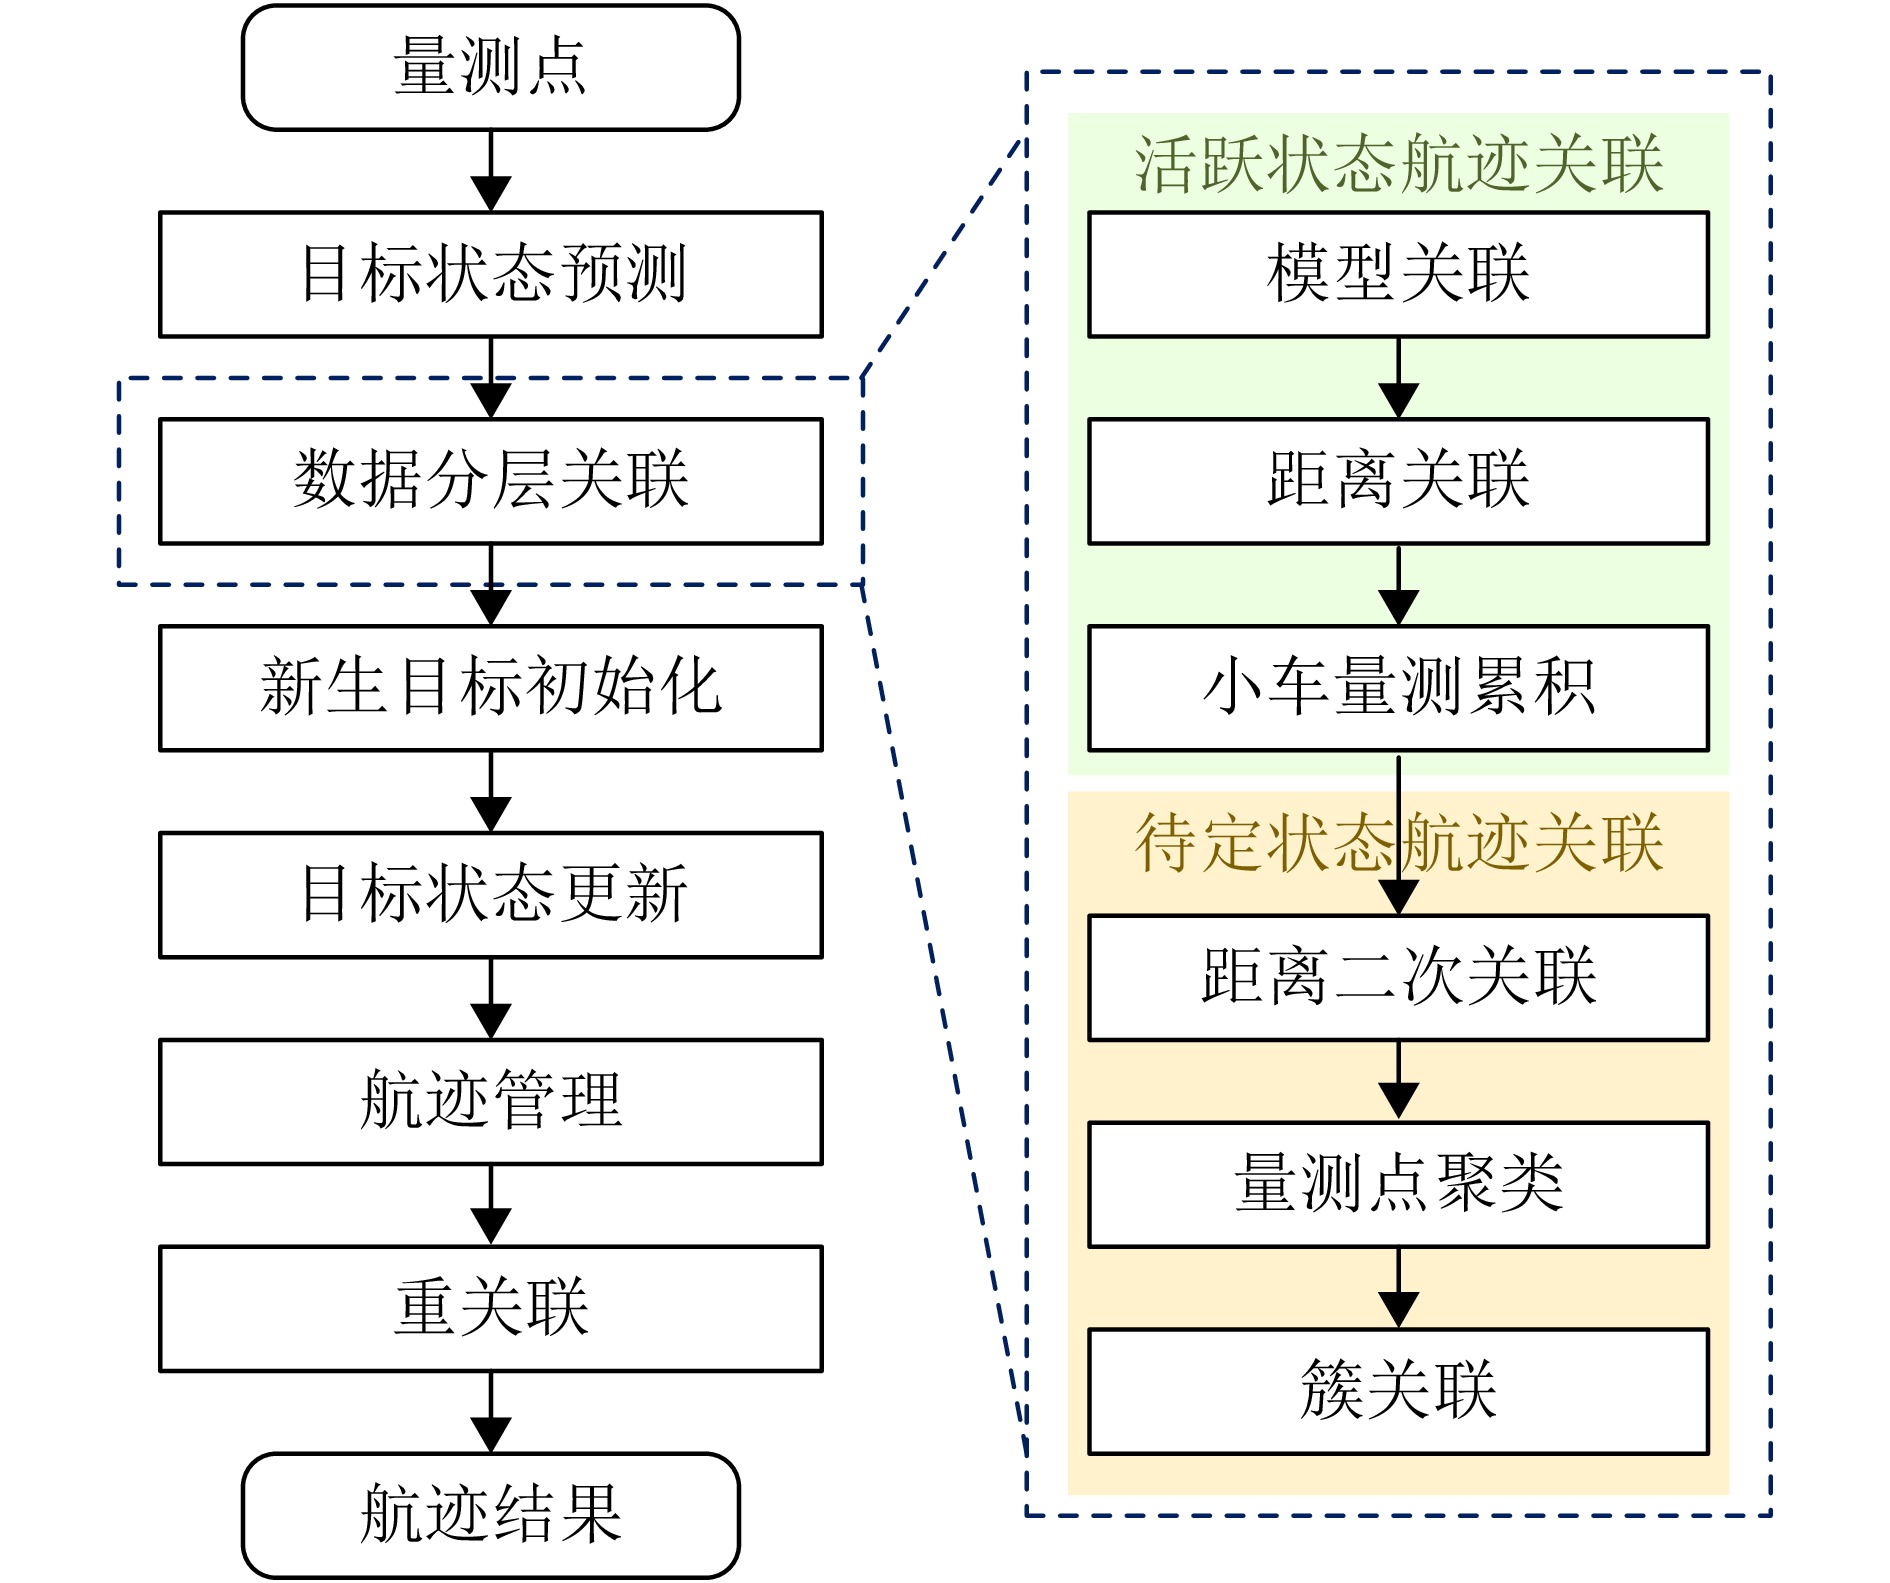
- Figure 3. Overall flowchart of the HARM-EKF
- Figure 4. Schematic diagram of sliding-window accumulation for small vehicles
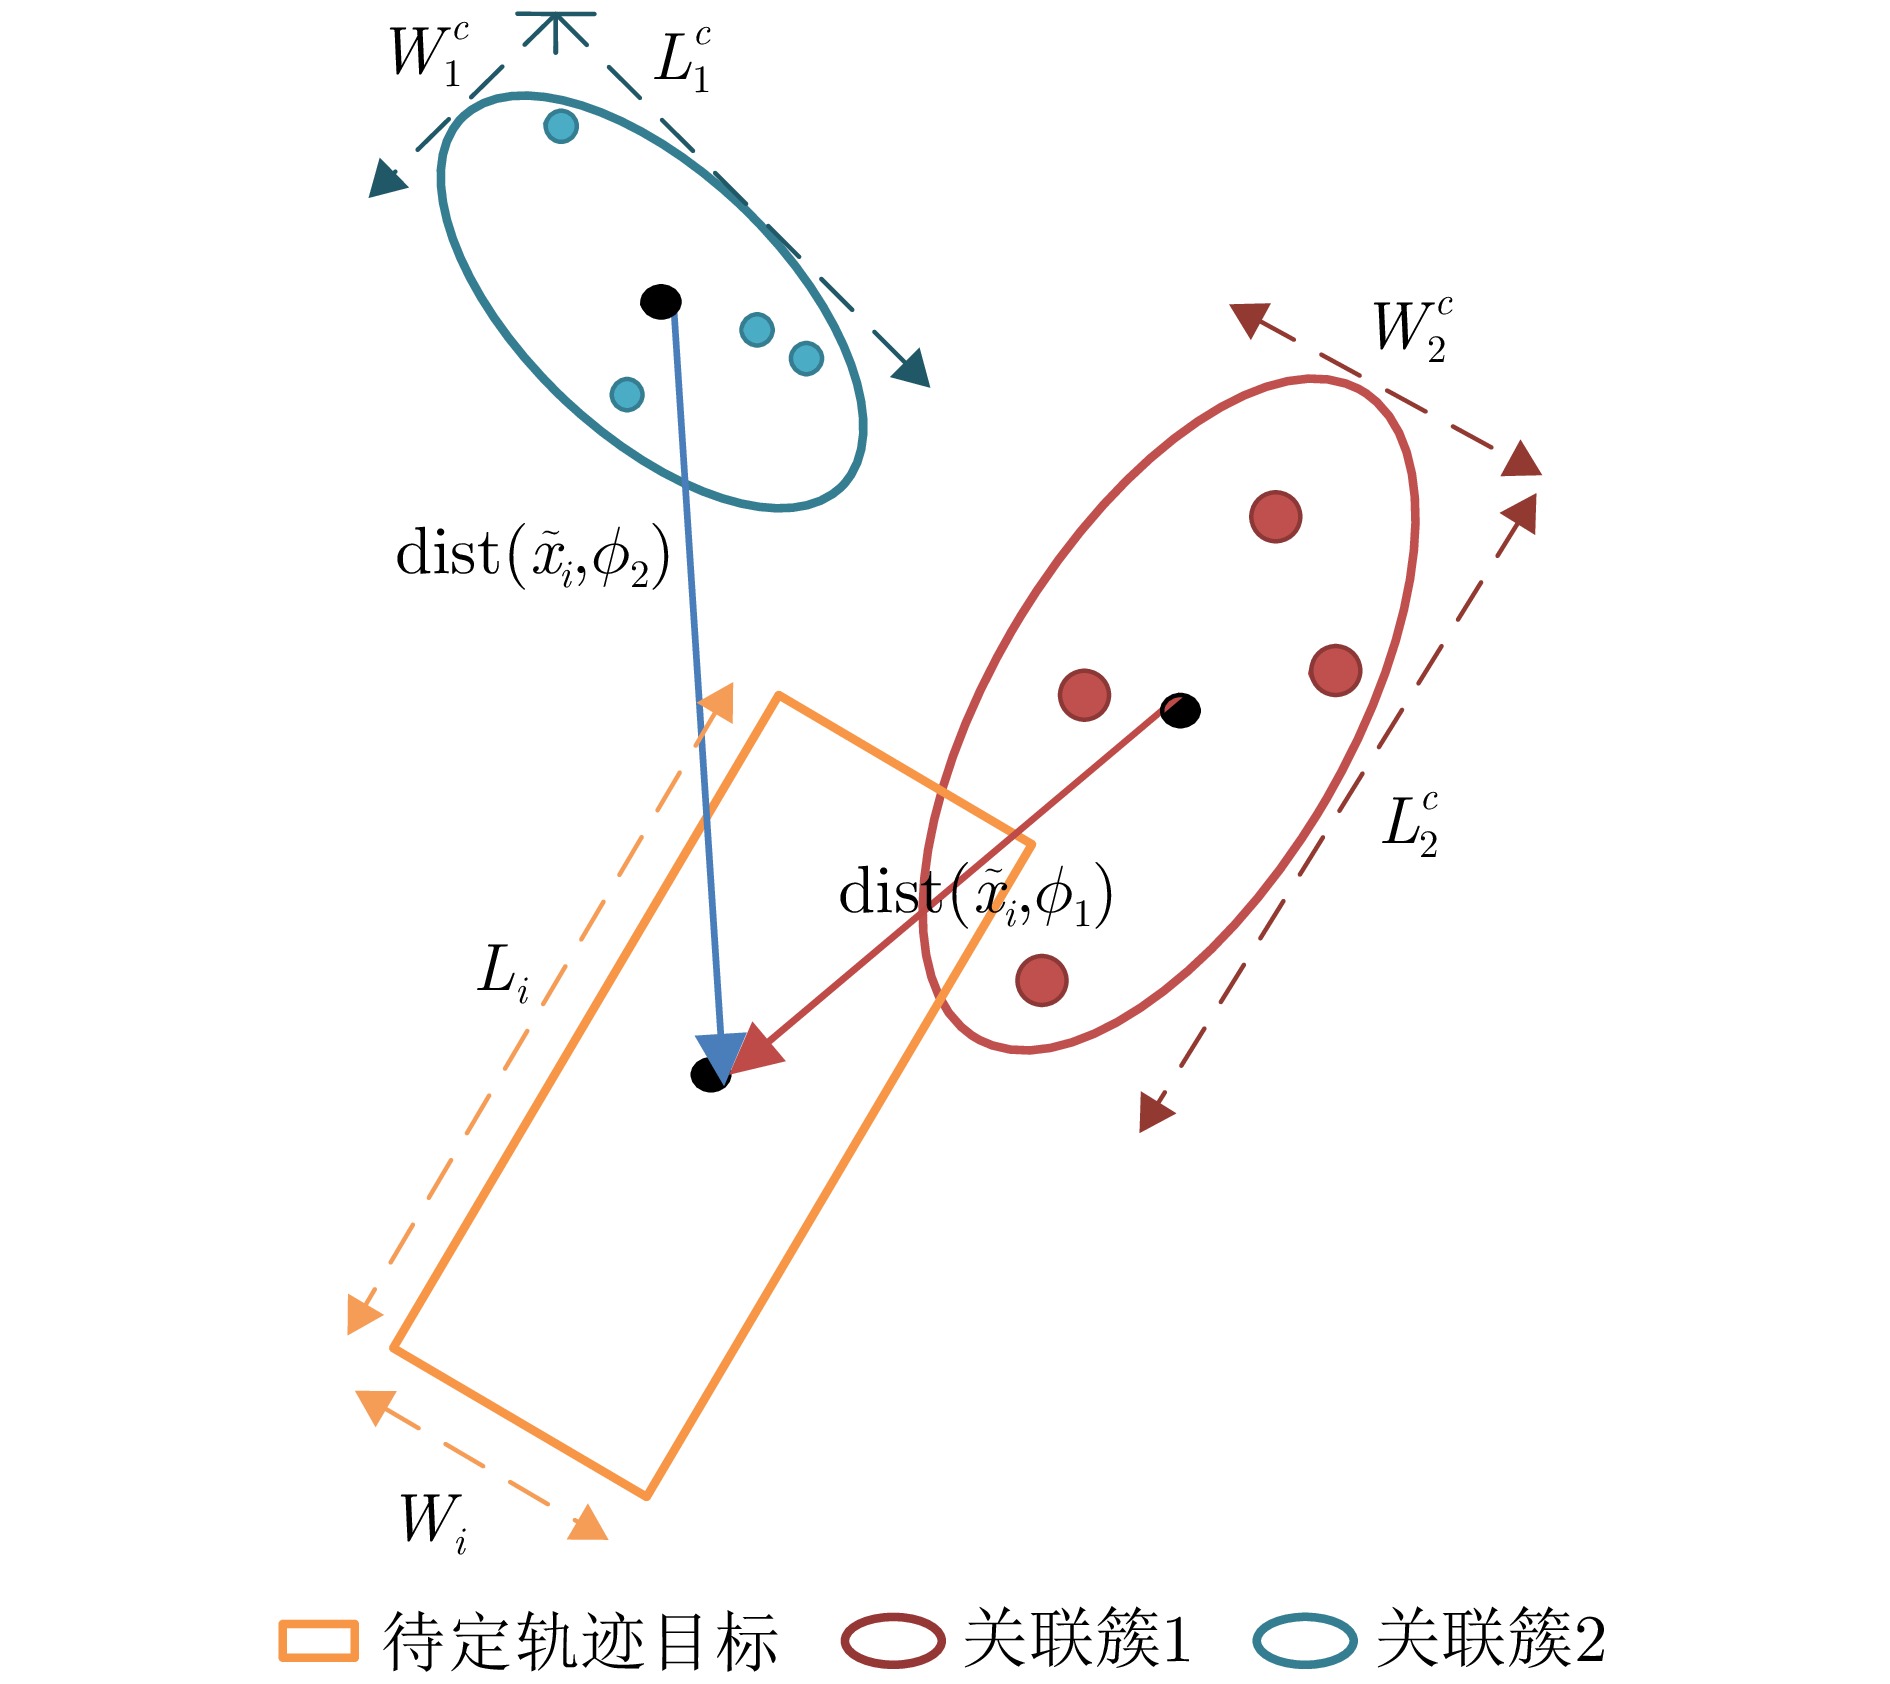
- Figure 5. Schematic diagram of tentative track association
- Figure 6. Schematic diagram of track state modeling
- Figure 7. Schematic diagram of re-association for targets traveling straight ahead
- Figure 8. Schematic diagram of re-association for turning targets
- Figure 9. Schematic diagram of simulated traffic flow operation
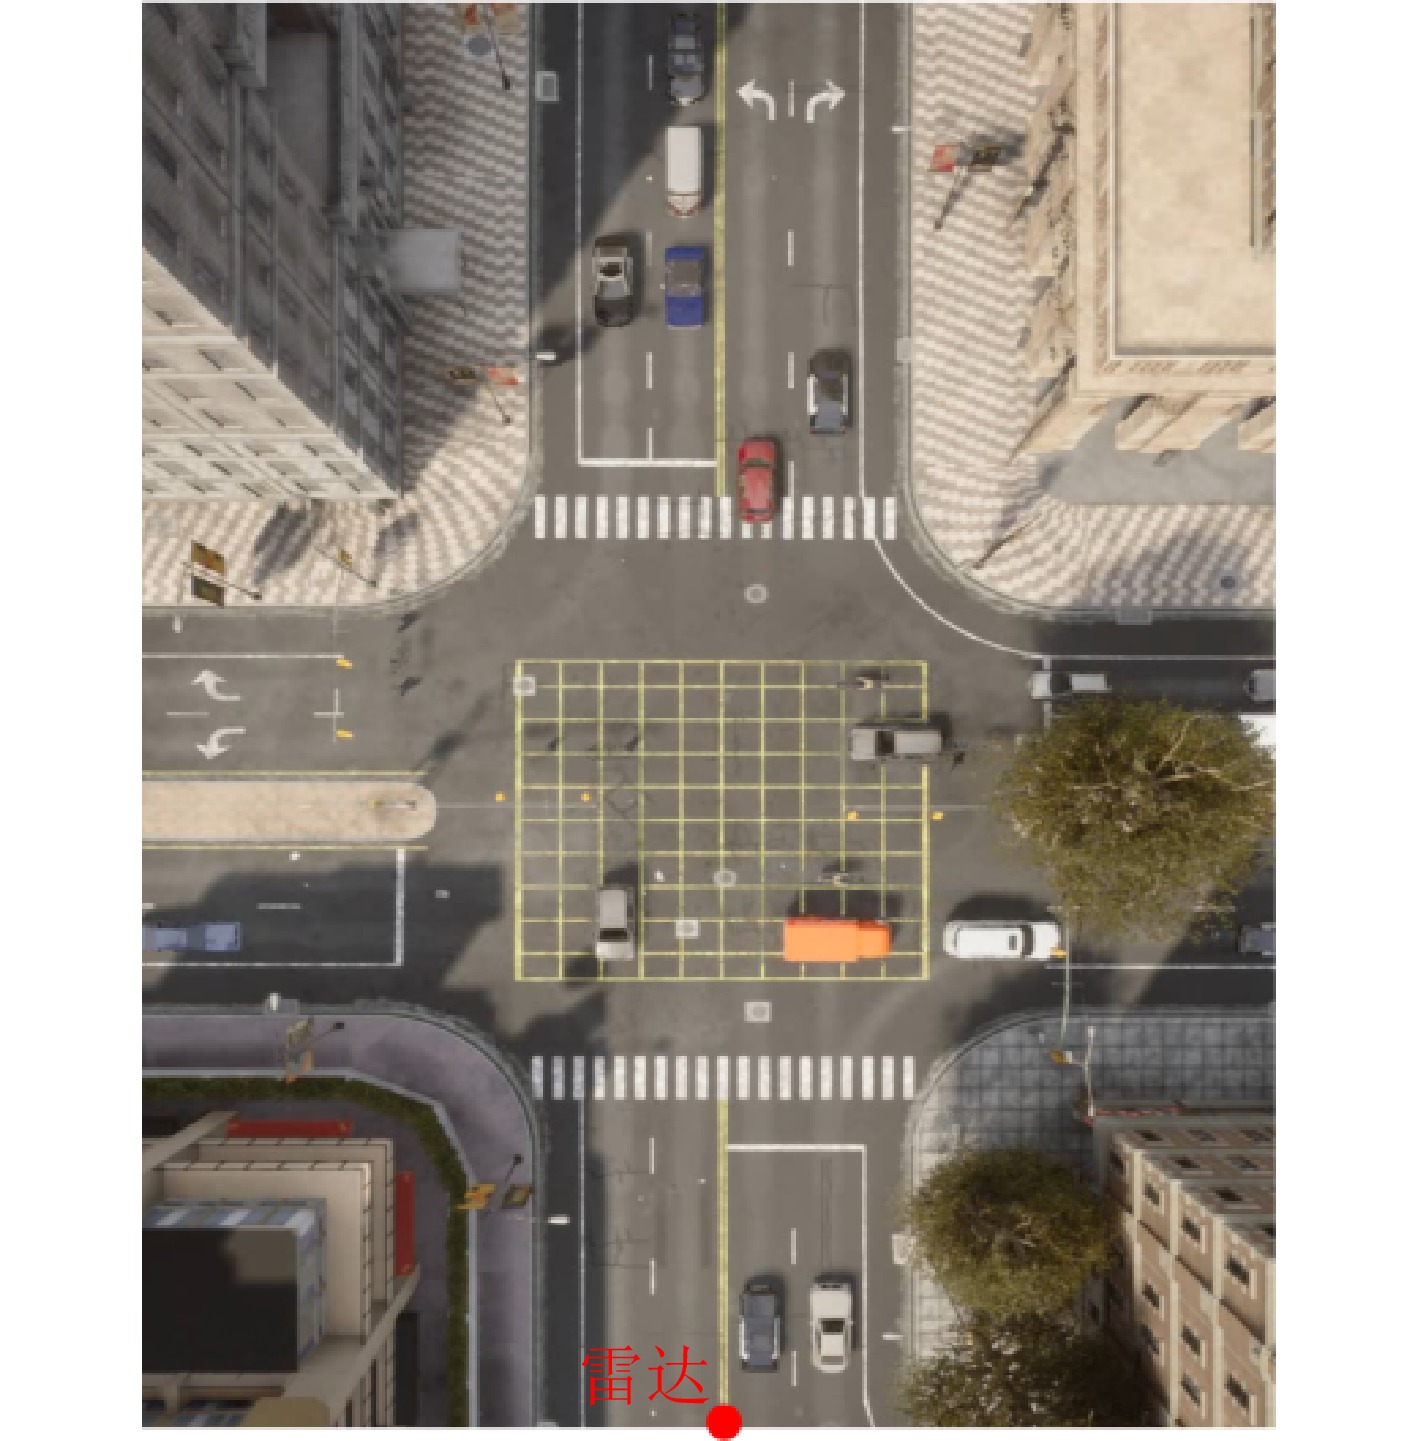
- Figure 10. Schematic diagram of the simulation scenario
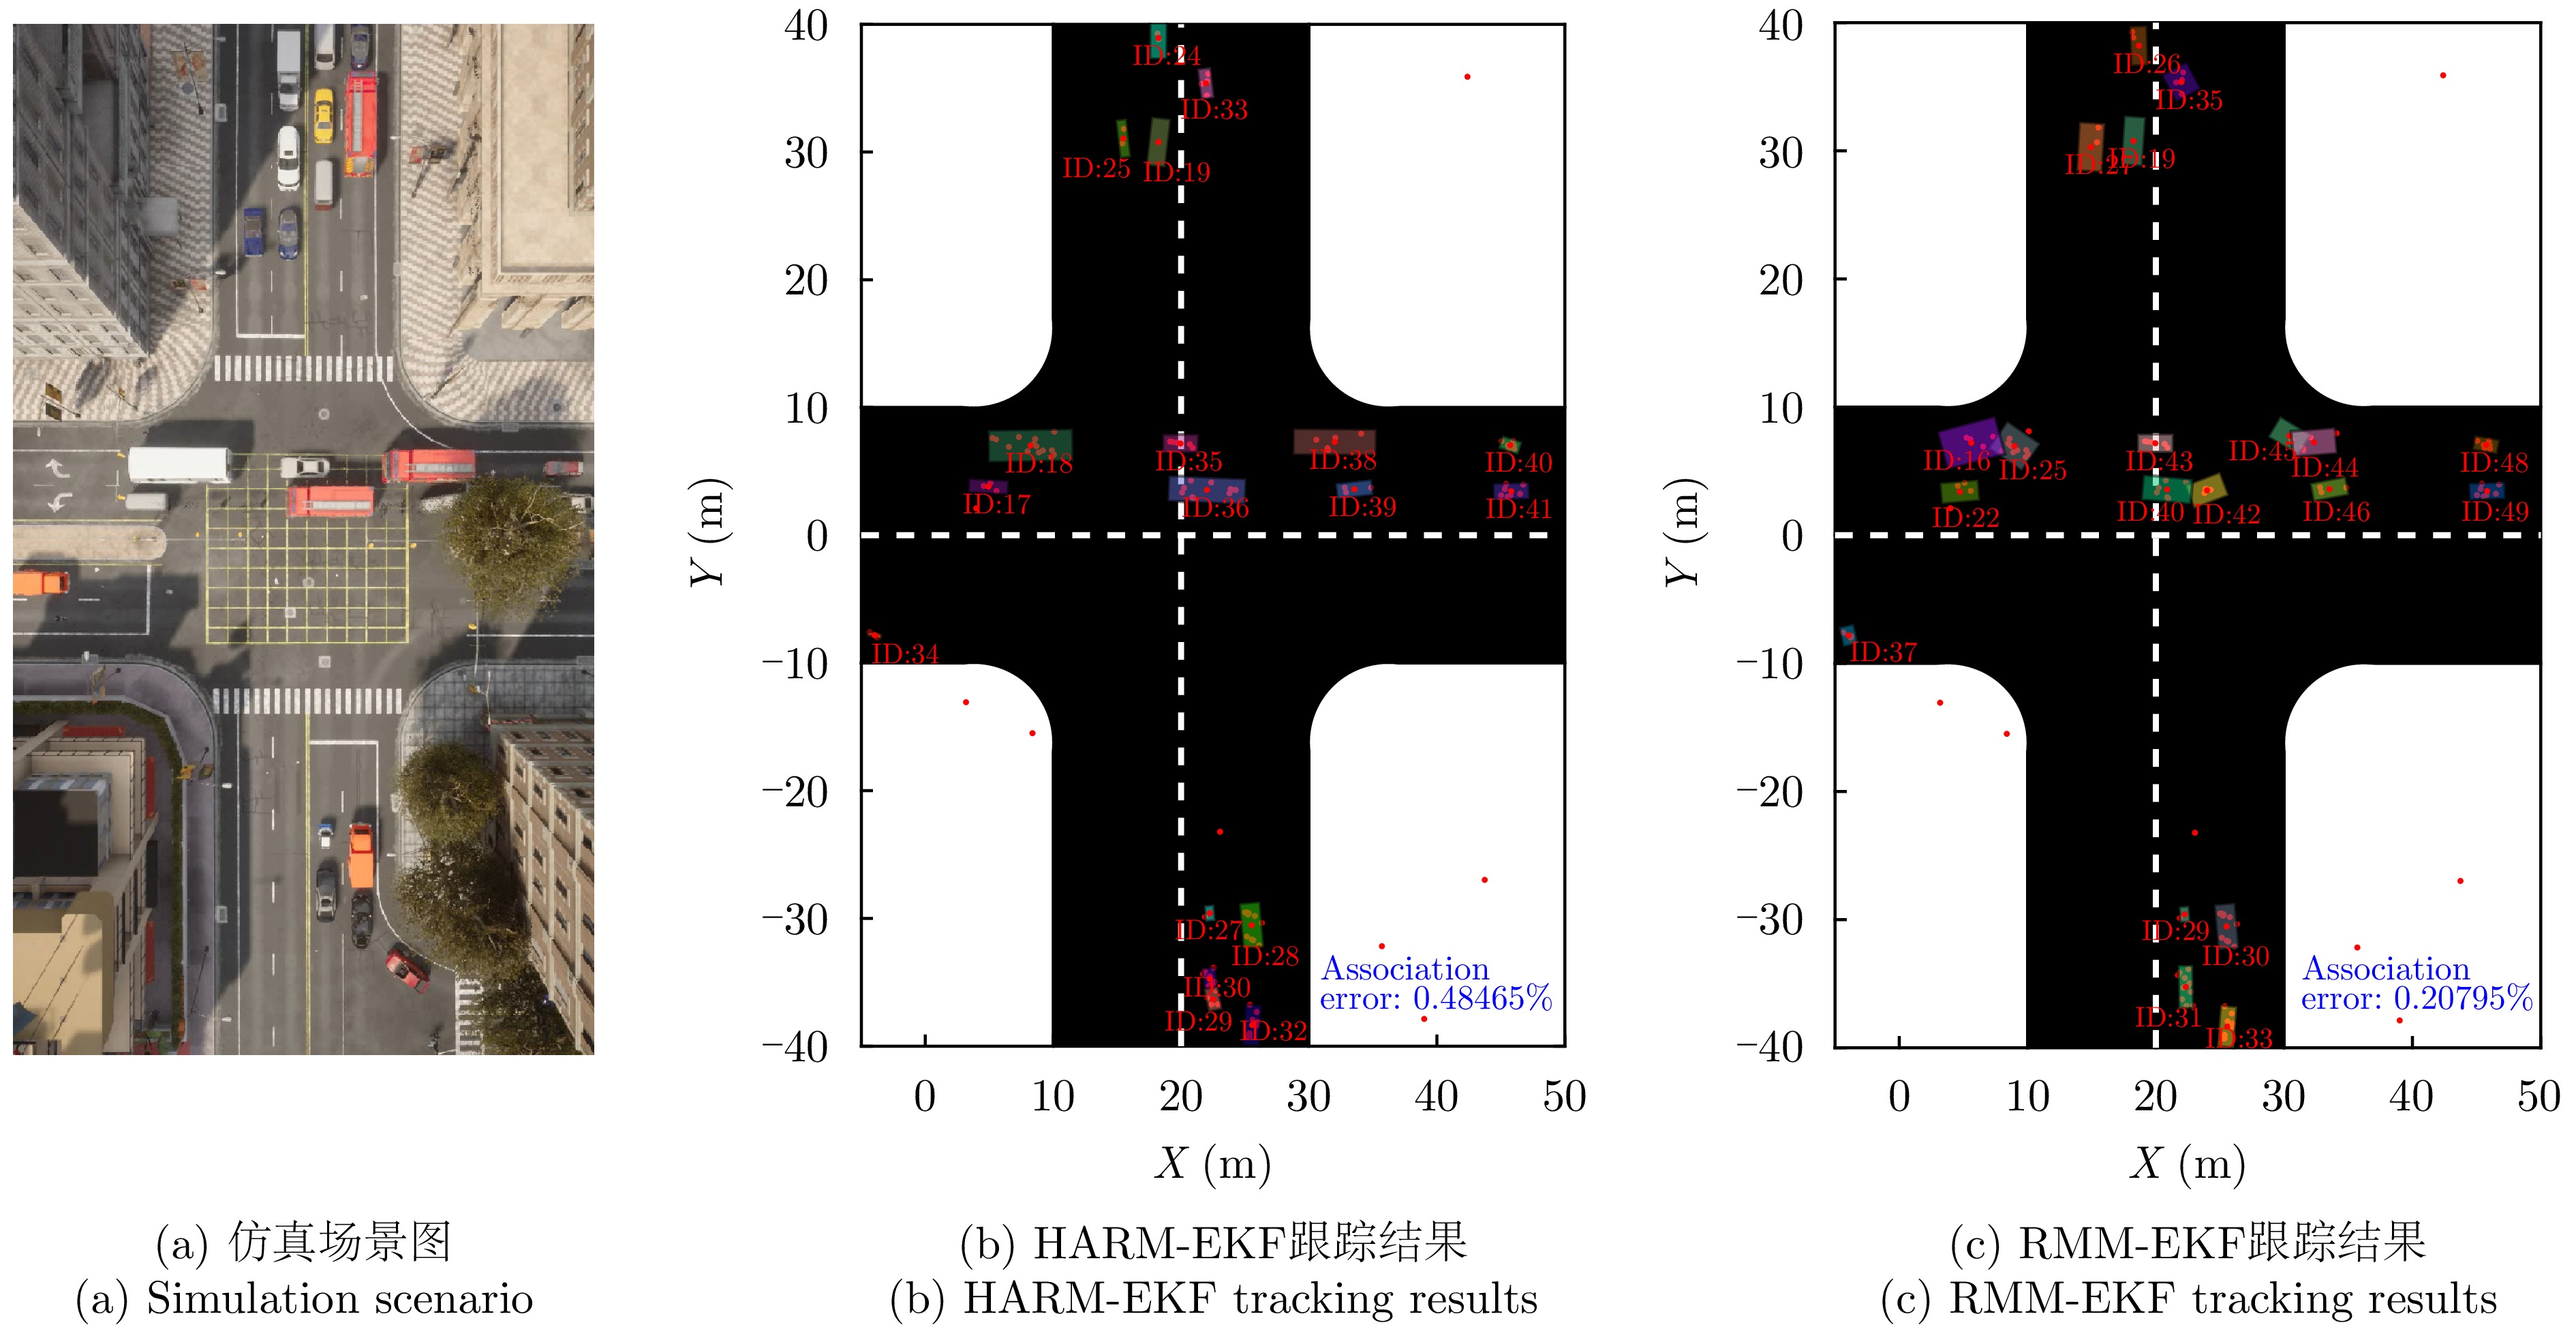
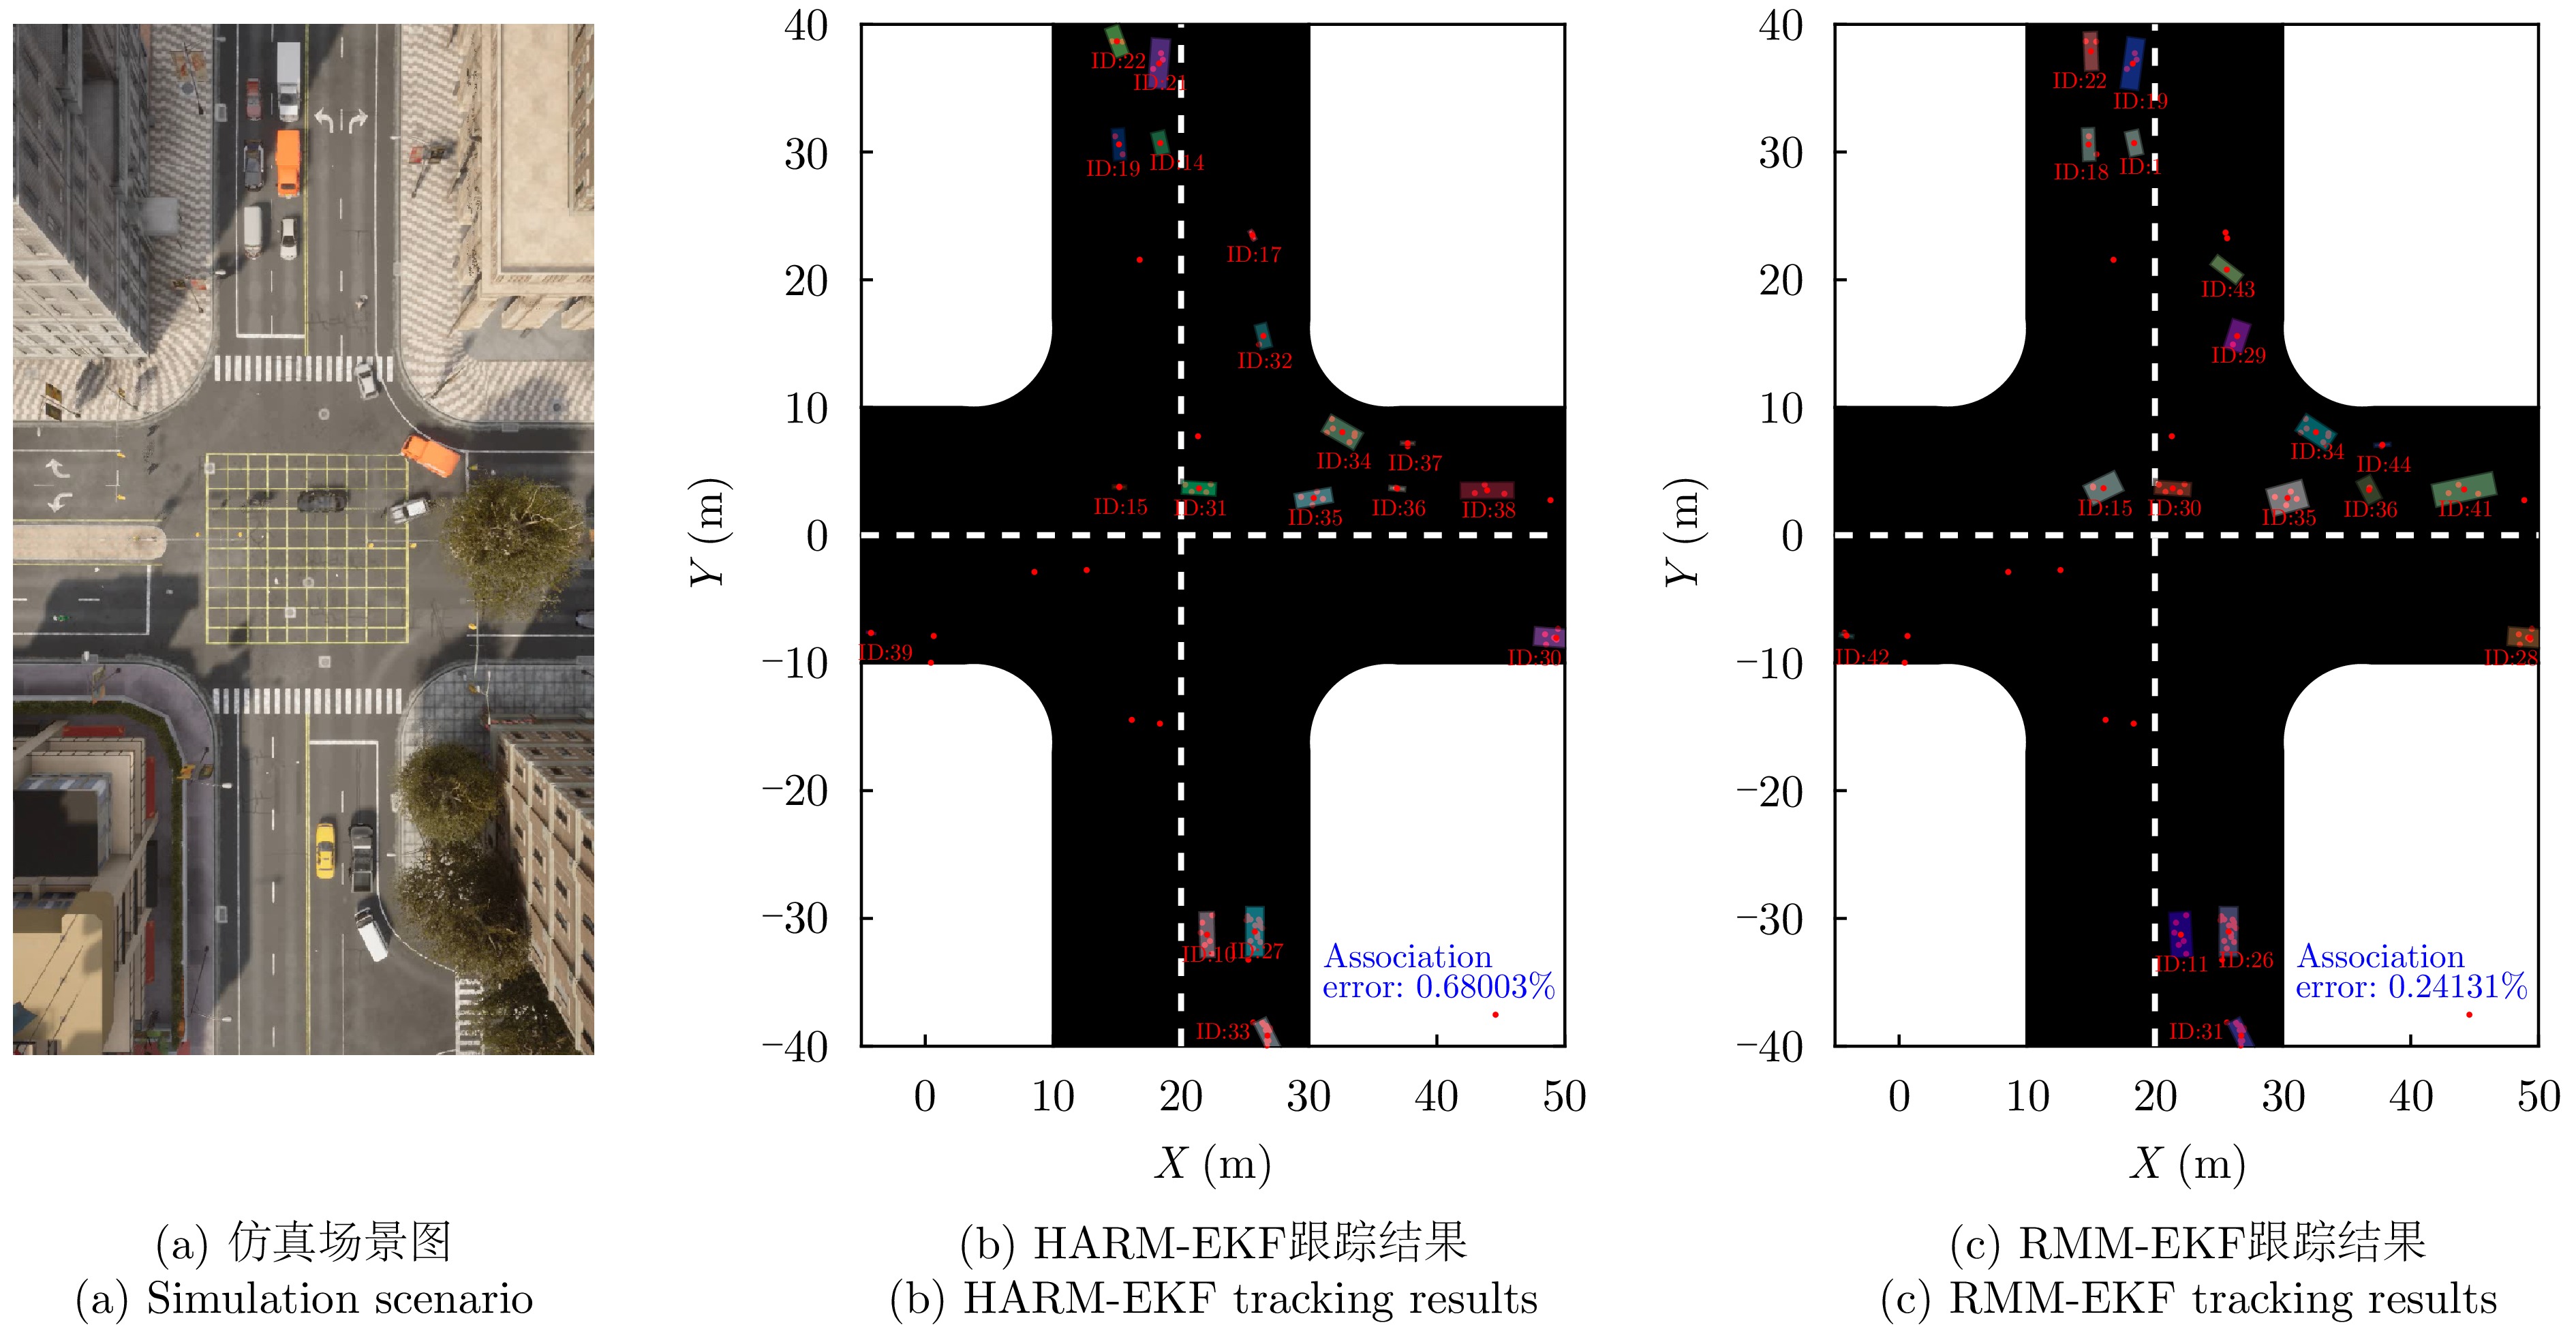
- Figure 11. Simulation scenario and tracking results in the large-vehicle-dominant scenario
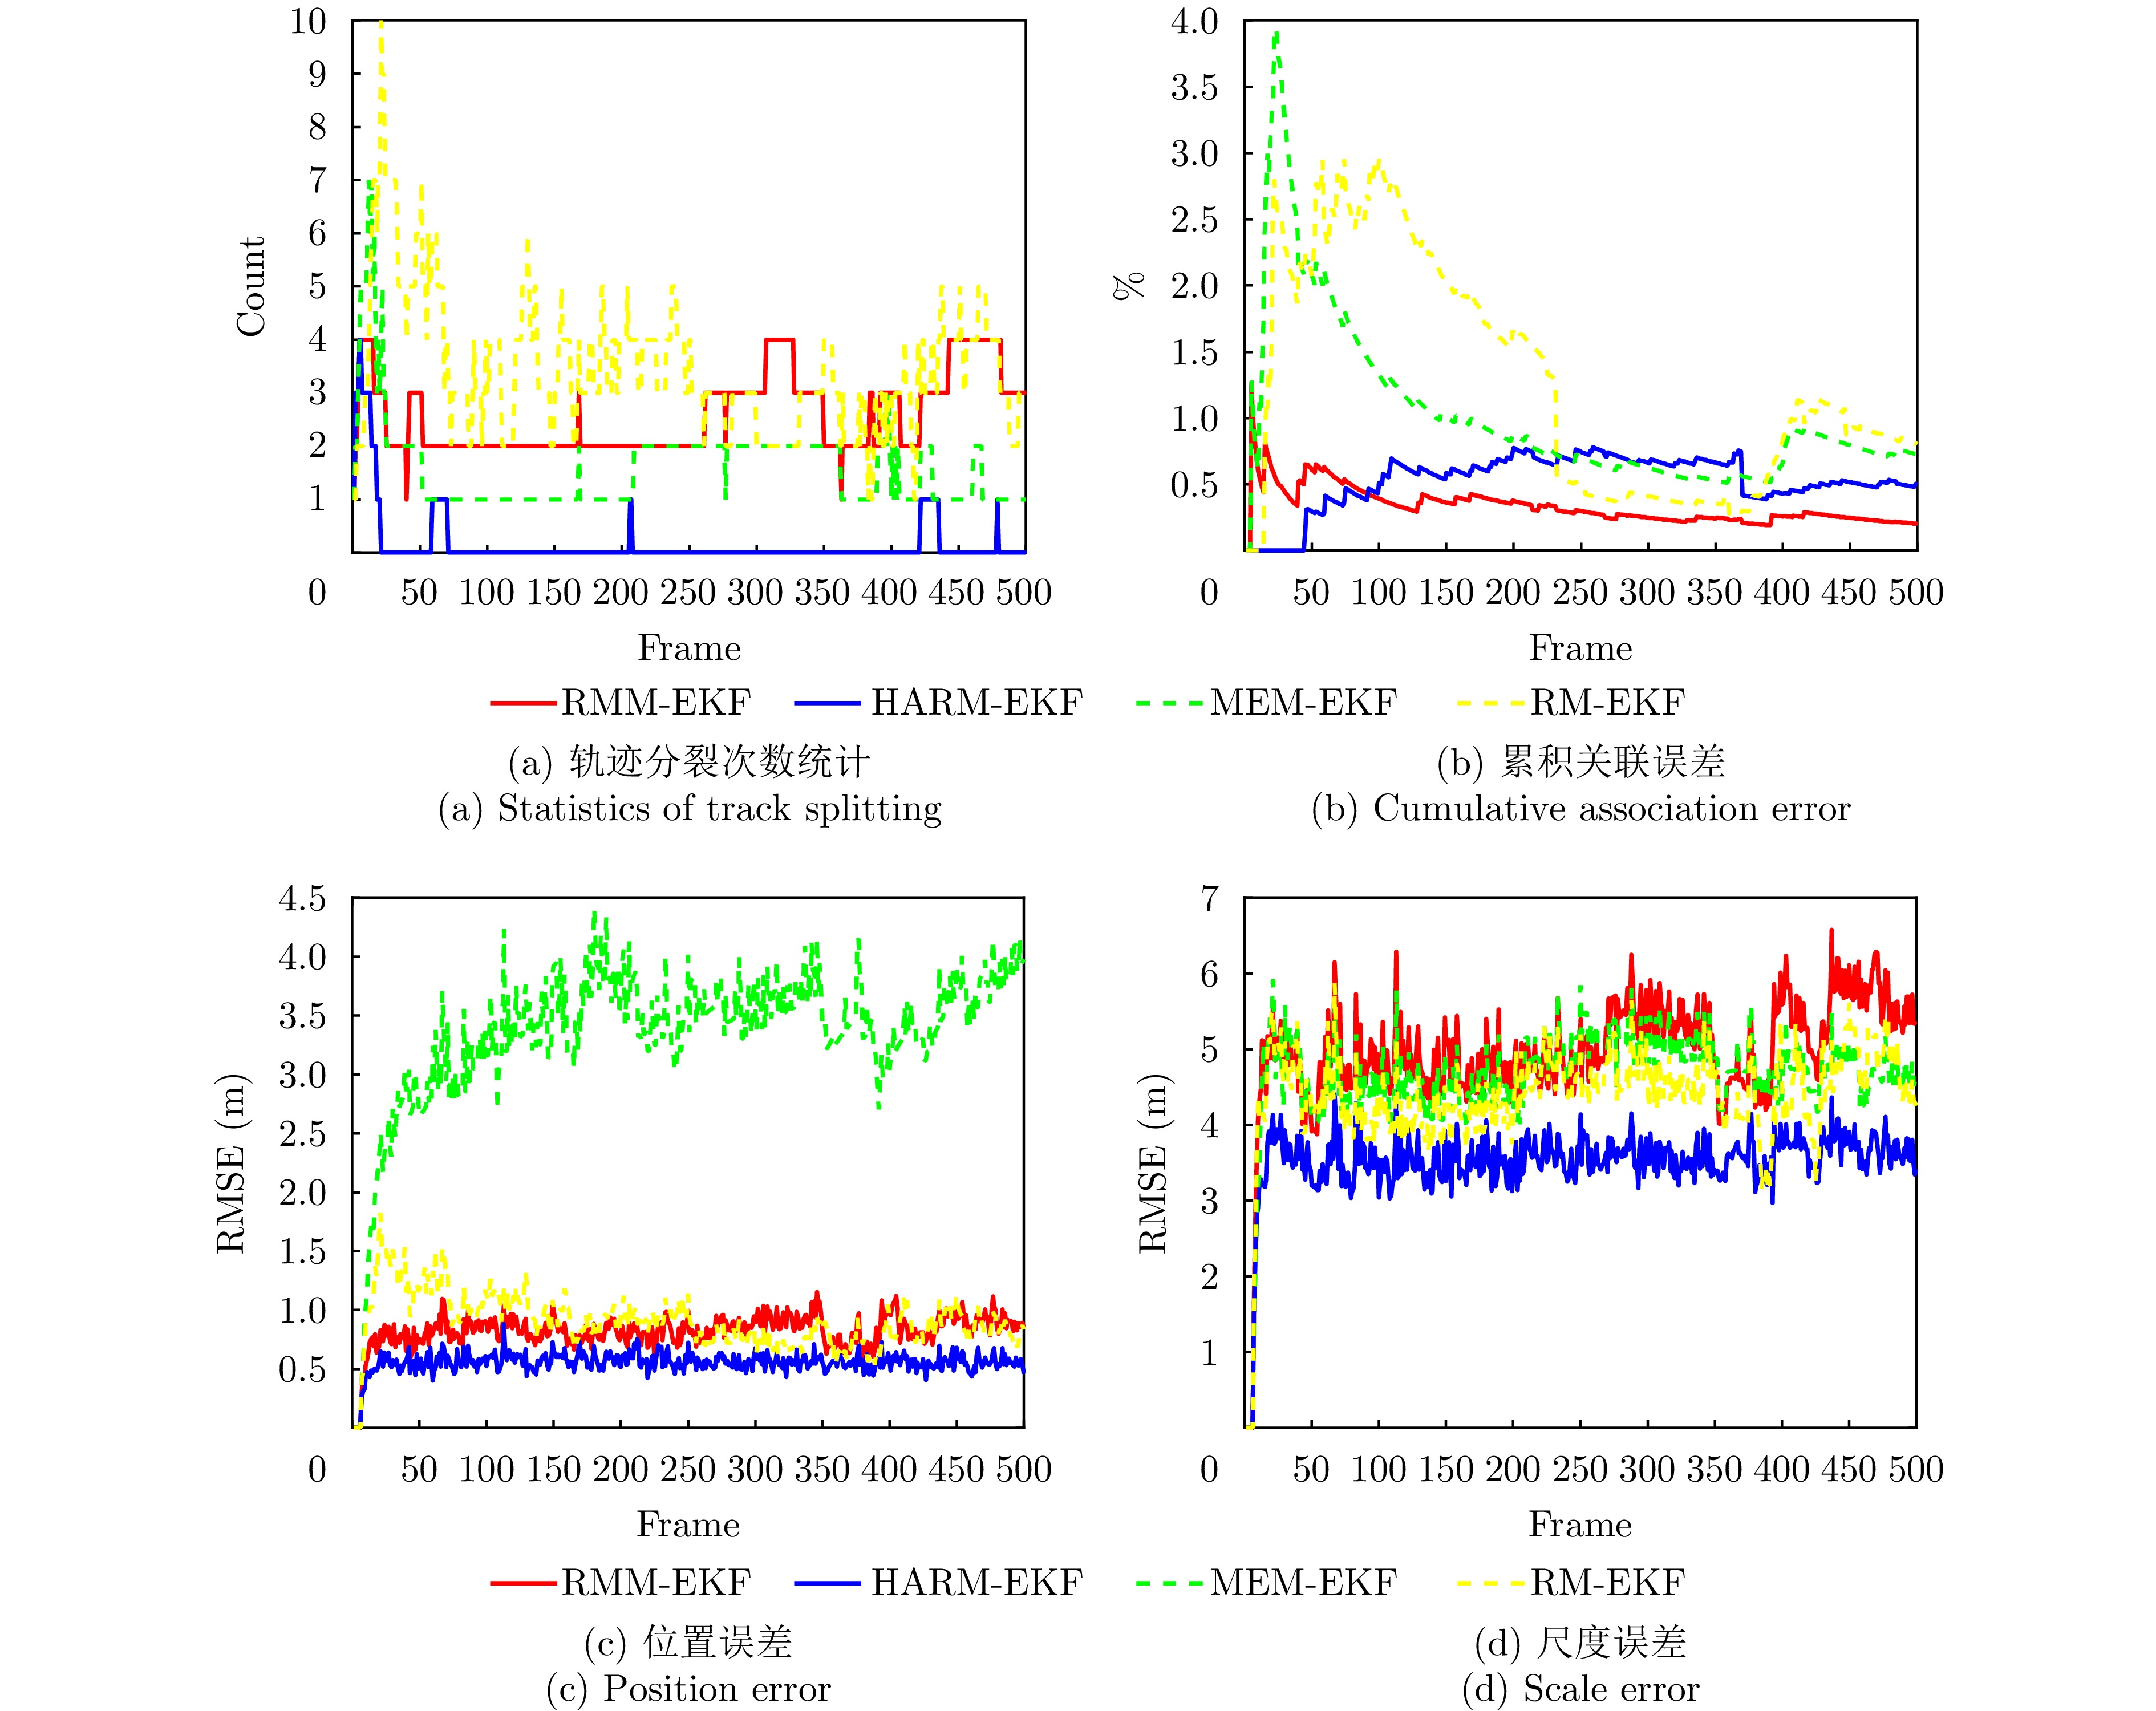
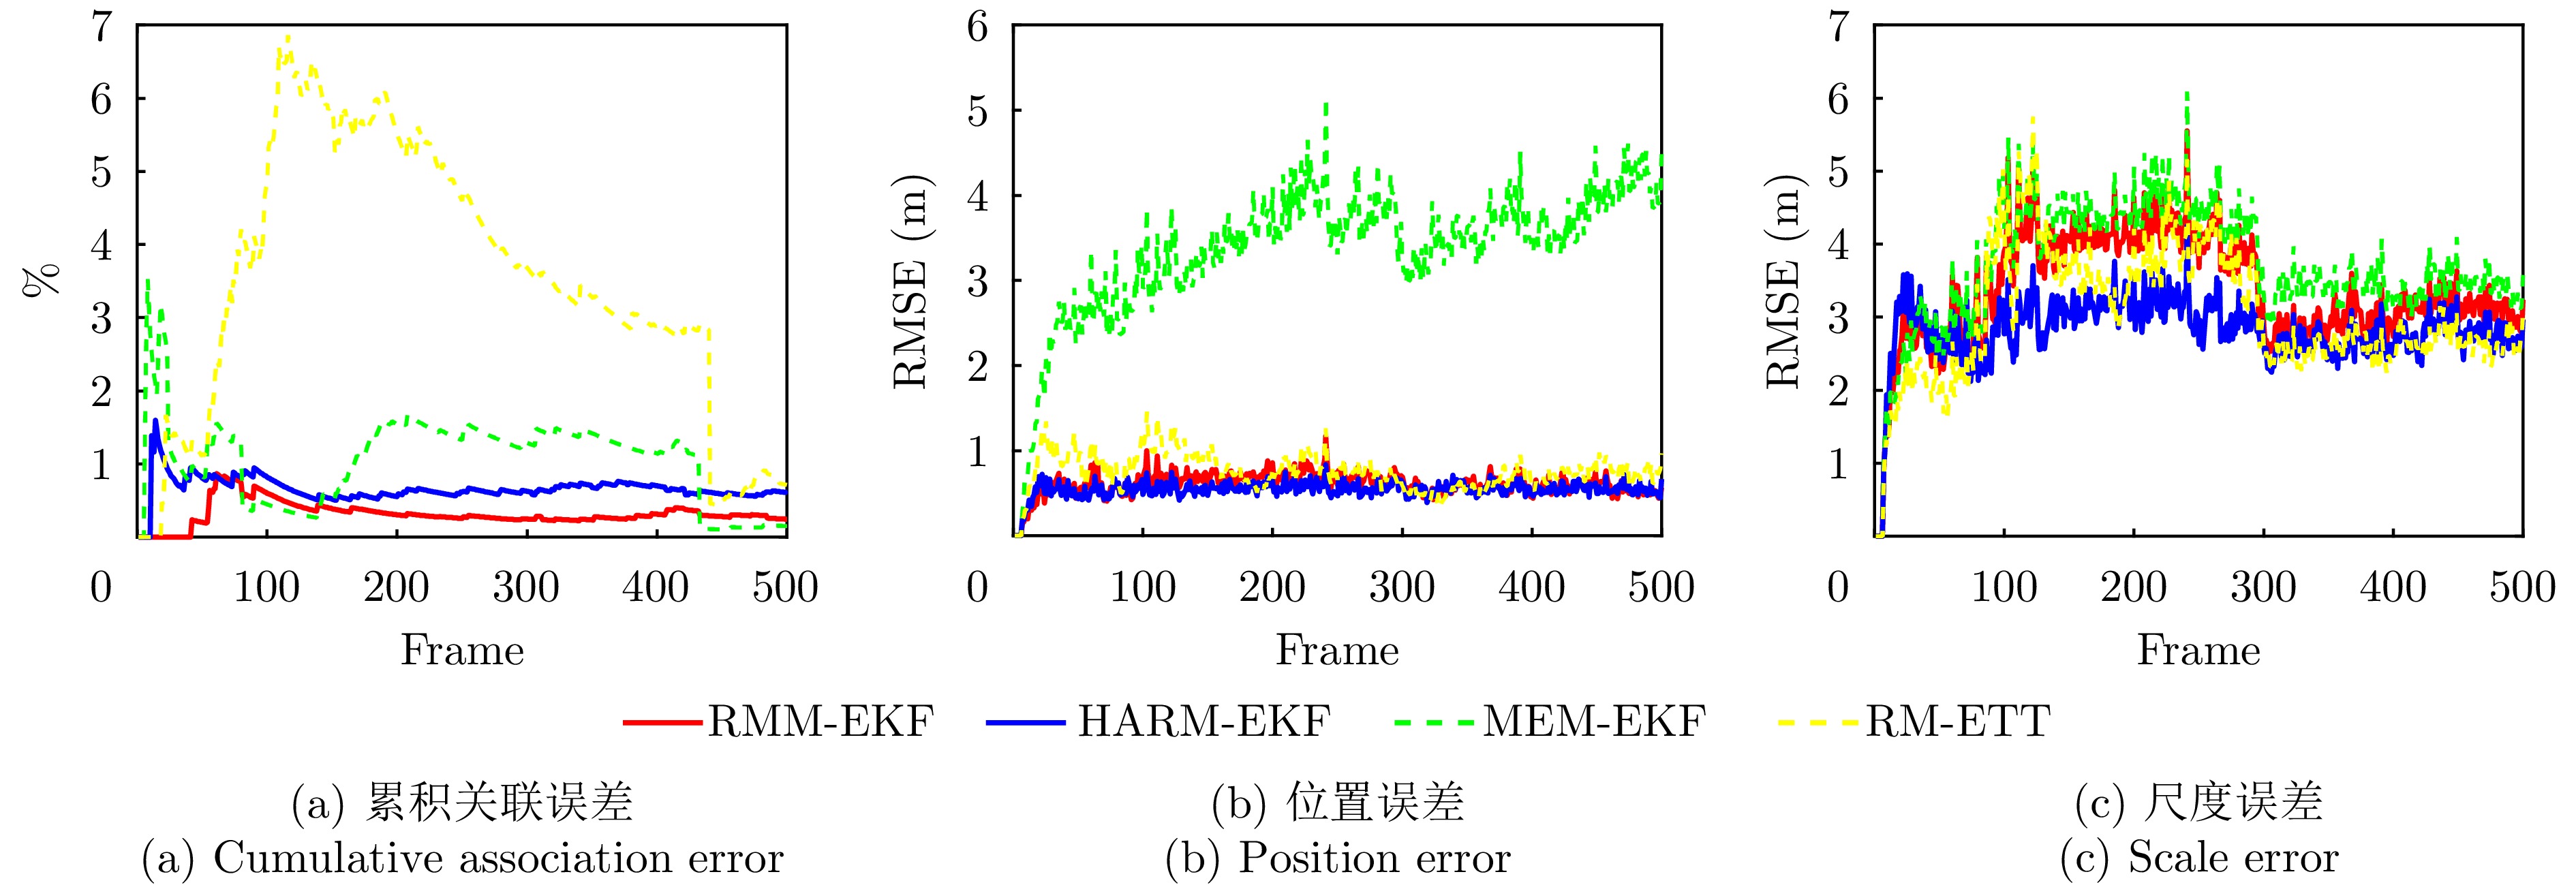
- Figure 12. Multi-metric performance evaluation results in the large-vehicle-dominant scenario
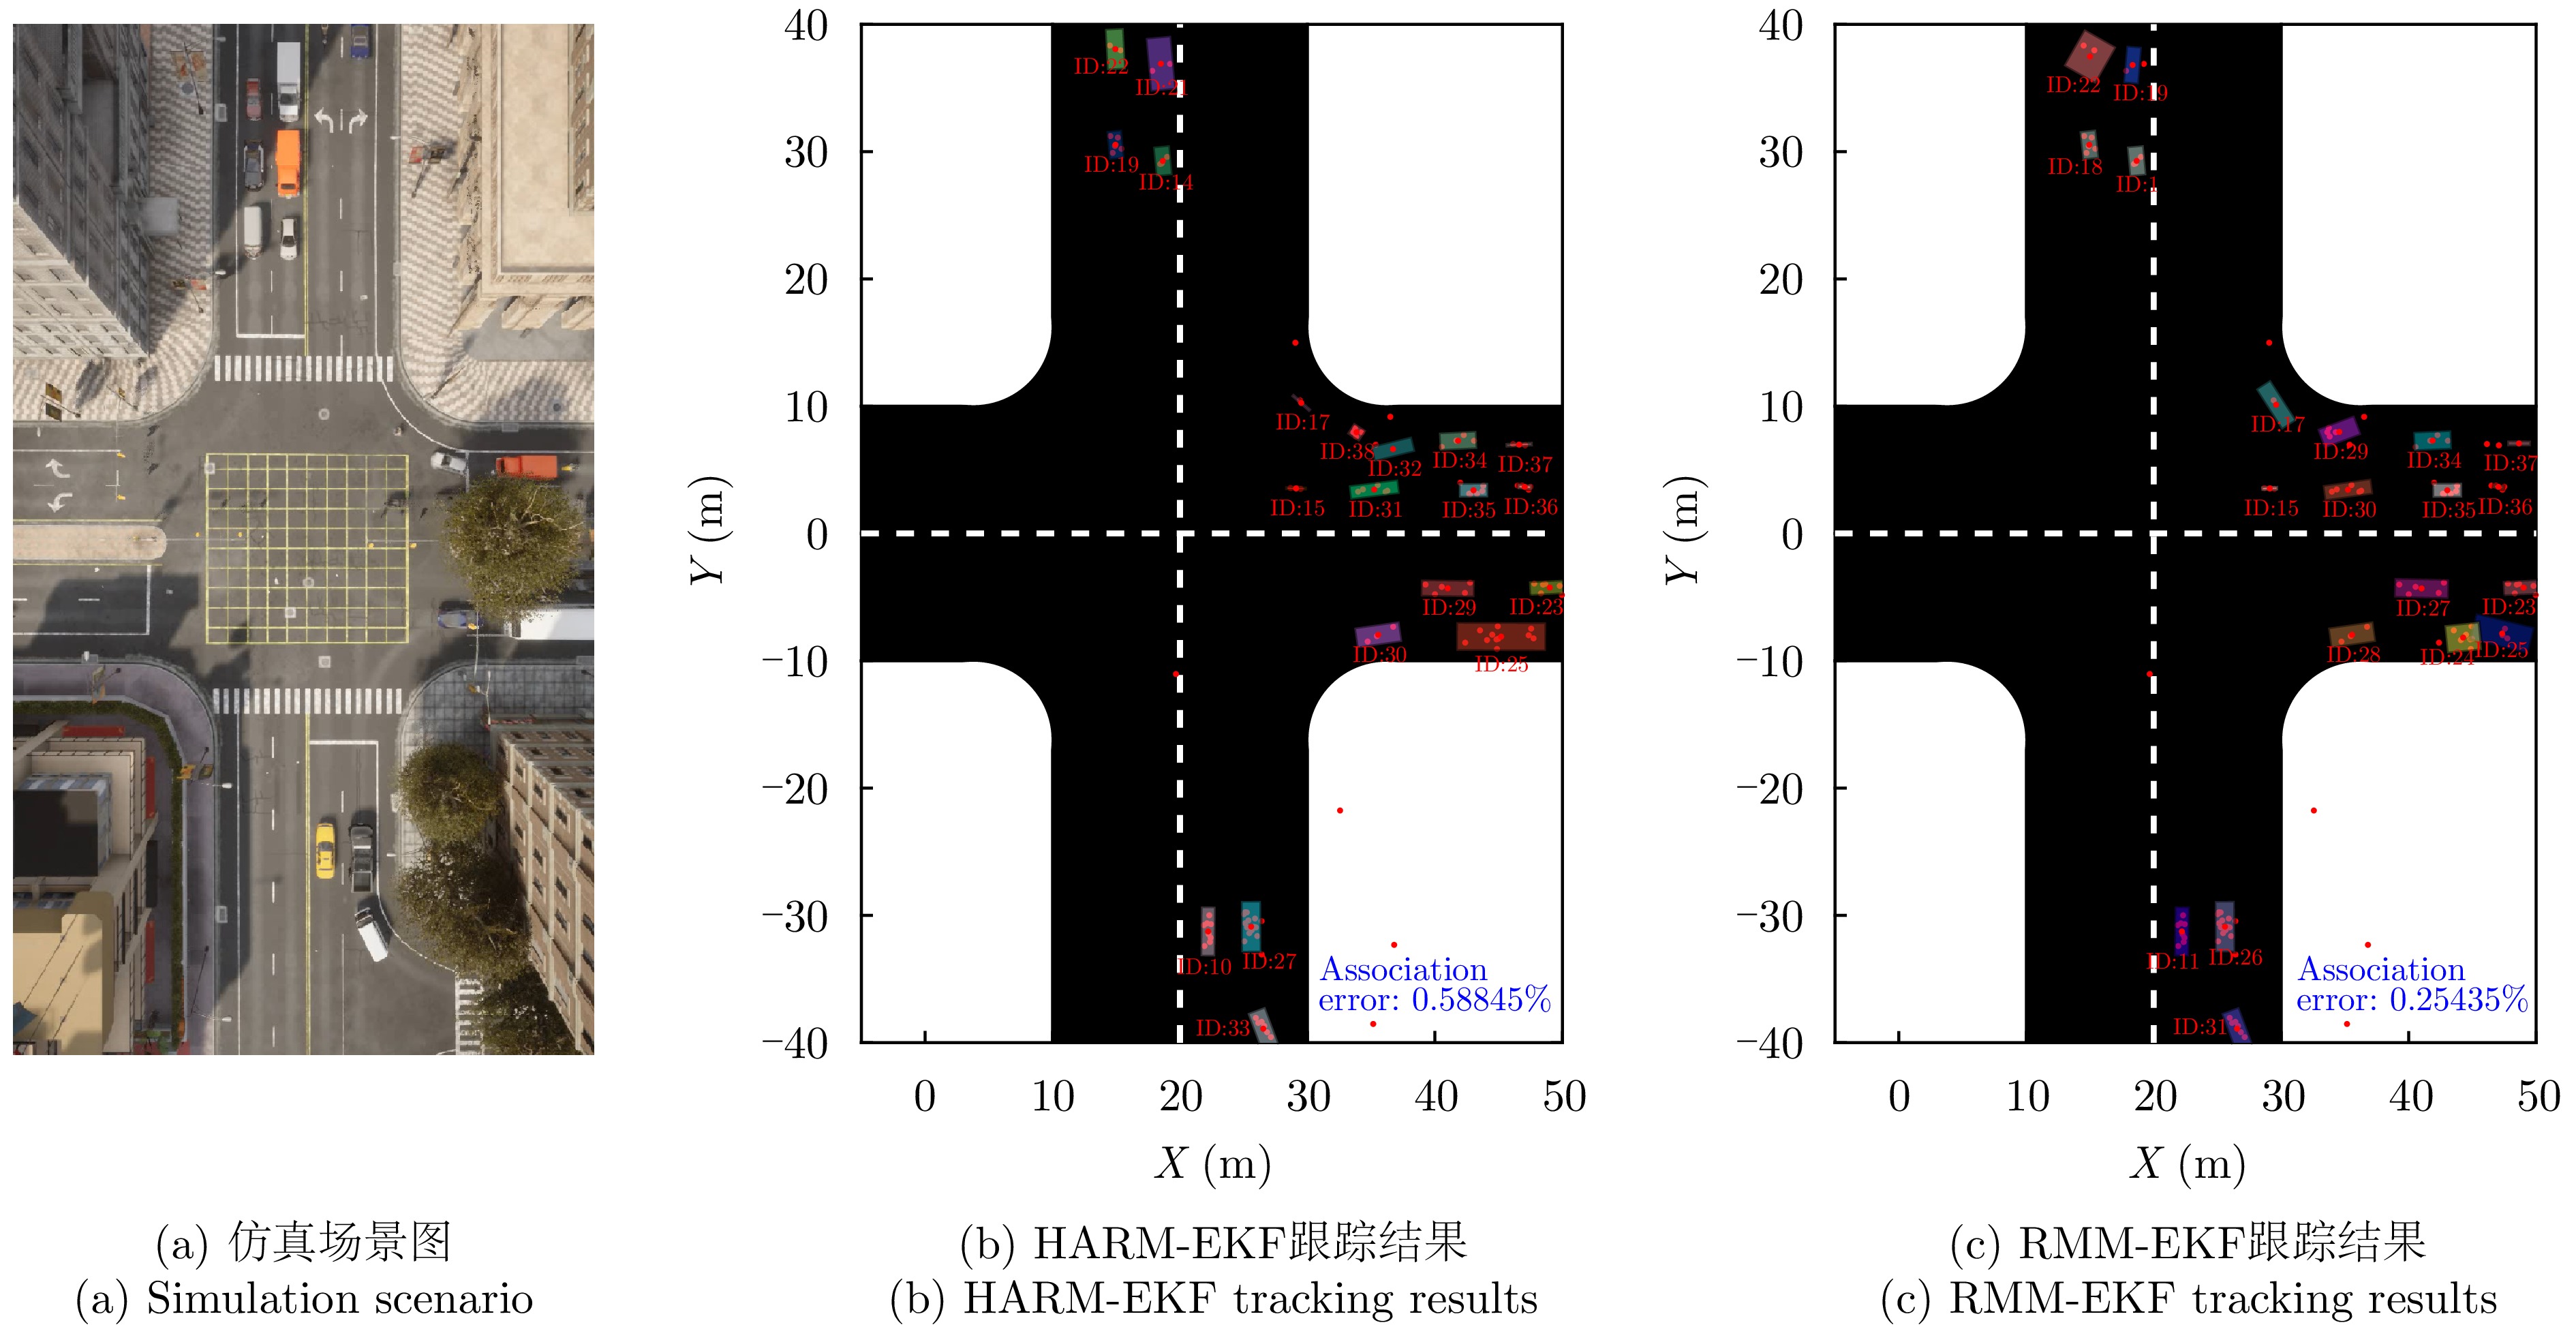
- Figure 13. Simulation scenario and tracking results in the small-vehicle-dominant scenario (frame 280)
- Figure 14. Simulation scenario and tracking results in the small-vehicle-dominant scenario (frame 327)
- Figure 15. Multi-metric performance evaluation results in the small-vehicle-dominant scenario
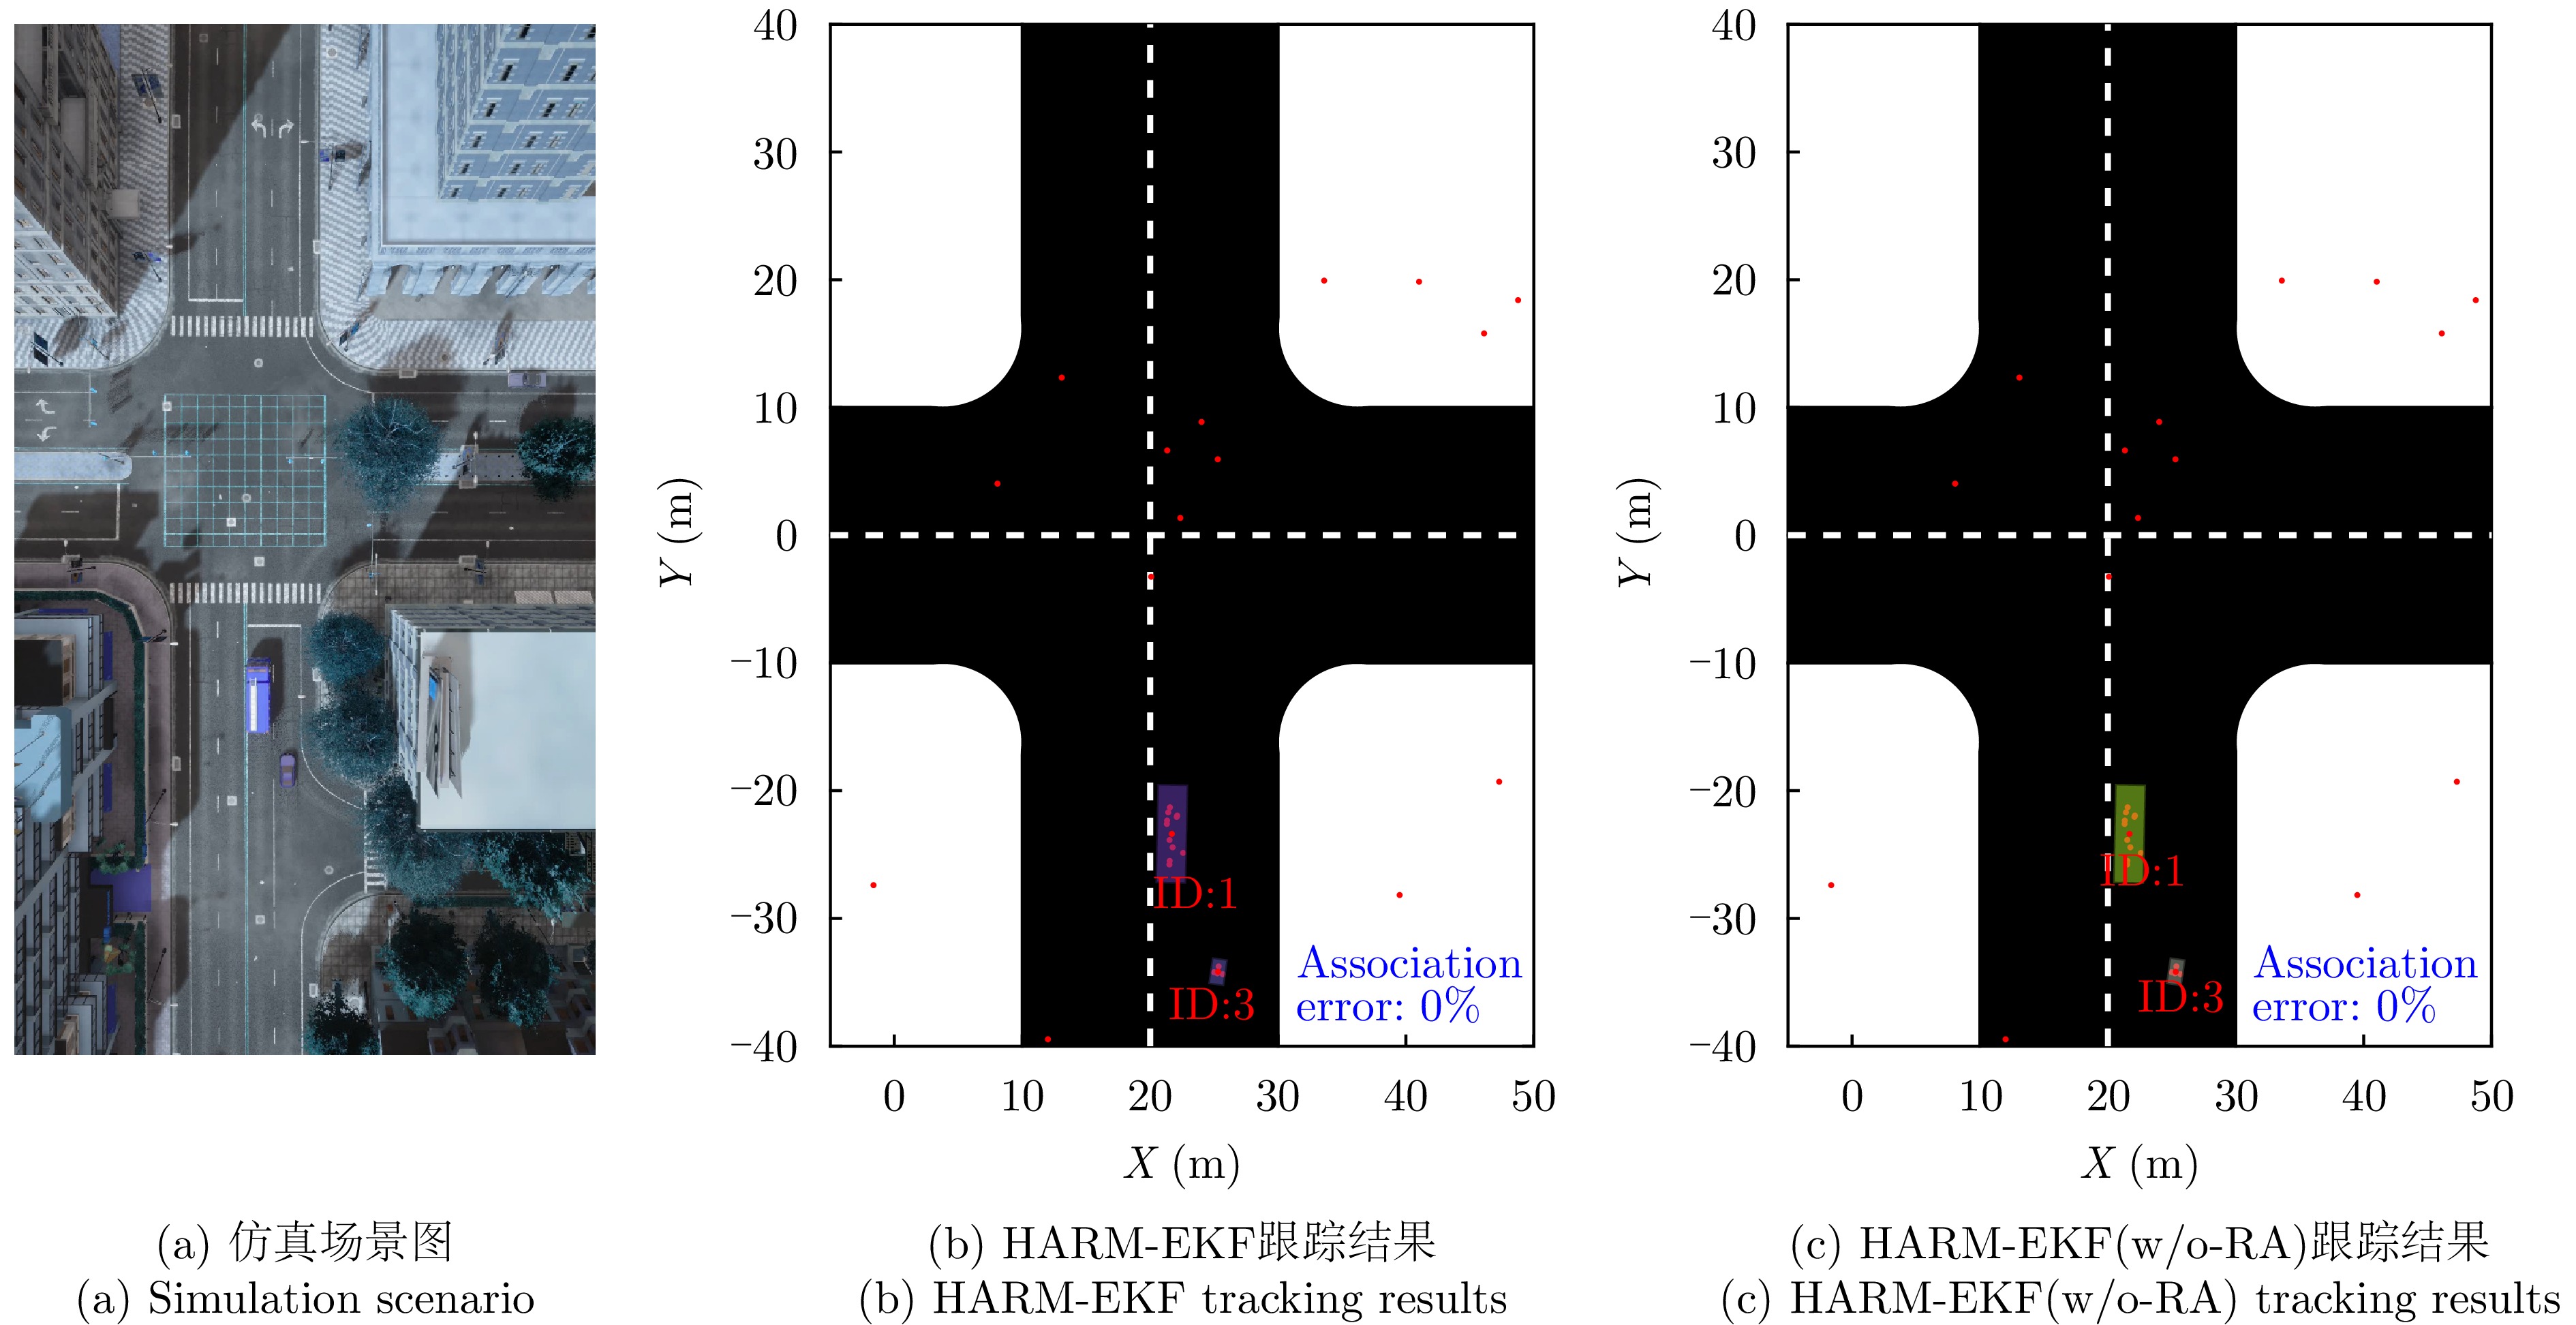
- Figure 16. Simulation scenario and tracking results of the hierarchical association ablation experiment
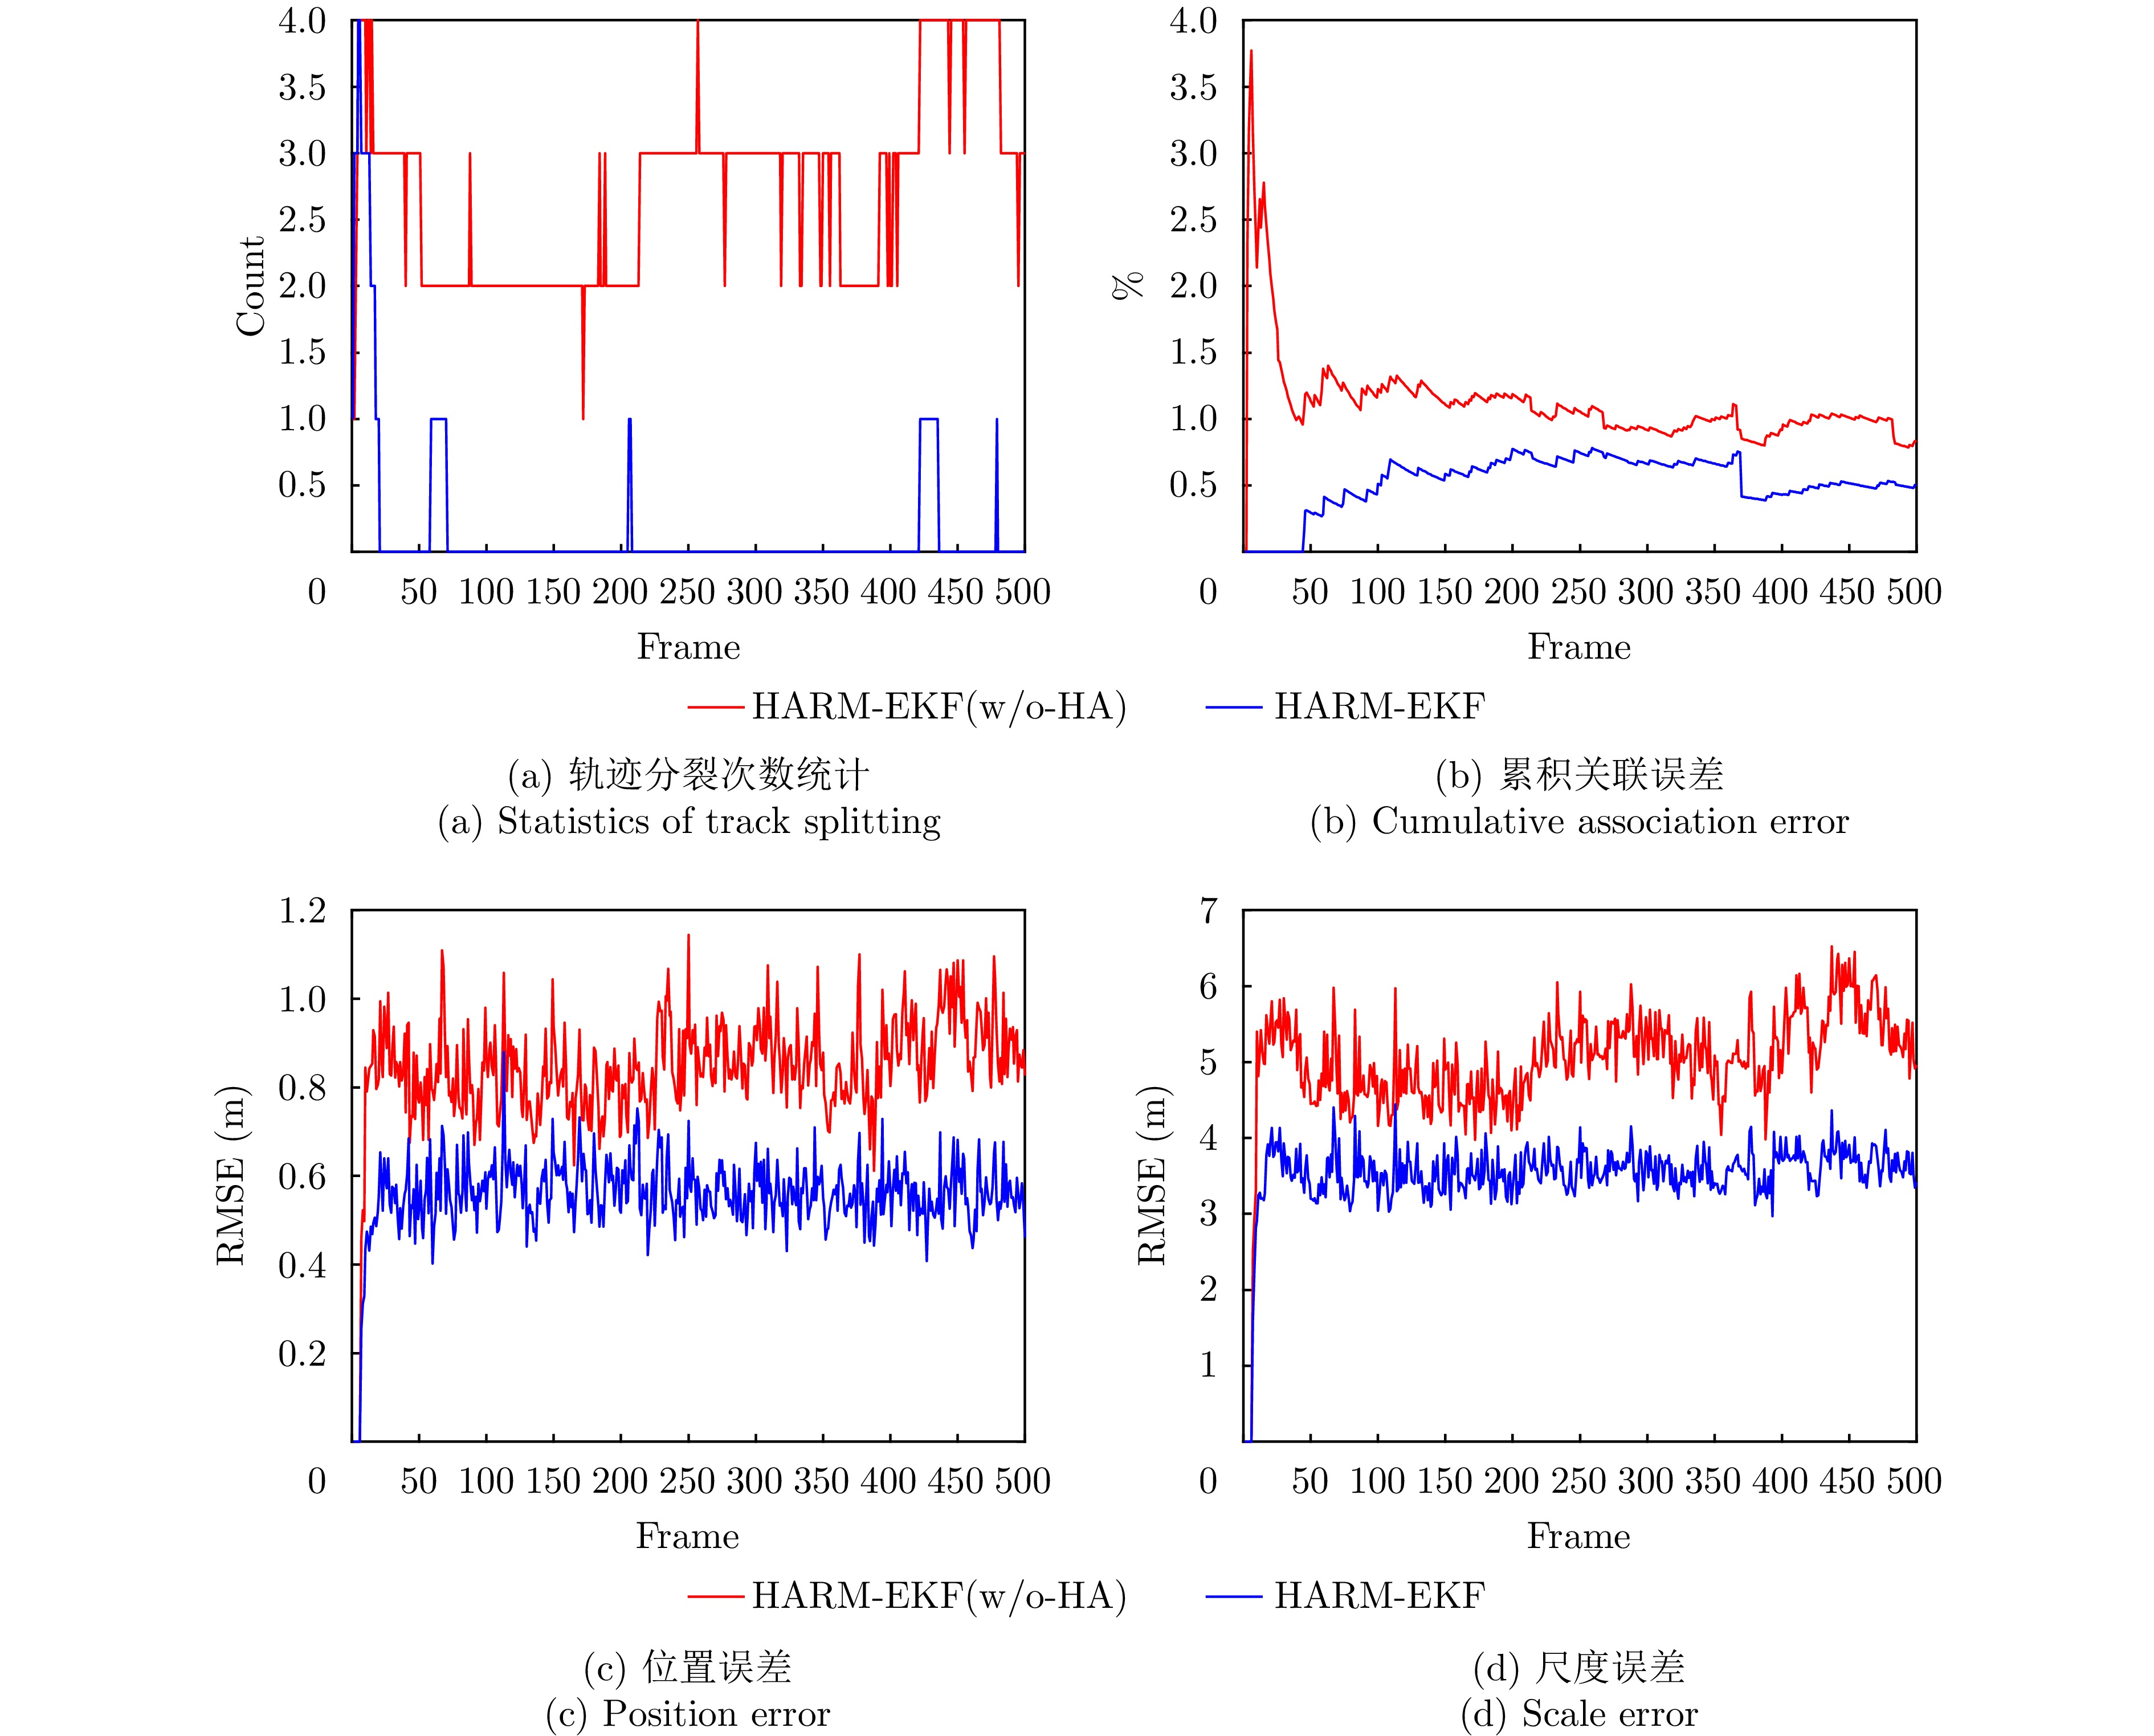
- Figure 17. Multi-metric performance evaluation results of the hierarchical association ablation experiment
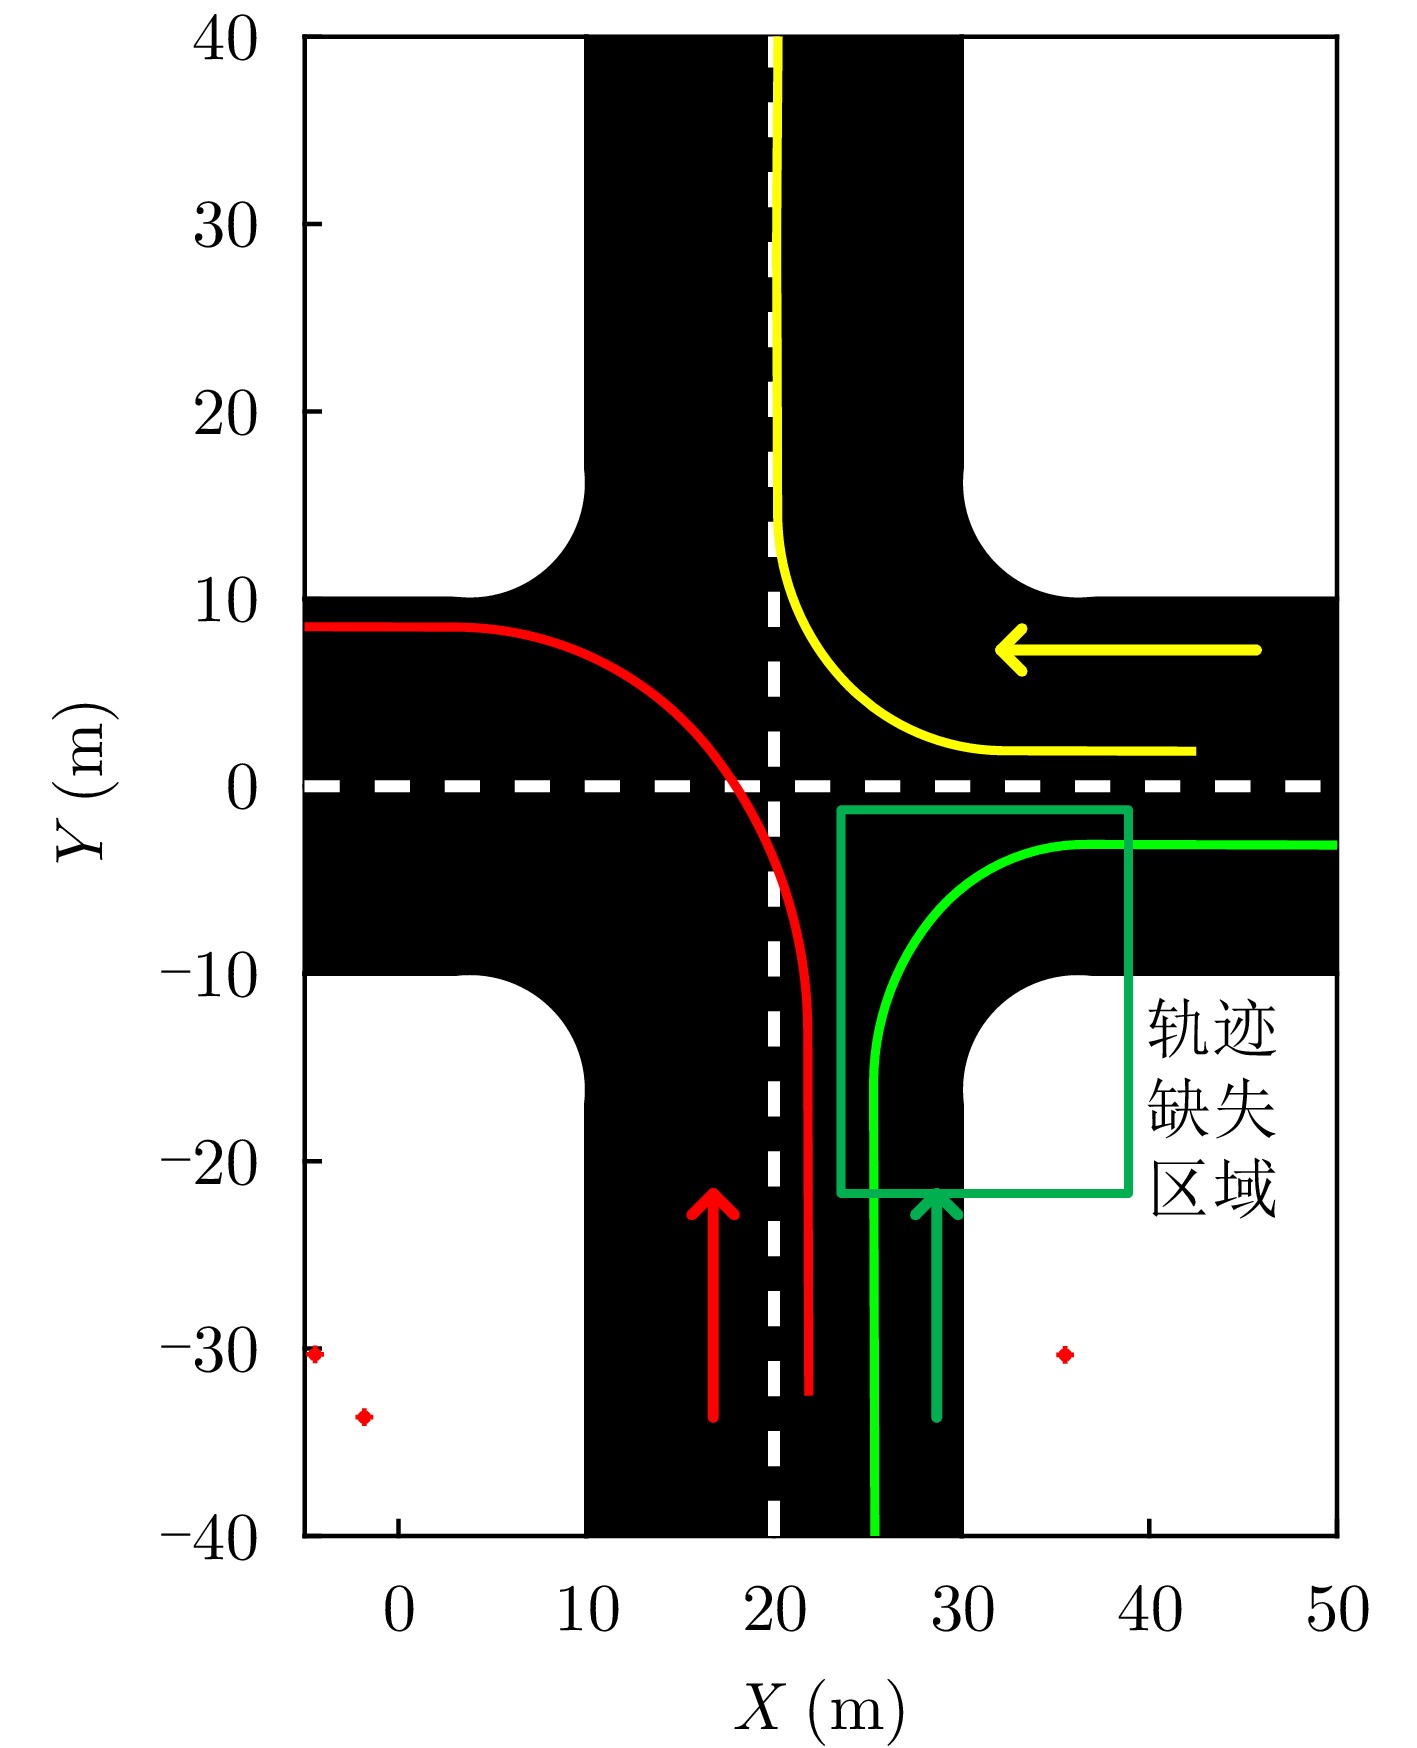
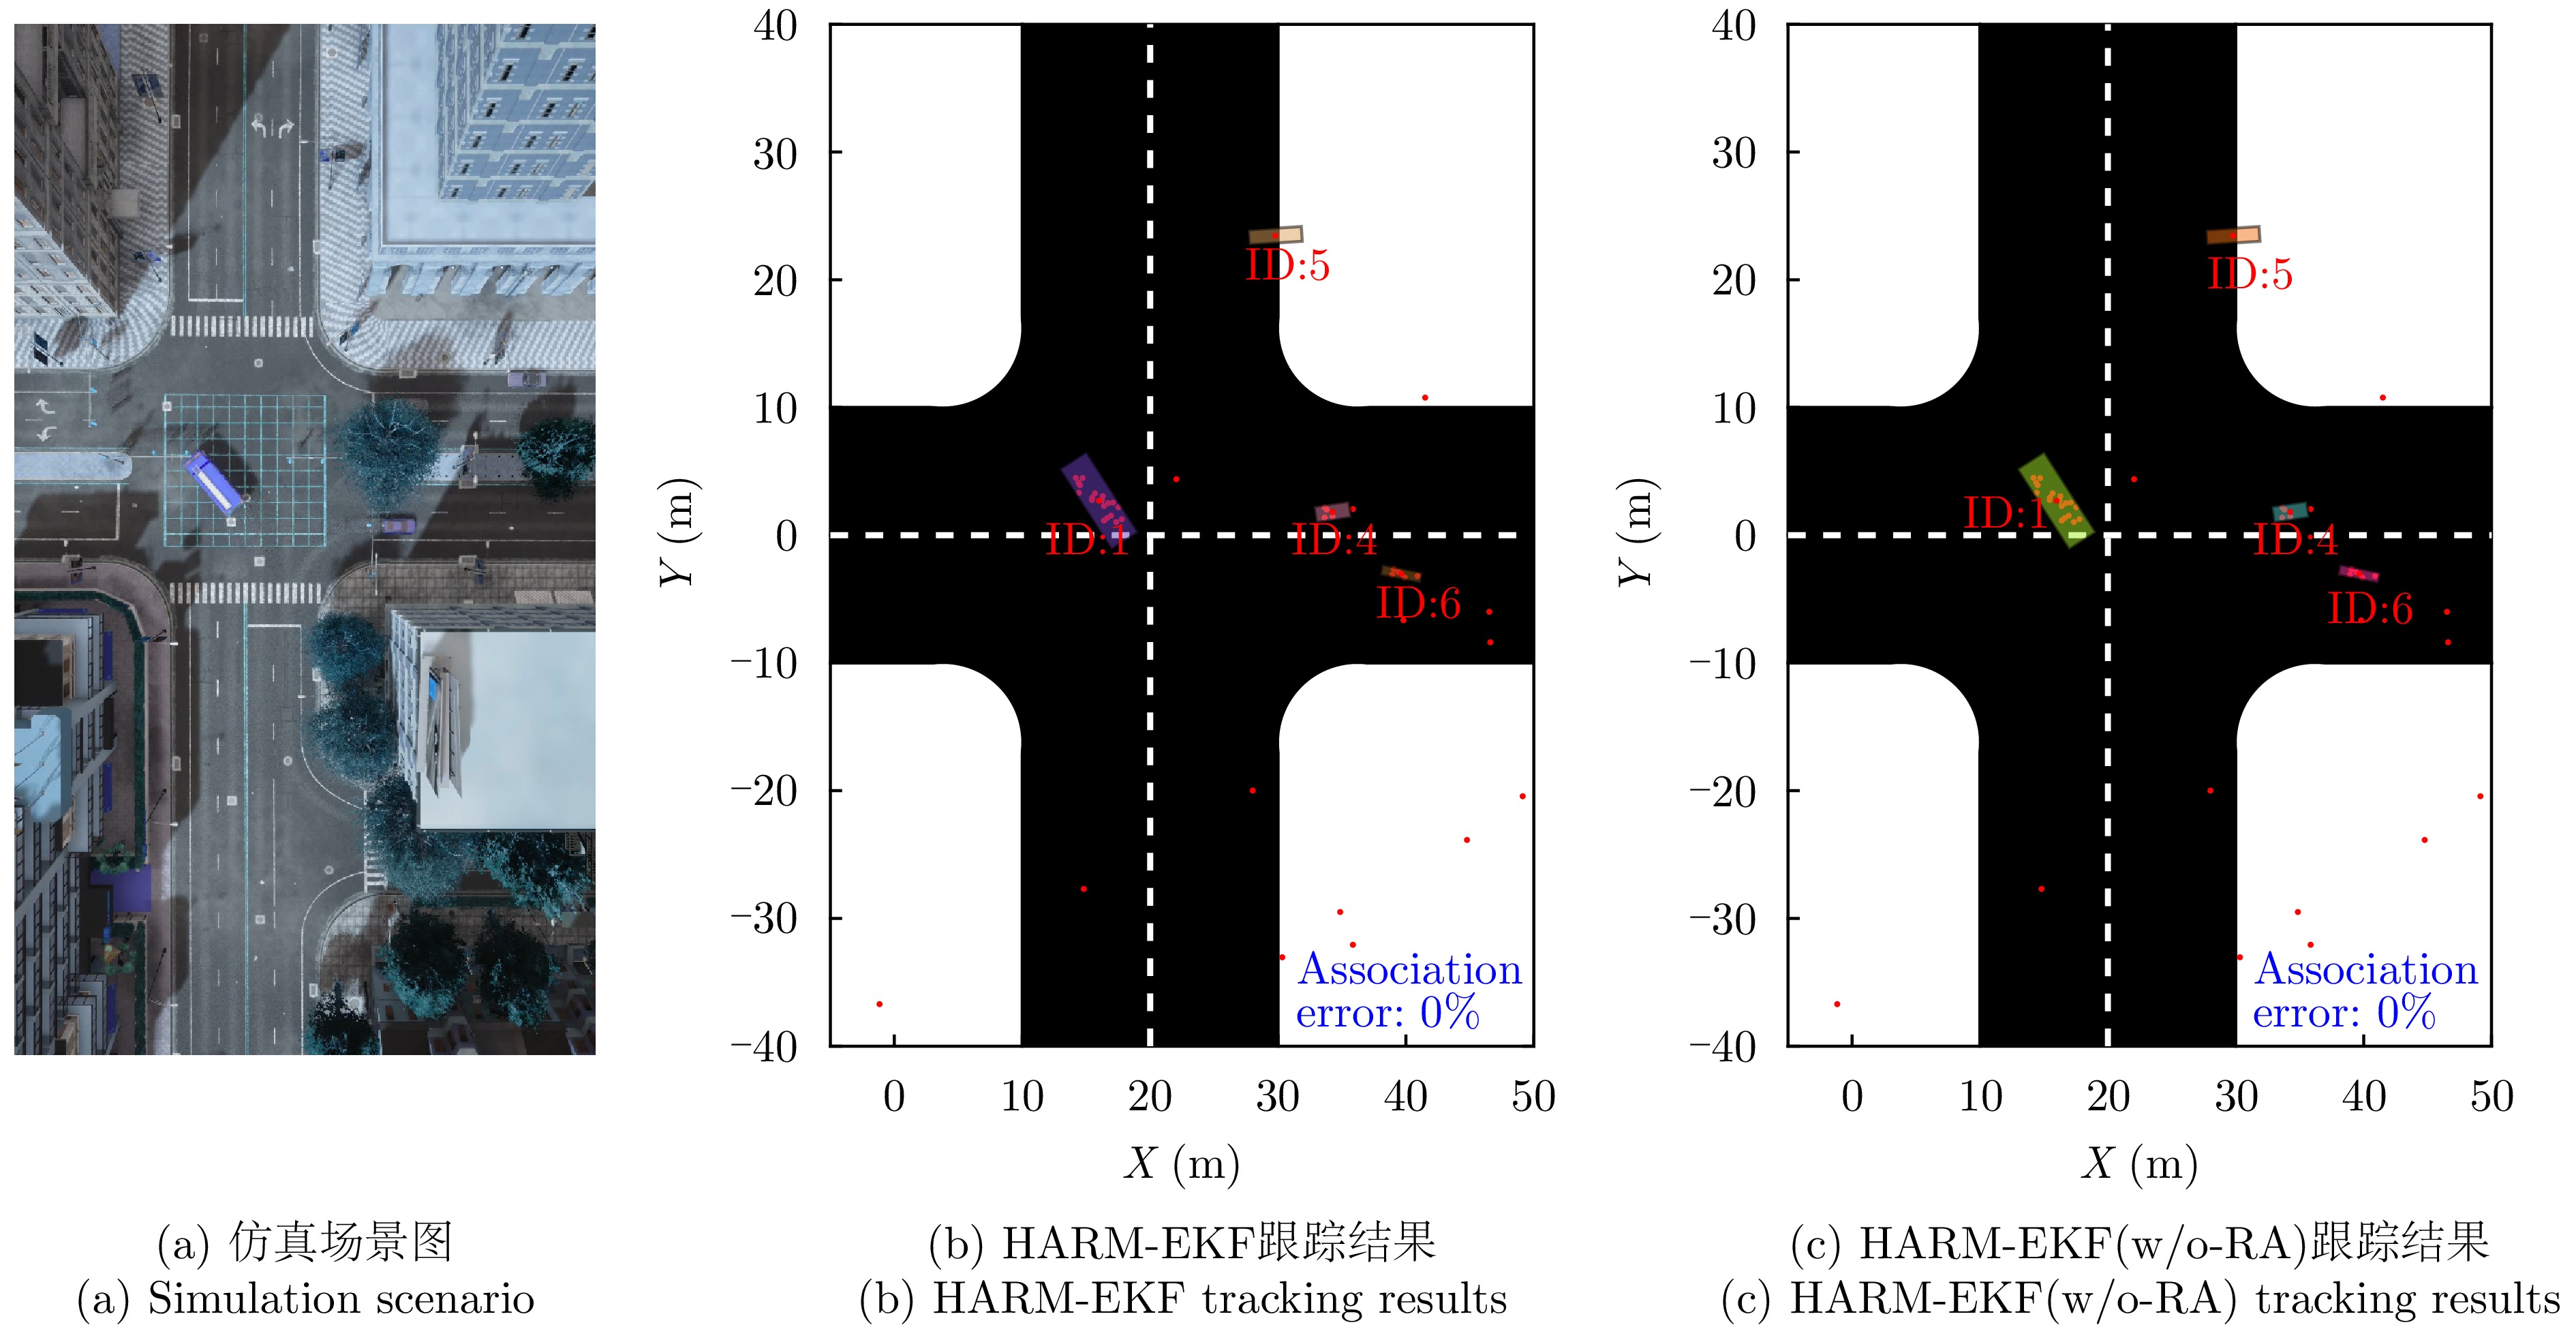
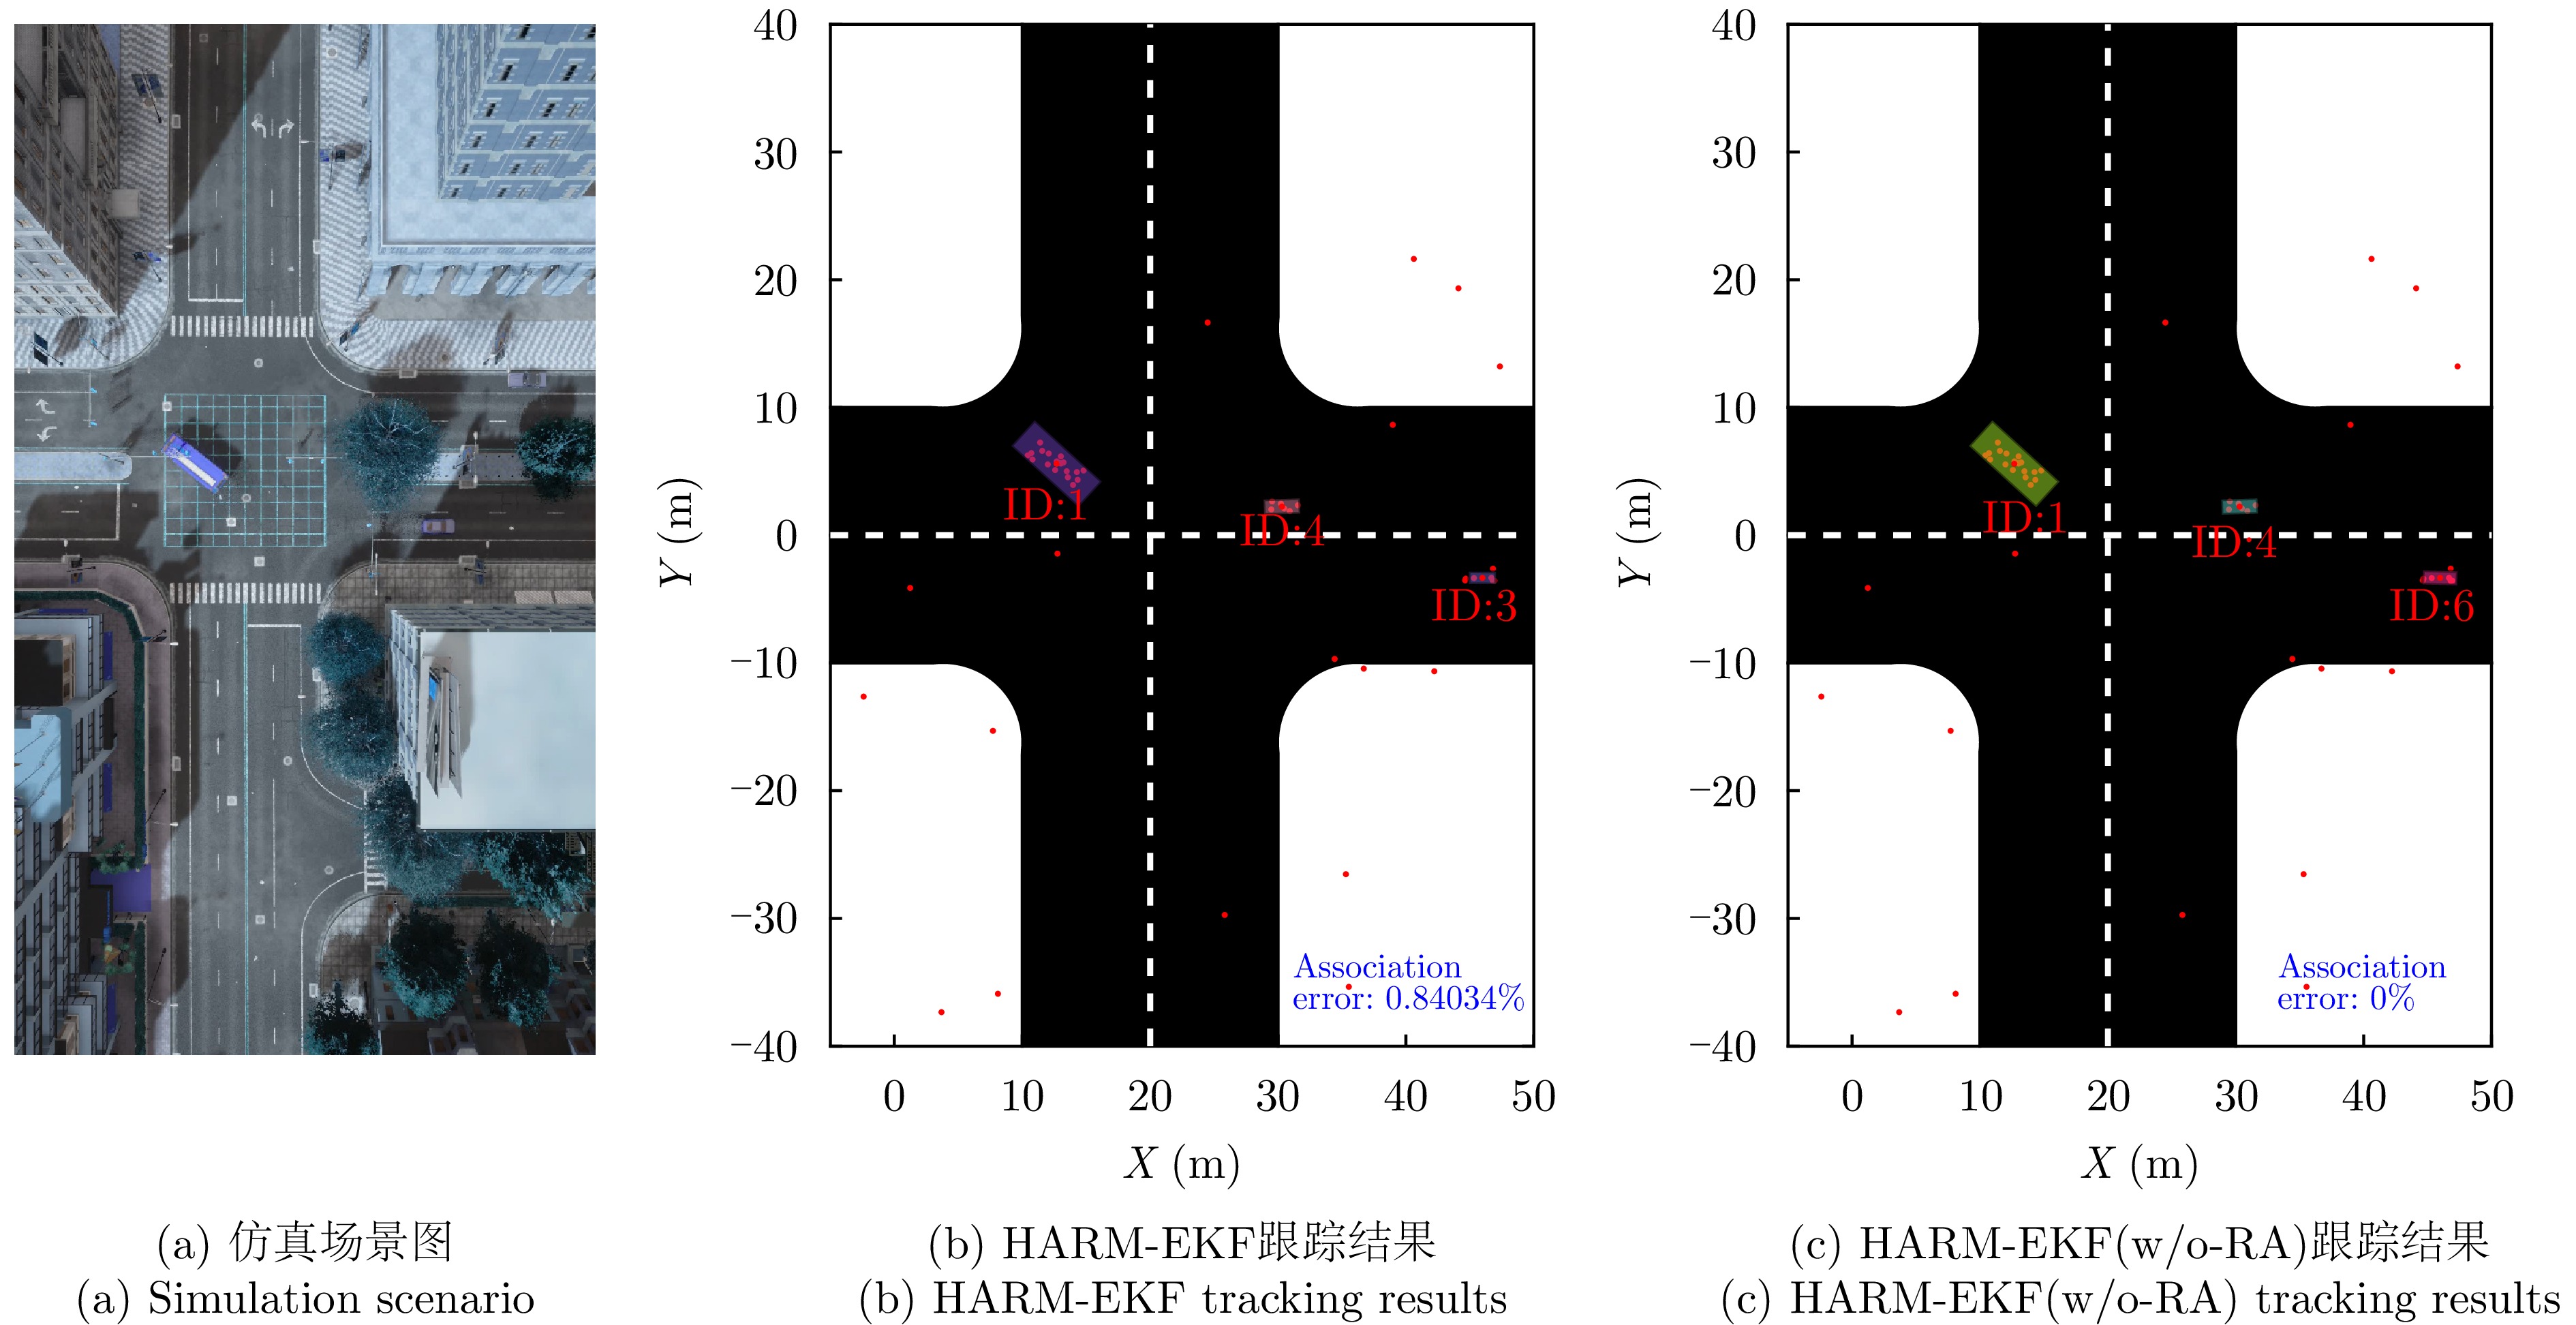
- Figure 18. Schematic diagram of the re-association ablation experiment scenario
- Figure 19. Simulation scenario and tracking results of the re-association ablation experiment (frame 19)
- Figure 20. Simulation scenario and tracking results of the re-association ablation experiment (frame 72)
- Figure 21. Simulation scenario and tracking results of the re-association ablation experiment (frame 78)